# Mission Planner
The **Mission Planner** allows you to **plan**, **configure**, and **monitor** the **robotic missions**. You can **configure** the **robotic units**, define **operational equipments**, and create **missions**. It allows you to **monitor** **mission status** and review the **data collected**. This book guides you from **initial configuration** to **real-time management** and **monitoring of completed missions**, and is useful for **automation** and **surveying** contexts.
**ITA:** Il **Mission Planner** consente di **pianificare**, **configurare** e **monitorare** le **missioni robotiche**. È possibile **configurare** le **unità robotiche**, definire i **equipaggiamenti operativi** e creare le **missioni**. Permette di **monitorare** lo **stato delle missioni** e consultare i **dati raccolti**. Questo libro ti guida dalla **configurazione iniziale** alla **gestione in tempo reale** e al **monitoraggio delle missioni concluse**, ed è utile in contesti di **automazione** e **rilievo**.
# Initial Setup
Before planning a mission, some basic system resources must be configured. These configurations define the assets used by the Mission Planner within projects.
[  English ](https://wiki.eaglearca.com/link/171#bkmrk-english-version) [  Italiano ](https://wiki.eaglearca.com/link/171#bkmrk-english-italiano-1)
---
Before planning a mission, some **basic system resources** must be configured.
These configurations define the assets used by the **Mission Planner** within projects.
The initial setup is managed through *[**Global Lists**](https://wiki.eaglearca.com/books/app-features/page/create-a-global-object "Create a global object")* and is a prerequisite for correctly enabling mission planning.
---
### Initial setup through Global Lists
From the app selection page, select the app you want to work on. Then, from the left sidebar, open the **Global Lists** section.

The main lists used for mission planning are:
- **Mission Unit**
Represents the robotic units available in the project.
- **Add-on**
Represents sensors, cameras, and accessories, either native or additional, used to support mission objectives.
- **Equipment**
Represents technical configurations composed of one or more **Add-on**. An Equipment is what you select when you configure a mission.
---
### Register a Mission Unit
To use a **Mission Unit** in mission planning, it must first be registered in the platform.
The Mission Unit models available for integration are:
- Unitree B2
- Unitree B2 Wheel
- Unitree Go2
- DJI Matrice 4TD
- DJI Dock 3
To **add** a new Mission Unit, open the **Mission Units** **global list** and click the **New object** button.
#### Robot dog
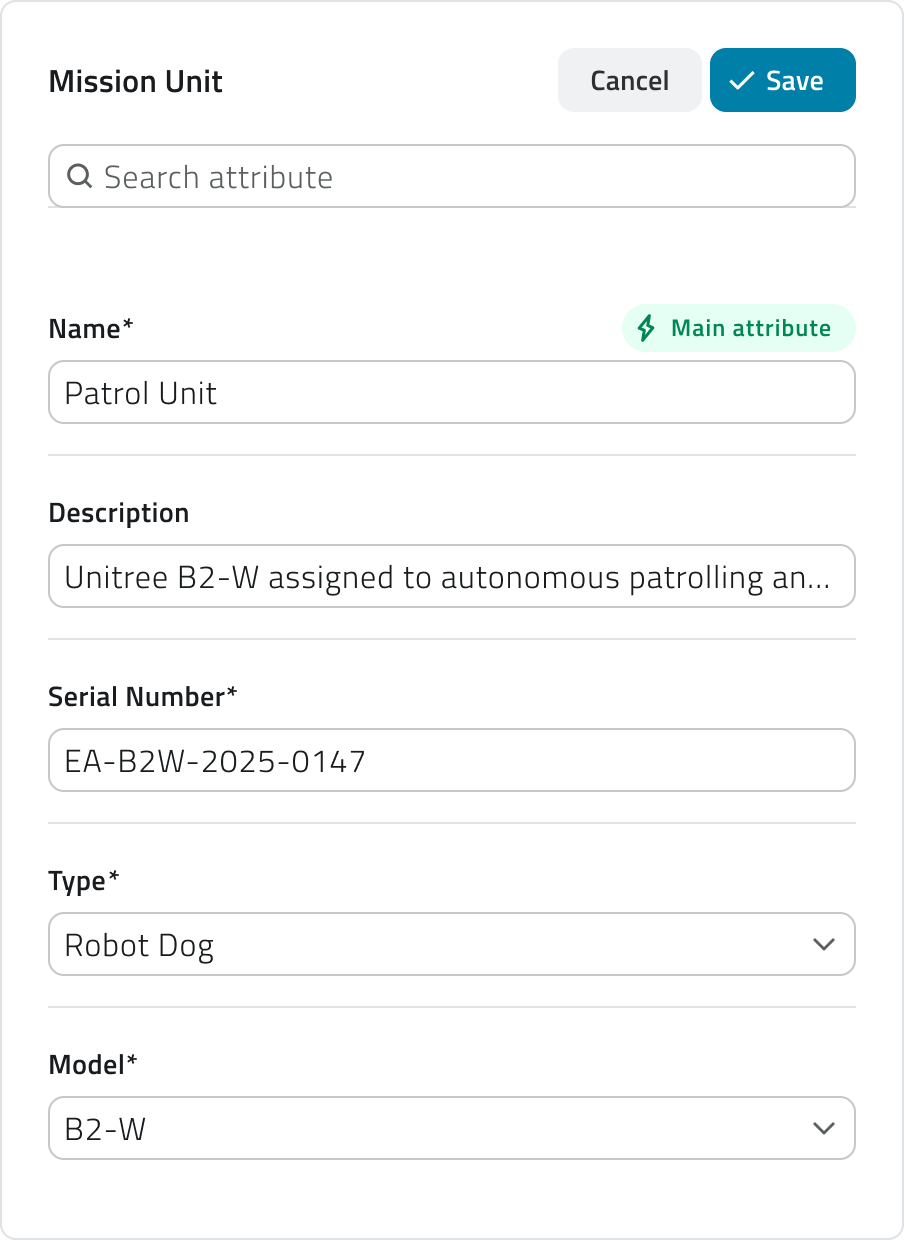
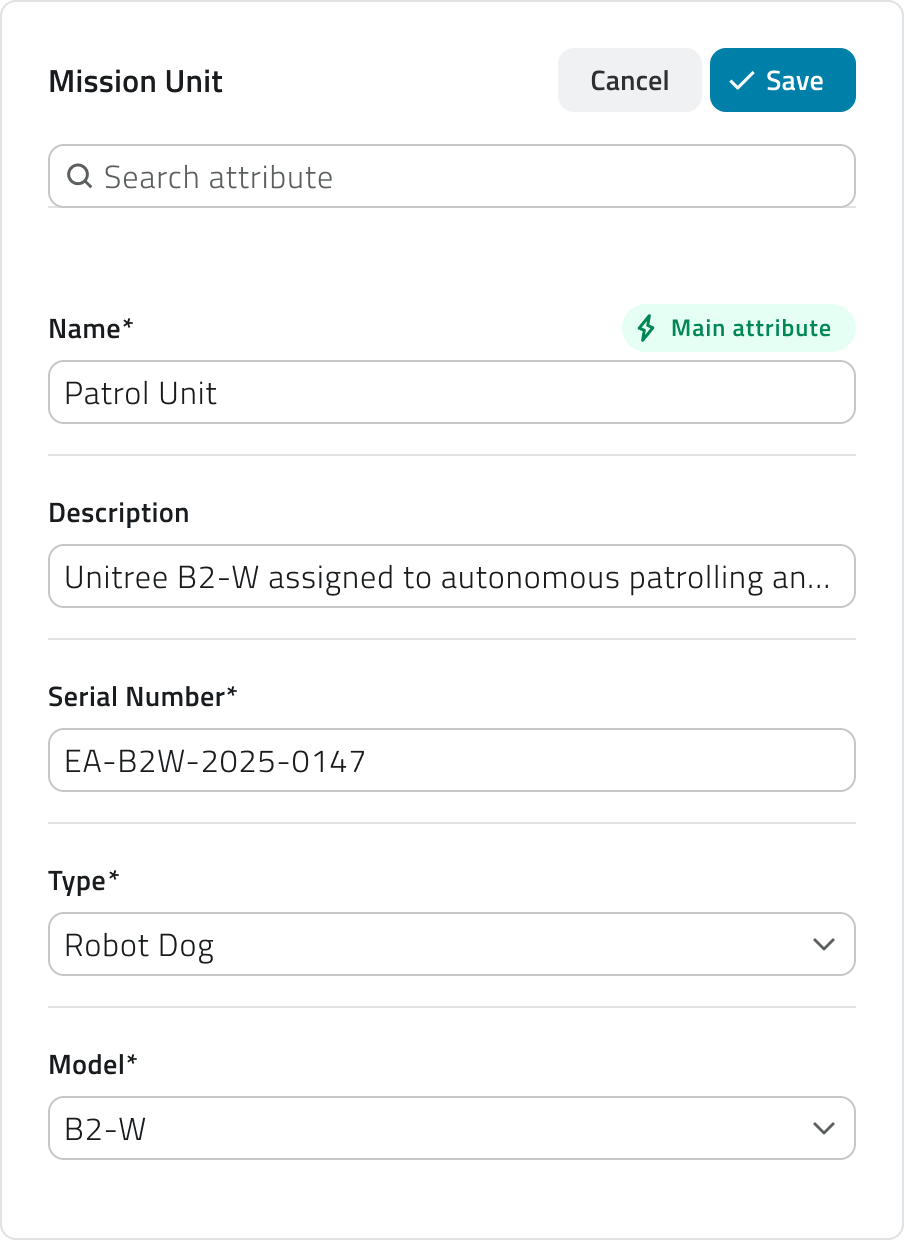
To register a robot dog, complete the following fields:
- **Name**
- **Description**
- **Serial Number**
Unique identification code displayed on the body of the robot dog.
Its position may vary depending on the model.
- **Type**
Select **Robot dog** from the list.
- **Dog model**
Select the specific robot dog model from the list.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/image-2.png)
#### Drone
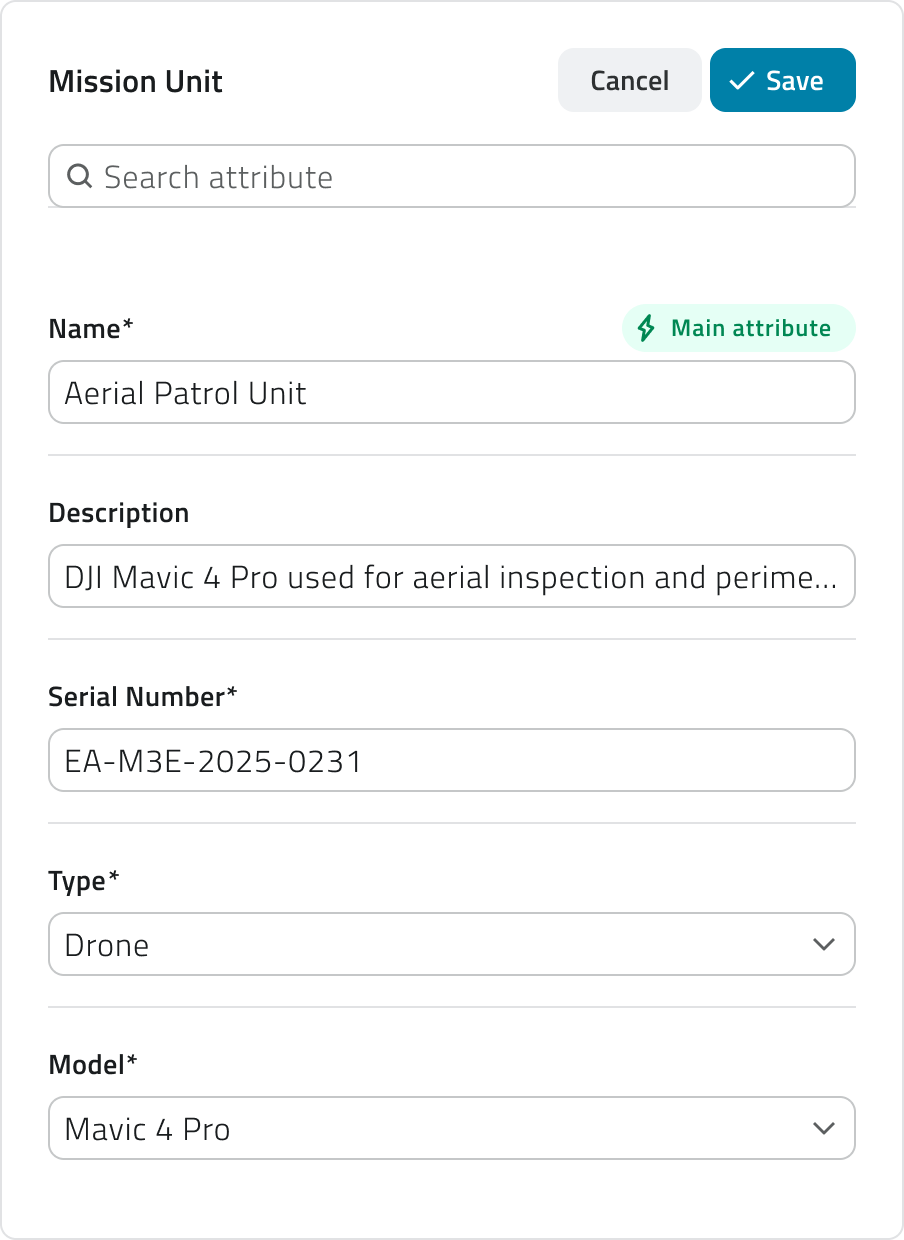
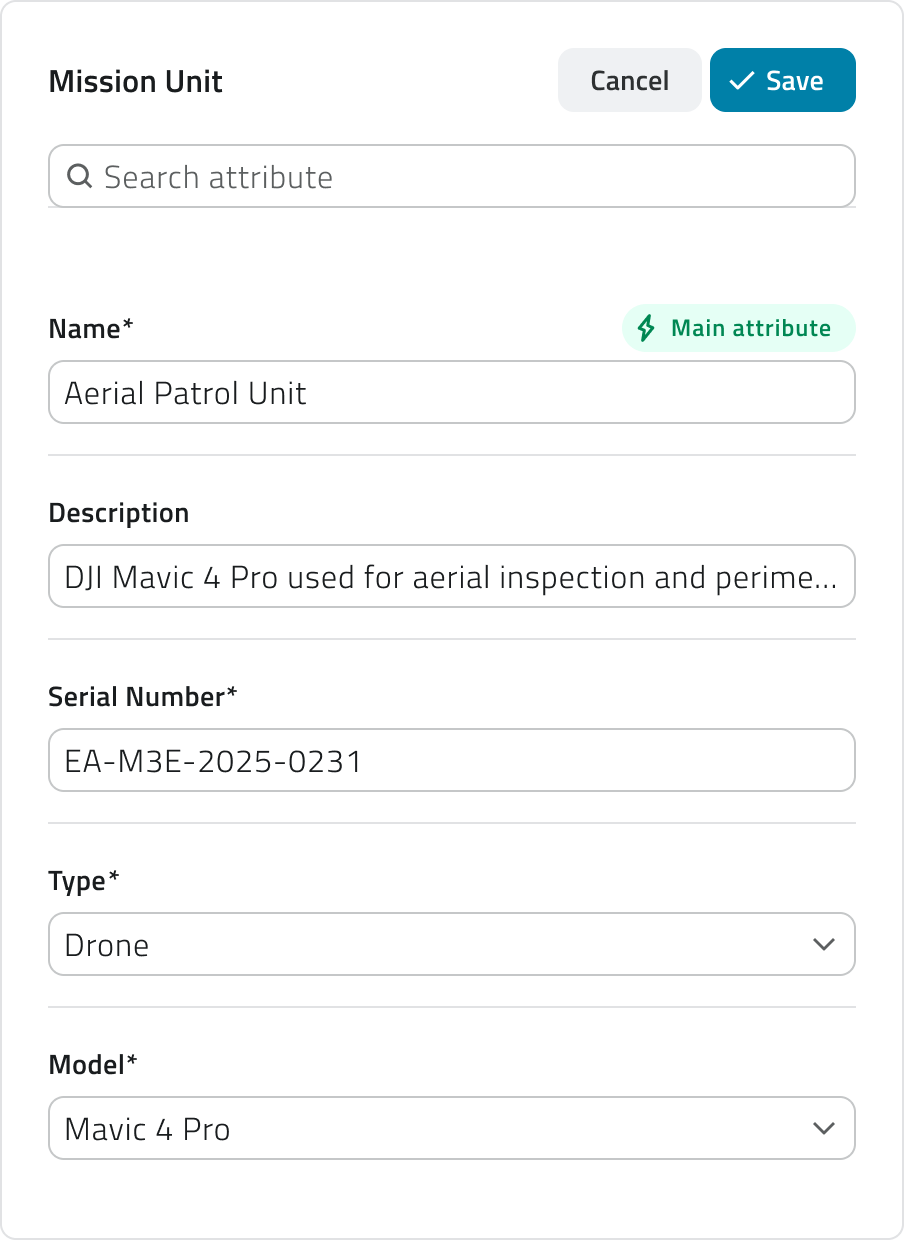
To register a drone, complete the following fields:
- **Name**
- **Description**
- **Serial Number**
Unique identification code displayed on the body of the drone.
Its position may vary depending on the model.
- **Type**
Select **Drone** from the list.
- **Drone model**
Select the specific drone model from the list.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/image-3.png)
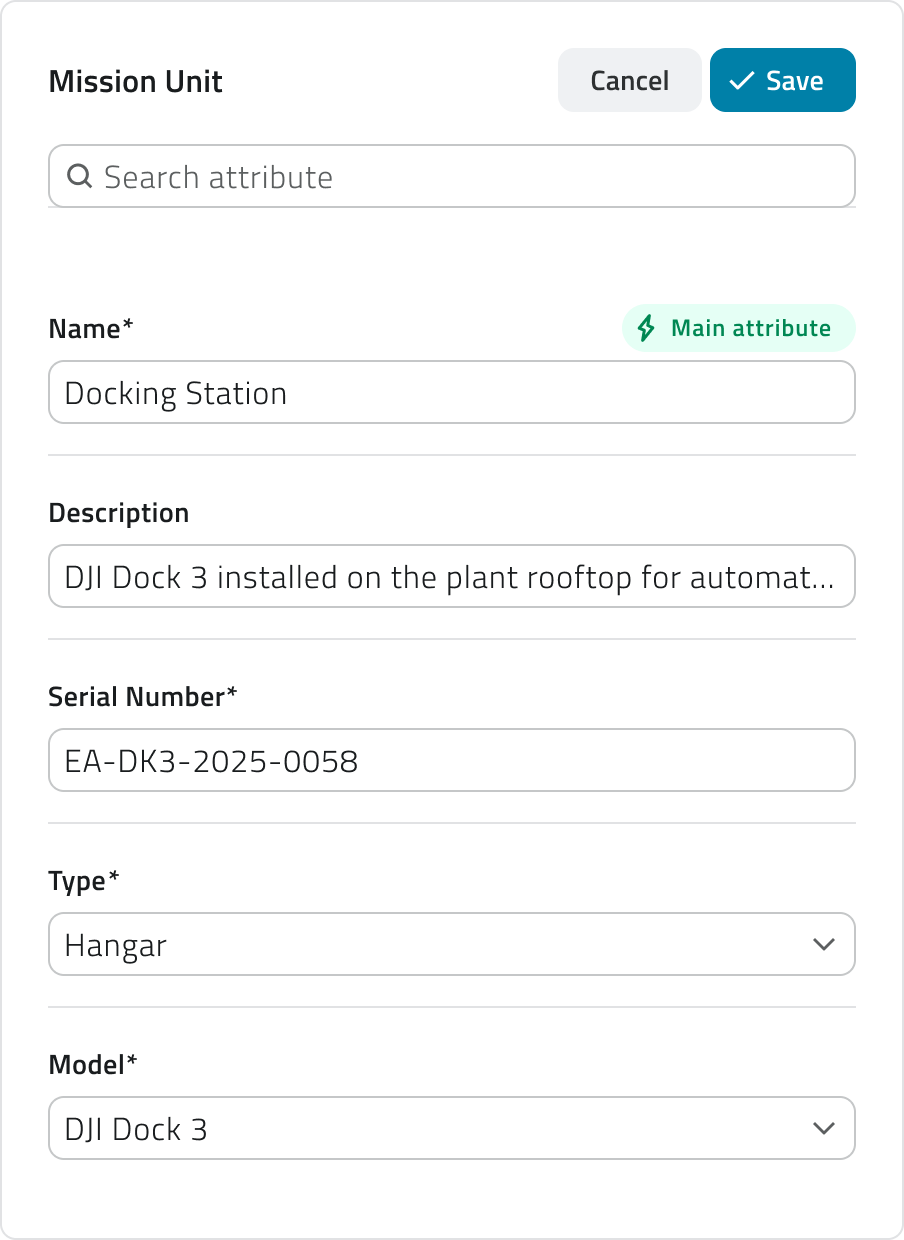
#### Hangar
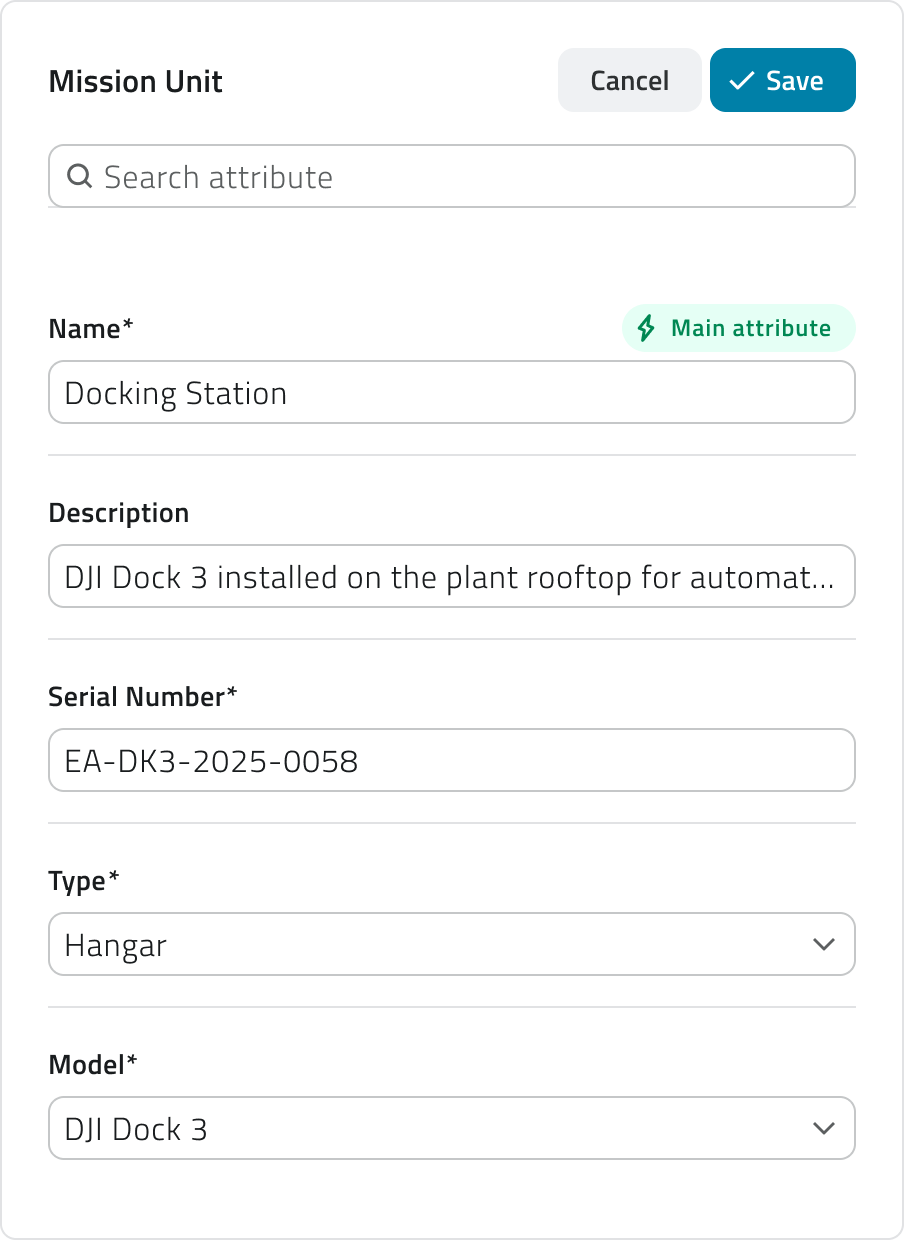
To register a **hangar**, complete the following fields:
- **Name**
- **Description**
- **Serial Number**
Unique identification code displayed on the body of the hangar.
Its position may vary depending on the model.
- **Type**
Select **Hangar** from the list.
- **Drone model**
Select the specific hangar model from the list.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/image-4.png)
To complete the **Mission Unit** registration, click **Save**.
A drone mission uses two Mission Units: a **drone** and a **hangar**. Register both.
---
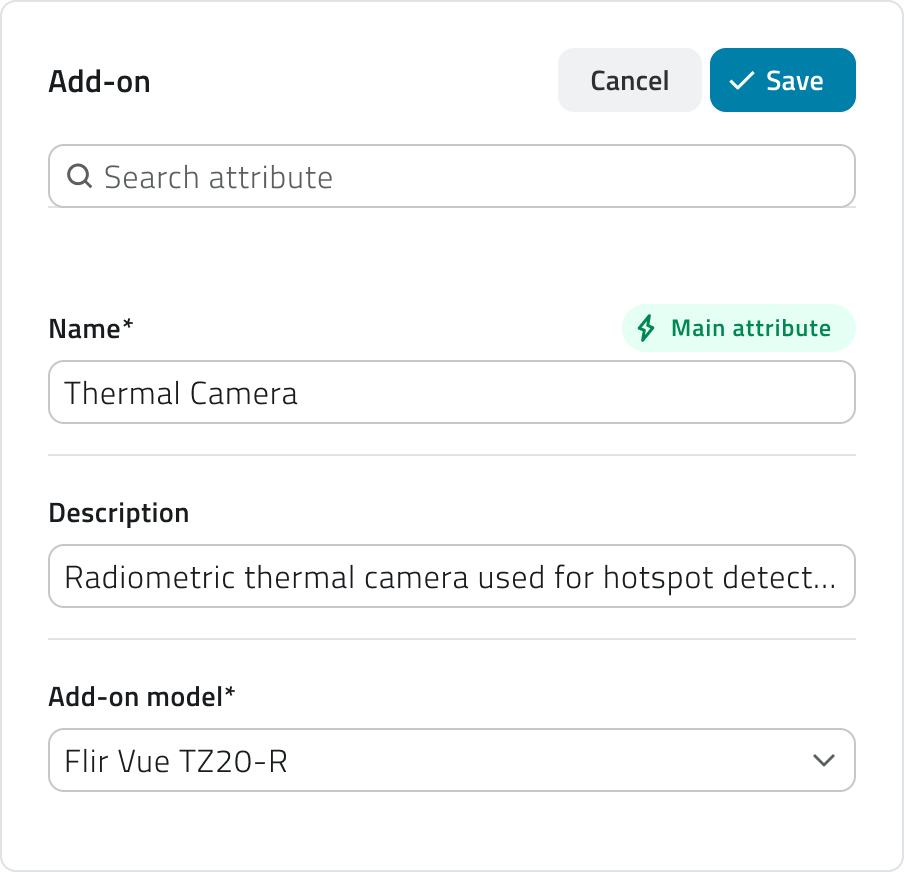
### Register an Add-on
Registering **Add-ons** is required only if you use a **Mission Unit** of type **Robot Dog**.
To **add** a new Add-on, open the **Add-ons global list** and click the **New object** button.
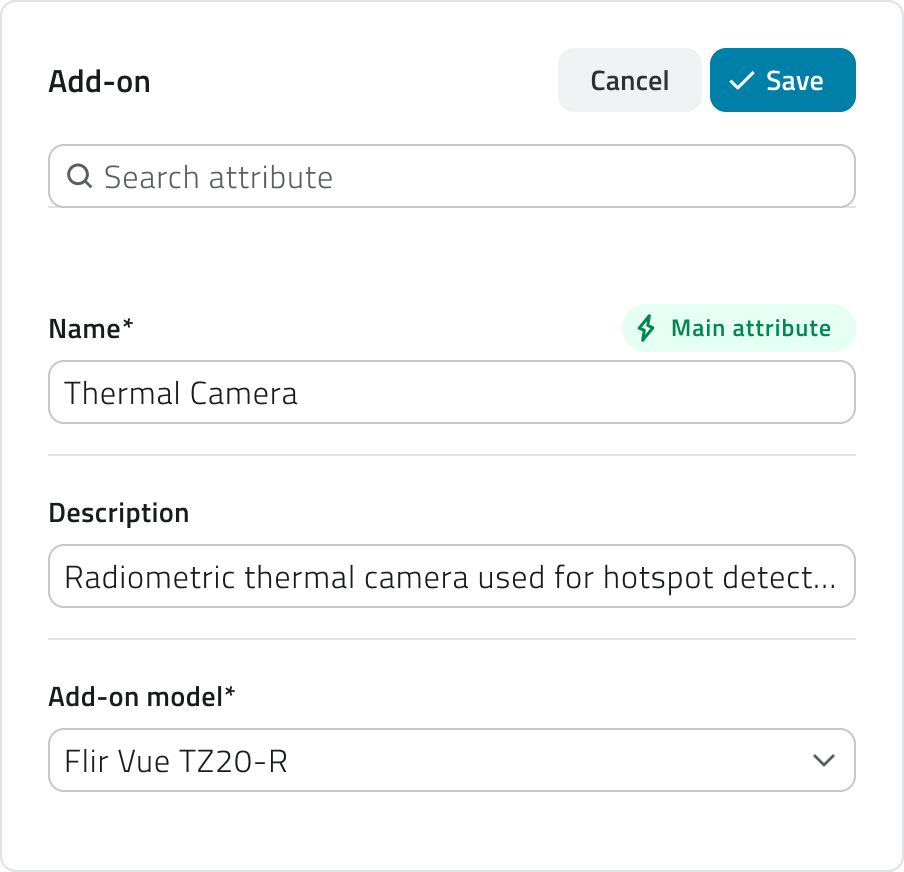
Complete the required fields:
- **Name**
- **Description**
- **Add-on Model**
Select the model of the sensor, camera or accessory to register from the list.
The list shows the models compatible with **EagleArca**.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/image-5.png)
To register the Add-on and make it available in the system, click **Save**.
If no external Add-ons are used, the **native Add-ons** of the Mission Unit must still be registered.
For **native asset**s, make sure you **know the model** of the sensor or camera installed on the Mission Unit, so that you can select the correct model. This information is available in the **technical documentation** of the Mission Unit.
If you cannot identify this information, contact support.
💡**Tip:** If an Add-on model is not available in the list, it means that it is not compatible with the platform. Make sure you use a supported model or contact support.
---
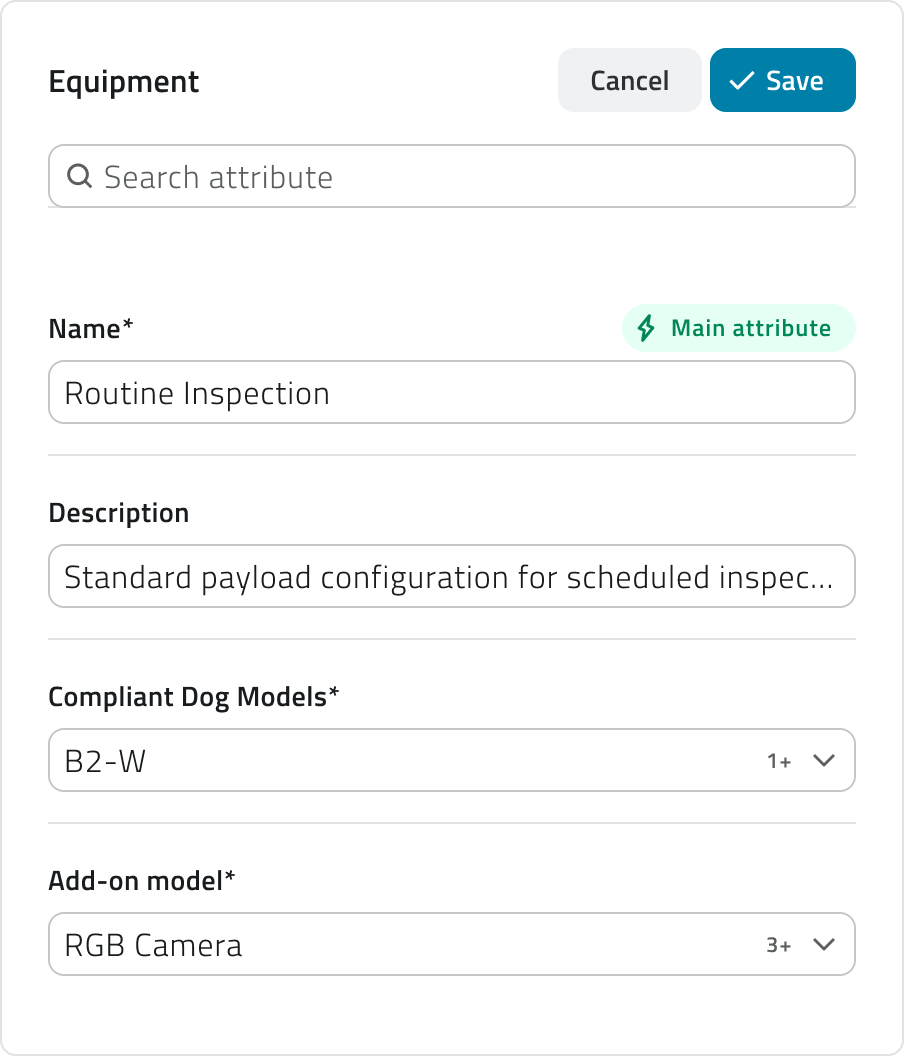
### Create an Equipment or Profile
**Equipment** can only be associated with **Mission Units** of type **Robot Dog**.
To **create** a new Equipment, open the **Equipment global list** and click the **New object** button.
Complete the required fields:
- **Name**
- **Description**
- **Compliant Dog Models**
Select the Robot Dog models compatible with the Equipment.
- **Add-on**
Select one or more previously registered Add-ons.
[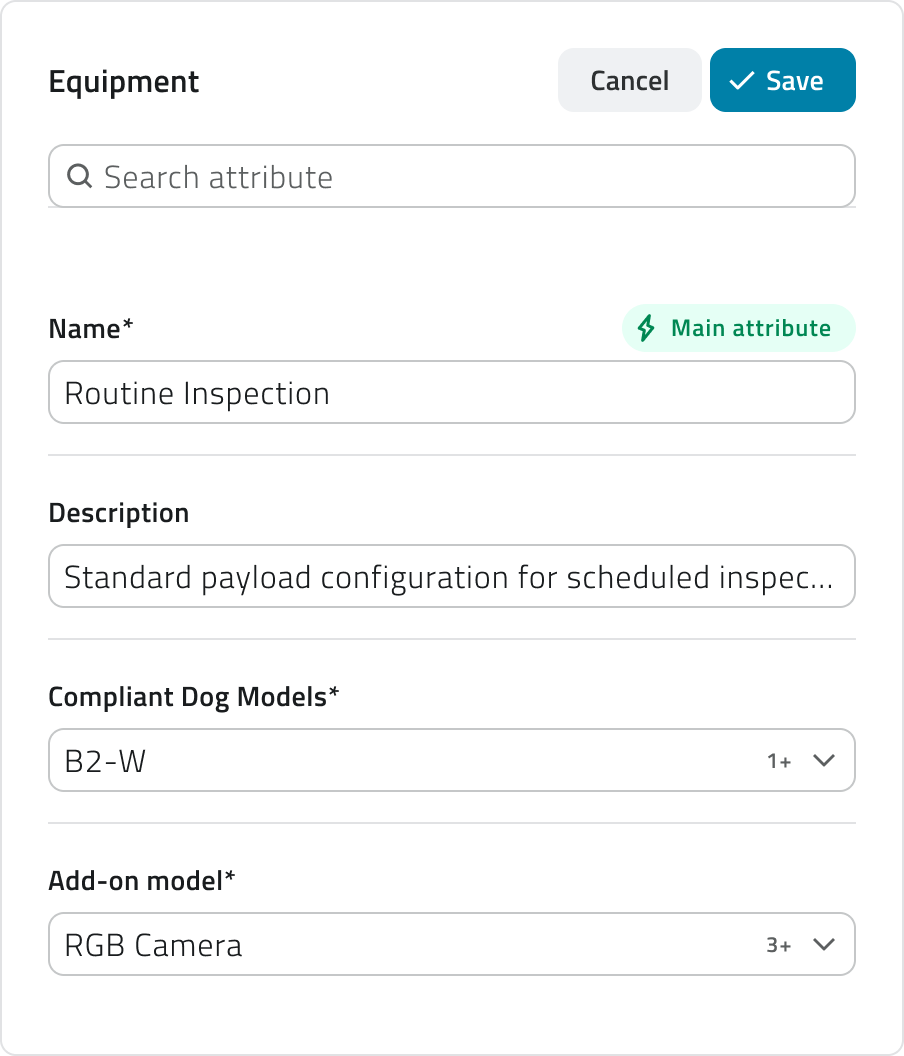](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/image-6.png)
To complete the creation of the Equipment, click **Save**. When you configure a mission, the list of available **Equipment** shows only the ones compatible with the **Mission Unit** you selected.
💡**Tip:** You can associate an Add-on with multiple Equipment, but make sure it is compatible with the selected Mission Unit models.
---
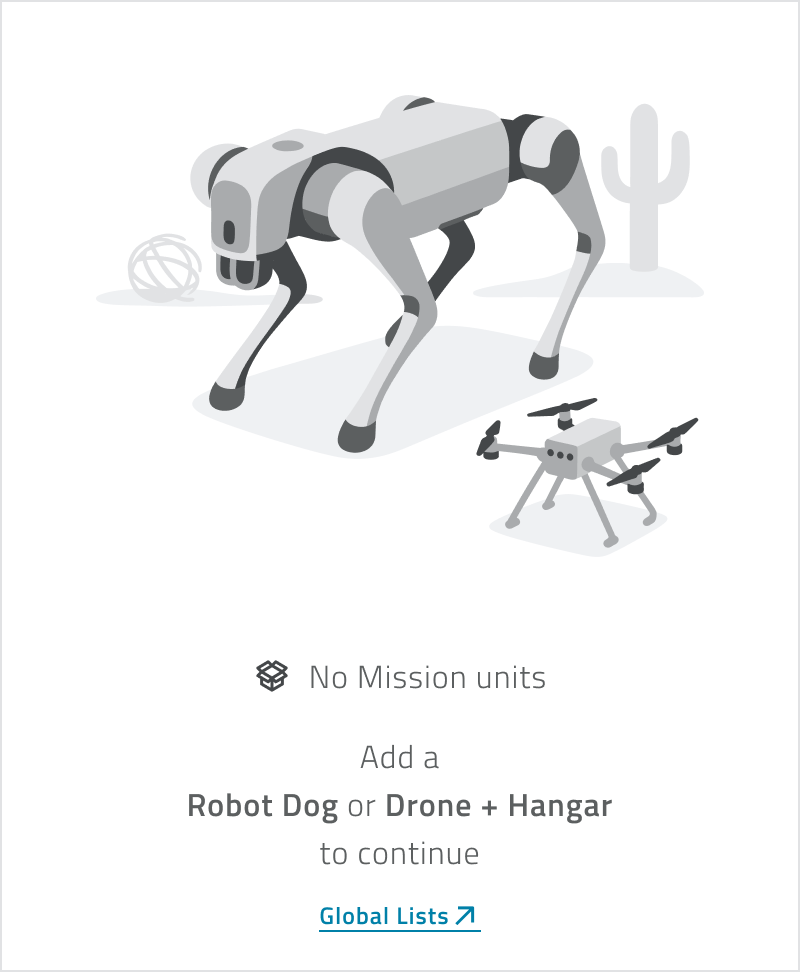
### Before you can create a mission
Mission creation starts from the **Missions** tab, in the side bar on the left, under **Live & Planned**. Two things need to be registered first:
- at least one **Mission Unit**, the unit that will carry out the mission;
- at least one **Equipment**, which defines what that unit takes with it.
A mission cannot exist without both: there would be no unit to send out, or nothing for it to work with. If either is missing, register it from the **Global Lists** and then create the mission.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/image-7.png)
---
### Links
- *[Create a global object](https://wiki.eaglearca.com/books/app-features/page/create-a-global-object "Create a global object")*: how the Global Lists work.
- *[Find and manage your missions](https://wiki.eaglearca.com/books/mission-planner-sBN/page/find-and-manage-your-missions "Find and manage your missions")*: where missions live once the setup is complete.
- *[Create a mission](https://wiki.eaglearca.com/books/mission-planner-sBN/page/create-a-mission "Create a mission")*: configure a new mission step by step.
---
[  English ](https://wiki.eaglearca.com/link/171#bkmrk-english-version) [  Italiano ](https://wiki.eaglearca.com/link/171#bkmrk-english-italiano-1)
## Configurazione iniziale
---
Prima di pianificare una missione è necessario configurare alcune **risorse di base del sistema**.
Queste configurazioni definiscono gli asset utilizzati dal **Mission Planner** all’interno dei progetti.
La configurazione iniziale viene gestita tramite le *[**Liste Globali**](https://wiki.eaglearca.com/books/app-features/page/create-a-global-object "Create a global object")* e rappresenta un prerequisito per abilitare correttamente la pianificazione delle missioni.
---
### Configurazione iniziale tramite le Liste Globali
Dalla pagina di scelta delle app, seleziona l'app su cui vuoi operare. Poi, dalla barra laterale a sinistra, apri la sezione **Liste Globali**.

Le liste principali per la pianificazione delle missioni sono:
- **Mission Unit**
Rappresentano le unità robotiche disponibili nel progetto.
- **Add-on**
Rappresentano sensori, telecamere e accessori, nativi o aggiuntivi, utilizzati a supporto degli obiettivi di missione.
- **Equipment**
Rappresentano configurazioni tecniche composte da uno o più **Add-on**. Un **Equipment** è ciò che selezioni quando configuri una missione.
---
### Censire una Mission Unit
Per utilizzare una **Mission Unit** nella pianificazione delle missioni, è necessario registrarla in piattaforma.
I modelli di Mission Unit disponibili per l'integrazione sono:
- Unitree B2
- Unitree B2 Wheel
- Unitree Go2
- DJI Matrice 4TD
- DJI Dock 3
Per **aggiungere** una nuova Mission Unit, apri la **Lista Globale** delle **Mission Units** e clicca sul pulsante **Nuovo oggetto**.
#### Robot dog
Per registrare un robot dog, compila i seguenti campi:
- **Nome**
- **Descrizione**
- **Serial Number**
Codice identificativo univoco riportato sul corpo del robot dog.
La posizione può variare in base al modello.
- **Tipo**
Seleziona **Robot dog** dall'elenco.
- **Dog model**
Seleziona dall’elenco il modello specifico del robot dog.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/ktKimage-2.png)
#### Drone
Per registrare un drone, compila i seguenti campi:
- **Nome**
- **Descrizione**
- **Serial Number**
Codice identificativo univoco riportato sul corpo del drone.
La posizione può variare in base al modello.
- **Tipo**
Seleziona **Drone** dall'elenco.
- **Drone model**
Seleziona dall’elenco il modello specifico del drone.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/Fwcimage-3.png)
#### Hangar
Per registrare un hangar, compila i seguenti campi:
- **Nome**
- **Descrizione**
- **Serial Number**
Codice identificativo univoco riportato sul corpo dell’hangar.
La posizione può variare in base al modello.
- **Tipo**
Seleziona **Hangar** dall'elenco.
- **Drone model**
Seleziona dall’elenco il modello specifico dell’hangar.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/6Ahimage-4.png)
Per completare la registrazione della Mission Unit, clicca su **Salva**.
Una missione con drone utilizza due Mission Unit: un **drone** e un **hangar**. Censiscili entrambi.
---
### Censire un Add-on
Il censimento degli **Add-on** è necessario solo se utilizzi una **Mission Unit** di tipo **Robot Dog**.
Per **aggiungere** un nuovo Add-on, apri la **Lista Globale** degli **Add-on** e clicca sul pulsante **Nuovo oggetto**.
Compila i campi richiesti:
- **Nome**
- **Descrizione**
- **Modello Add-on**
Seleziona dall’elenco il modello del sensore, della fotocamera o dell’accessorio da registrare.
La lista mostra i modelli compatibili con **EagleArca**.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/QeAimage-5.png)
Per registrare l’Add-on e renderlo disponibile nel sistema, clicca su **Salva**.
In assenza di Add-on esterni, è comunque necessario censire gli **Add-on nativi** della Mission Unit.
Per gli **asset nativi**, assicurati di **conoscere il modello** del sensore o della camera installata sulla Mission Unit, in modo da selezionare il modello corretto. Questa informazione è disponibile nella **documentazione tecnica** della Mission Unit.
Se non riesci ad individuare questa informazione contatta il supporto.
💡**Suggerimento:** Se un modello di Add-on non è presente nella lista, significa che non è compatibile con la piattaforma. Assicurati di utilizzare un modello supportato o contatta il supporto.
---
### Creare un Equipment o Profile
Gli **Equipment** possono essere associati solo a **Mission Unit** di tipo **Robot Dog**.
Per **creare** un nuovo Equipment, apri la **Lista Globale** degli **Equipment** e clicca sul pulsante **Nuovo oggetto**.
Compila i campi richiesti:
- **Nome**
- **Descrizione**
- **Compliant Dog Models**
Seleziona i modelli di Robot Dog compatibili con l’Equipment.
- **Add-on**
Seleziona uno o più Add-on precedentemente censiti.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/sr9image-6.png)
Per completare la creazione dell’Equipment, clicca su **Salva**. Quando configuri una missione, l’elenco degli **Equipment** mostra solo quelli compatibili con la **Mission Unit** selezionata.
💡**Suggerimento:** Puoi associare un Add-on a più Equipment, ma assicurati che sia compatibile con i modelli di Mission Unit selezionati.
---
### Prima di poter creare una missione
La creazione di una missione parte dalla sezione **Missioni**, nella barra laterale a sinistra, sotto **Live & Planned**. Prima però servono due elementi già censiti:
- almeno una **Mission Unit**, l'unità che eseguirà la missione;
- almeno un **Equipment**, che definisce la strumentazione a bordo dell'unità.
Senza entrambi la missione non può esistere: mancherebbe l'unità da inviare oppure l'equipaggiamento con cui operare. Se manca uno dei due, censiscilo dalle **Liste Globali** prima di creare la missione.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/Lhkimage-7.png)
---
### Collegamenti
- *[Creare un oggetto globale](https://wiki.eaglearca.com/books/app-features/page/create-a-global-object "Create a global object")*: come funzionano le Liste Globali.
- *[Trovare e gestire le missioni](https://wiki.eaglearca.com/books/mission-planner-sBN/page/find-and-manage-your-missions "Find and manage your missions")*: dove trovi le missioni una volta completata la configurazione.
- *[Creare una missione](https://wiki.eaglearca.com/books/mission-planner-sBN/page/create-a-mission "Create a mission")*: configurare una nuova missione passo per passo.
---
***Last update:** 31 July 2026*
# Find and manage your missions
The Missions tab collects every mission of the project. From here you follow what is running, resume what you have already prepared and start new ones. Open the Missions tab from the side bar on the left.
[  English ](https://wiki.eaglearca.com/link/172#bkmrk-english-italiano) [  Italiano ](https://wiki.eaglearca.com/link/172#bkmrk-english-italiano-1)
---
The **Missions** tab collects every mission of the project. From here you follow what is running, resume what you have already prepared and start new ones. Open the **Missions** tab from the side bar on the left.
---
### The Live & Planned tab
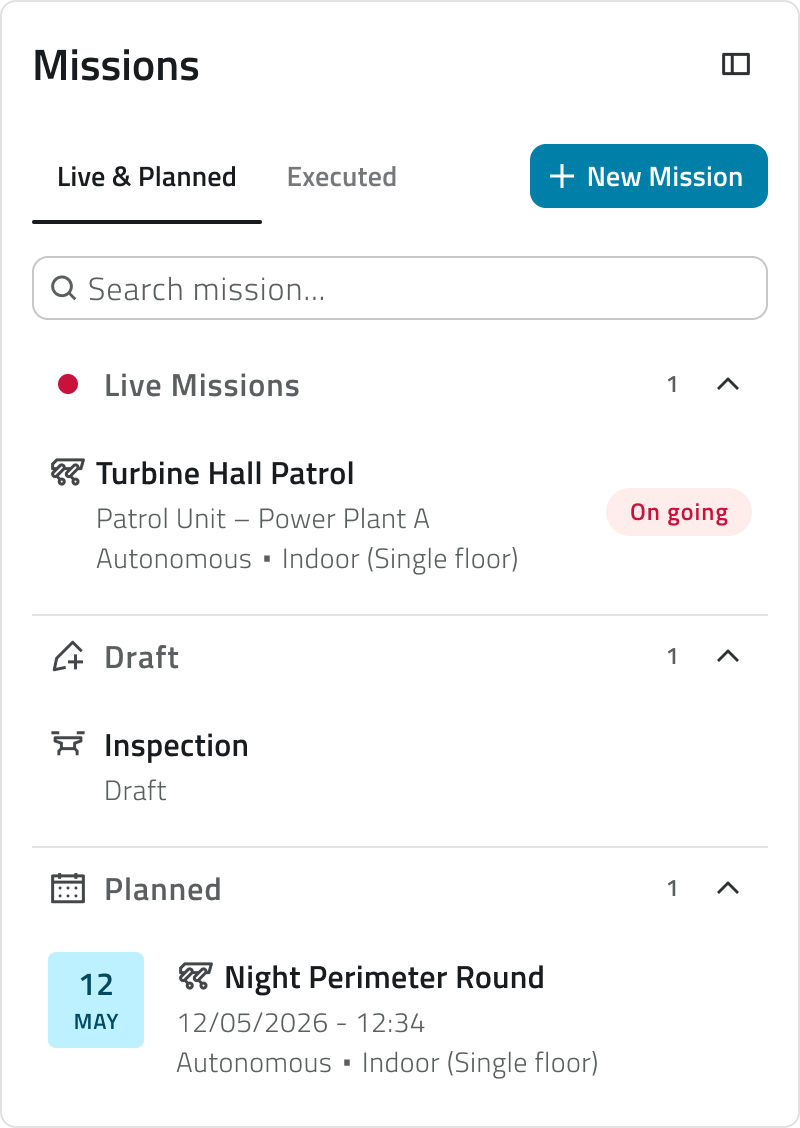
The **Missions** tab has two tabs: **Live & Planned**, which is where missions are prepared and followed, and **Executed**, which collects the missions already carried out.
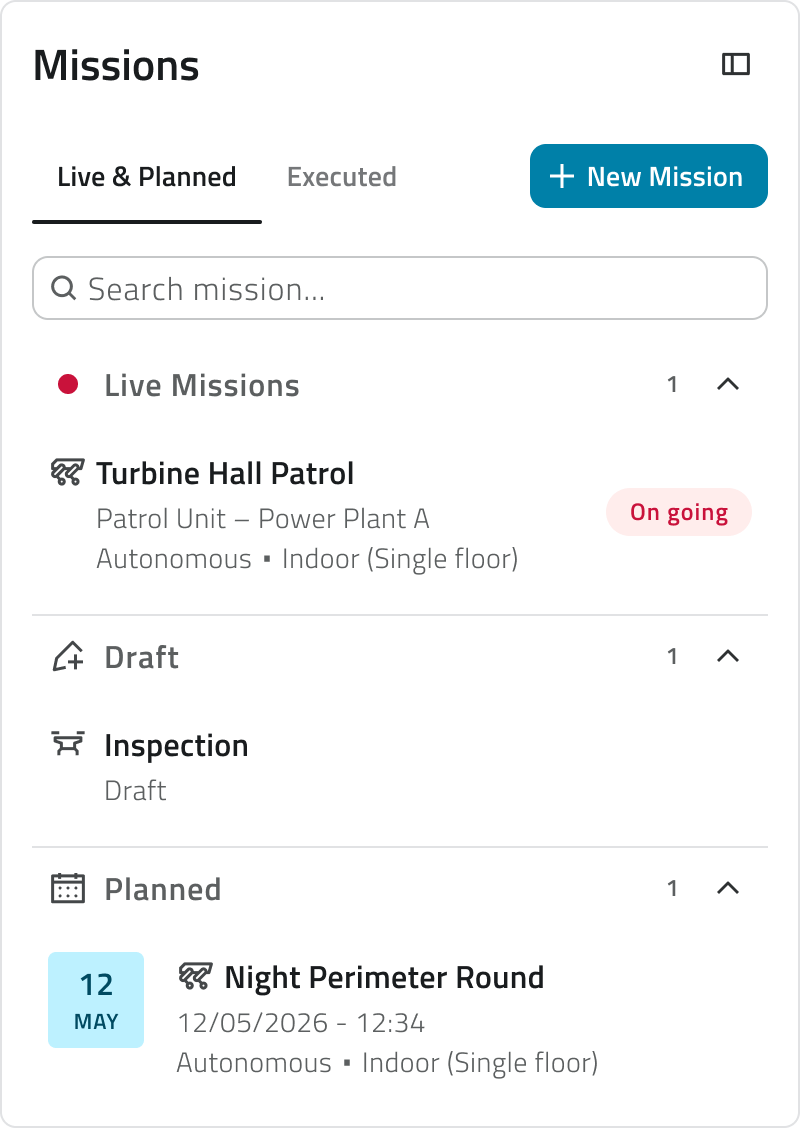
In **Live & Planned** the missions are grouped by state. Each group shows how many missions it contains and can be collapsed using the arrow next to its name.
| **Group** | **What it contains** | **What you can do** |
| **Live Missions** | Missions running right now. | Open the mission to follow it and take control of the Mission Unit. |
| **Draft** | Missions configured and saved, not started yet. A Draft is created as soon as you complete the configuration, and stays available to be reused. | Open the mission to complete or change it, then run the **Pre Check** and start it. |
| **Planned** | Missions scheduled to run at a set date and time, once or repeatedly. | Open the mission to change it before it runs. |
---
### Reading the list
Every mission shows its name and the **Mission Unit** assigned to it. The icon next to the name tells you the type of unit: robot dog, or drone and hangar.
Each group adds the information that matters for that state:
| **Group** | **What is shown** |
| **Live Missions** | For a robot dog, a status chip with what the Mission Unit is doing: **On going** while the mission is running, **RTH** while the unit is returning to its **Home Position**. |
| **Draft** | The **Draft** label. |
| **Planned** | The scheduled date, and the time the mission will start. For a repeating mission you also see **Next**, with the date and time of the following run, and a chip with the number of runs still to come. |
The status chip reports what a **robot dog** is doing. Missions running with a **drone** are listed without it.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/keGimage-1.png)
---
### Find a mission
The search bar filters the list by name and keeps the grouping: each group then holds only the missions that match.
💡**Tip:** When a project holds many missions, collapse the groups you are not working on using the arrow next to the group name, so that the one you need stays in view.
---
### Open a mission
Click a mission to open it. Where you land depends on its state:
- a **Live** mission opens on the live view, where you follow it and control the Mission Unit.
- a **Draft** or **Scheduled** mission opens on the mission editor.
When you open a **Draft** or **Scheduled** mission, the initial setup you have already completed is not requested again. To change it, open the **Details** section and select **Edit mission details**.
---
### Save a mission as a draft
On the planning screen, **Save as a Draft** stores the mission with everything you have defined so far. You can save whenever there is something new to keep; once the mission is saved, there is nothing left to save until you change something again.
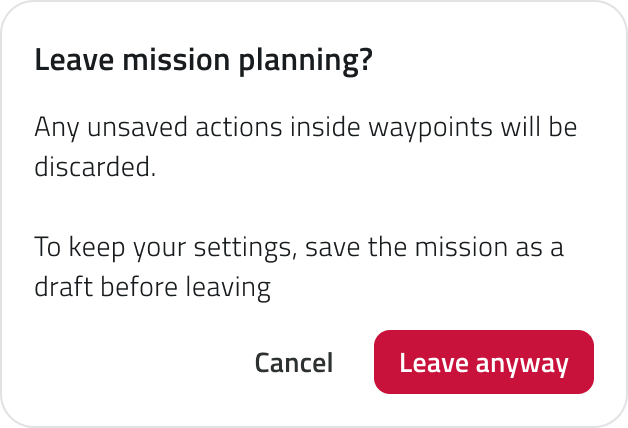
If you leave the planning screen with unsaved changes, a confirmation is asked before you go.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/xiaimage-2.png)
Going ahead discards the actions configured on the **Waypoints** that have not been saved. Save the mission as a draft first to keep them.
---
### Delete a mission
Deleting a mission removes it from the project together with everything defined on it. The confirmation says how many occurrences are about to be deleted.
To delete more than one mission at a time, hold **CTRL** and click the ones you need; **CTRL** and click on a mission that is already selected takes it out of the selection.

Deletion is permanent and cannot be undone.
---
### Start a new mission
The **New Mission** button, at the top of the **Live & Planned** tab, opens the configuration of a new mission.
A **Mission Unit** and an **Equipment** must be registered before a mission can be created. If either is missing, a message explains what to register.
---
### Links
- *[Create a mission](https://wiki.eaglearca.com/books/mission-planner-sBN/page/create-a-mission "Create a mission")*: configure a new mission step by step.
- *[Draw the mission on the map](https://wiki.eaglearca.com/books/mission-planner-sBN/page/draw-the-mission-on-the-map "Draw the mission on the map")*: what you can do on the planning screen.
- *[Initial Setup](https://wiki.eaglearca.com/books/mission-planner-sBN/page/initial-setup "Initial Setup")*: register Mission Units, Add-ons and Equipment.
---
[  English ](https://wiki.eaglearca.com/link/172#bkmrk-english-italiano) [  Italiano ](https://wiki.eaglearca.com/link/172#bkmrk-english-italiano-1)
## Trova e gestisci le tue missioni
---
La scheda **Missioni** raccoglie tutte le missioni del progetto. Da qui puoi seguire quelle in corso, riprendere quelle già preparate e avviarne di nuove. Apri la scheda **Missioni** dalla barra laterale sinistra.
---
### La sezione Live & Planned
**Missioni** si divide in due sezioni: **Live & Planned**, dove le missioni si preparano e si seguono, ed **Eseguite**, che raccoglie quelle già eseguite.
In **Live & Planned** le missioni sono raggruppate per stato. Ogni gruppo indica quante missioni contiene e si comprime con la freccia accanto al nome.
| **Gruppo** | **Cosa contiene** | **Cosa puoi fare** |
| **Live Missions** | Le missioni in esecuzione in questo momento. | Aprire la missione per seguirla e intervenire sulla Mission Unit. |
| **Bozze** | Le missioni configurate e salvate, non ancora avviate. Una Bozza viene creata appena completi la configurazione e resta disponibile per essere ripresa. | Aprire la missione per completarla o modificarla, poi eseguire il **Pre Check** e avviarla. |
| **Pianificate** | Le missioni pianificate per una data e un'ora, una sola volta oppure a ripetizione. | Aprire la missione per modificarla prima che venga eseguita. |
---
### Leggere l'elenco
Ogni missione mostra il nome e la **Mission Unit** assegnata. L'icona accanto al nome indica il tipo di unità: robot dog, oppure drone e hangar.
Ogni gruppo riporta l'informazione più utile per quello stato:
| **Gruppo** | **Cosa viene mostrato** |
| **Live Missions** | Per un robot dog, un chip che indica cosa sta facendo la Mission Unit: **In corso** mentre la missione è in corso, **RTH** mentre l'unità sta rientrando alla **Home Position**. |
| **Bozze** | L'etichetta **Bozza**. |
| **Pianificate** | La data pianificata e l'ora di avvio. Se la missione si ripete, compare anche la voce **Prossima**, con la data e l'ora dell'esecuzione più imminente, e un chip che indica quante esecuzioni restano. |
Il chip di stato riguarda soltanto il **robot dog**: per una missione in corso con un **drone** non compare.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/qKaimage-1.png)
---
### Trovare una missione
La barra di ricerca filtra l'elenco per nome, mantenendo la divisione in gruppi: dentro ciascuno rimangono soltanto le missioni corrispondenti.
💡**Tip:** Se un progetto contiene molte missioni, comprimi con la freccia i gruppi su cui non stai lavorando, così resta in vista solo quello che ti serve.
---
### Aprire una missione
Clicca una missione per aprirla: la schermata su cui arrivi dipende dal suo stato:
- una missione **Live** si apre sulla vista in diretta, dove la segui e comandi la Mission Unit.
- una missione **Bozza** o **Pianificata** si apre sull'editor della missione.
Aprendo una missione **Bozza** o **Pianificata,** la configurazione iniziale che hai già completato non viene richiesta di nuovo. Per modificarla, apri la sezione **Dettagli** e seleziona **Modifica i dettagli della missione**.
---
### Salvare una missione come bozza
Nella schermata di pianificazione, **Salva come bozza** salva la missione con tutto ciò che hai definito fino a quel momento. Puoi salvare ogni volta che c'è qualcosa di nuovo; una volta salvata la missione, non resta nulla da salvare finché non la modifichi.
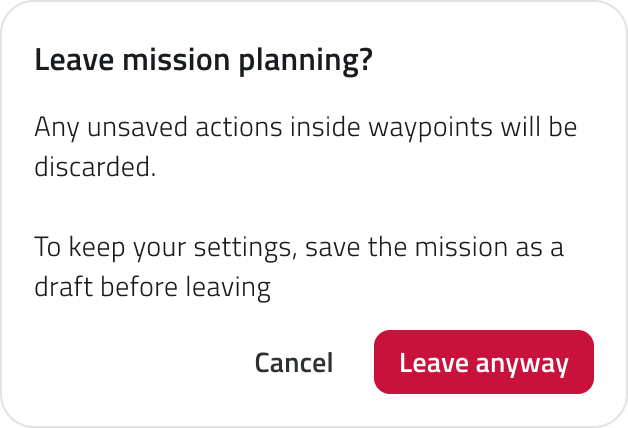
Se esci dalla schermata di pianificazione con modifiche non salvate ti viene chiesta conferma.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/VGqimage-2.png)
Proseguendo, le azioni configurate sui **Waypoints** e non salvate vengono perse: salva la missione come bozza per conservarle.
---
### Eliminare una missione
Eliminando una missione, dal progetto vengono rimossi anche tutti gli elementi definiti al suo interno. La conferma indica quante occorrenze verranno eliminate.
💡**Tip:** Per eliminare più missioni insieme, tieni premuto **CTRL** e clicca quelle che ti servono; con **CTRL** + clic su una missione già selezionata la togli dalla selezione.

L'eliminazione è permanente e non può essere annullata.
---
### Avviare una nuova missione
Il pulsante **Nuova missione**, in alto nella sezione **Live & Planned**, apre la configurazione di una nuova missione.
Per creare una missione servono almeno una **Mission Unit** e un **Equipment** già censiti. Se manca uno dei due, un messaggio indica cosa censire.
---
### Collegamenti
- *[Creare una missione](https://wiki.eaglearca.com/books/mission-planner-sBN/page/create-a-mission "Create a mission")*: configurare una nuova missione passo per passo.
- *[Disegnare la missione in mappa](https://wiki.eaglearca.com/books/mission-planner-sBN/page/draw-the-mission-on-the-map "Draw the mission on the map")*: cosa puoi fare nella schermata di pianificazione.
- *[Configurazione iniziale](https://wiki.eaglearca.com/books/mission-planner-sBN/page/initial-setup "Initial Setup")*: censire Mission Unit, Add-on ed Equipment.
---
***Last update:** 31 July 2026*
# Create a Mission
Configuring a mission takes five steps. You choose the unit to deploy, what it carries, what kind of mission it is, where it runs and when it starts. At the end the mission is created as a Draft and the planning screen opens, where you place the route on the map.
[  English ](https://wiki.eaglearca.com/link/173#bkmrk-english-italiano) [  Italiano ](https://wiki.eaglearca.com/link/173#bkmrk-english-italiano-1)
---
Configuring a mission takes **five steps**. You choose the unit to deploy, what it carries, what kind of mission it is, where it runs and when it starts. At the end the mission is created as a **Draft** and the planning screen opens, where you place the route on the map.
Start from the **Missions** tab, **Live & Planned**, with the **New Mission** button.
A **Mission Unit** and an **Equipment** must be registered before a mission can be created.
---
### Which path you are on
The configuration adapts to what you choose. These are the main combinations, and they differ in the number of steps and in what you define along the way.
| **Path** | **Steps** | **Map** | **Home Position** | **On the map** |
| Robot dog, **Autonomous** | 5 | Chosen from the **Maps Library** | Marked automatically | **Waypoints**, **Geofencing**, **Danger Zones** |
| Robot dog, **Discovery** | **4** | Built by the robot dog during the mission | Marked automatically | Nothing to place |
| **Drone** | 5 | Geographic, fixed | Drawn on the map | **Waypoints** |
Move between the steps with **Next** and **Back**. The numbers at the bottom show where you are and how many steps are left.
---
### Step 1: Mission Unit to deploy
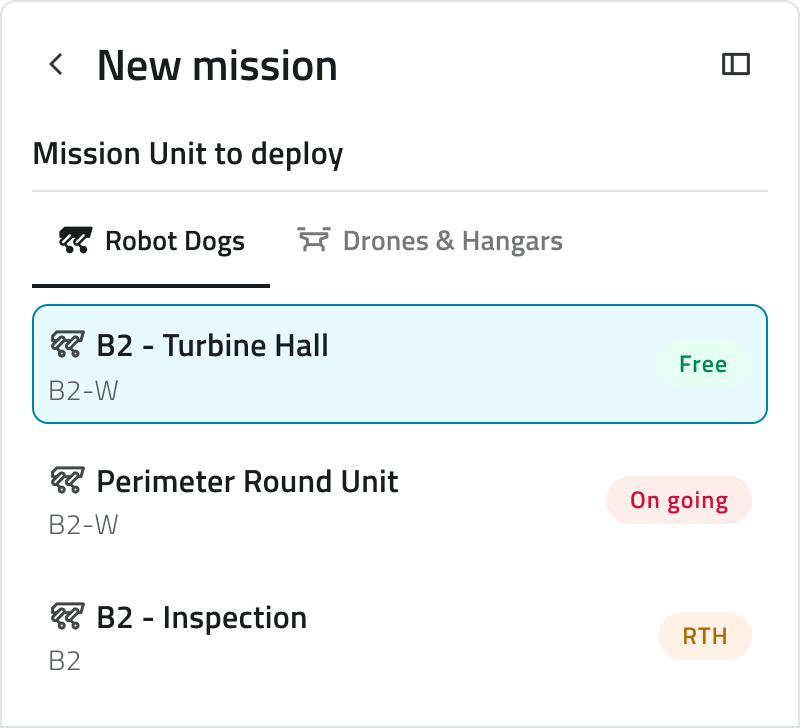
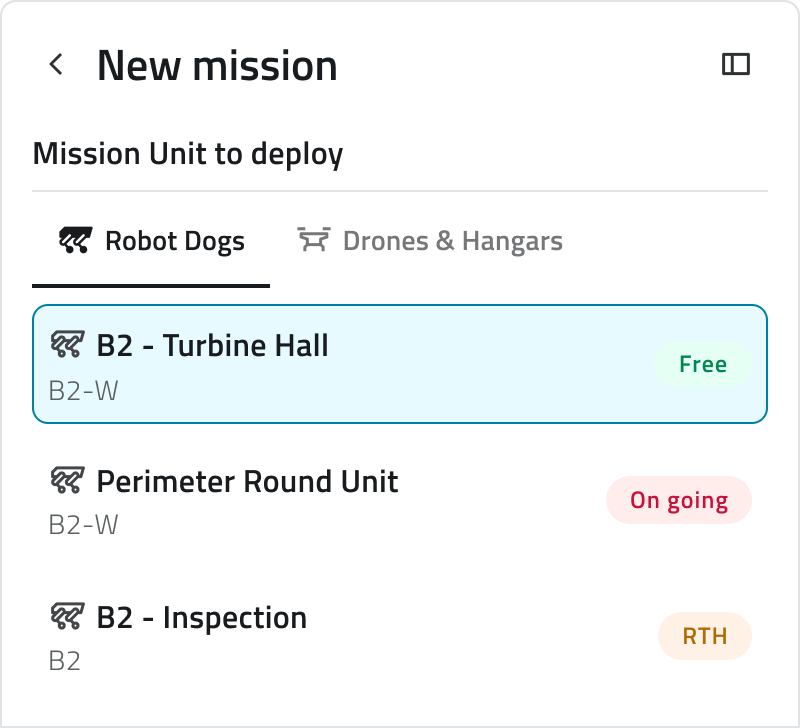
Choose the unit that will carry out the mission. Two tabs separate the types: **Robot Dogs** and **Drones & Hangars**.
Each robot dog displays its name and model.
A mission with a robot dog uses **one unit**.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/zrCimage-1.png)
A mission with a drone uses **two units**: one drone and one hangar, both required, one of each. Select both to continue. Until you do, a message reminds you.
---
### Step 2: Equipment & AI Algorithm
Here you decide how to equip the unit and what it will be able to do during the mission, through three sections: **Equipment**, **AI Algorithms** and **Continuous Actions**.
#### Equipments
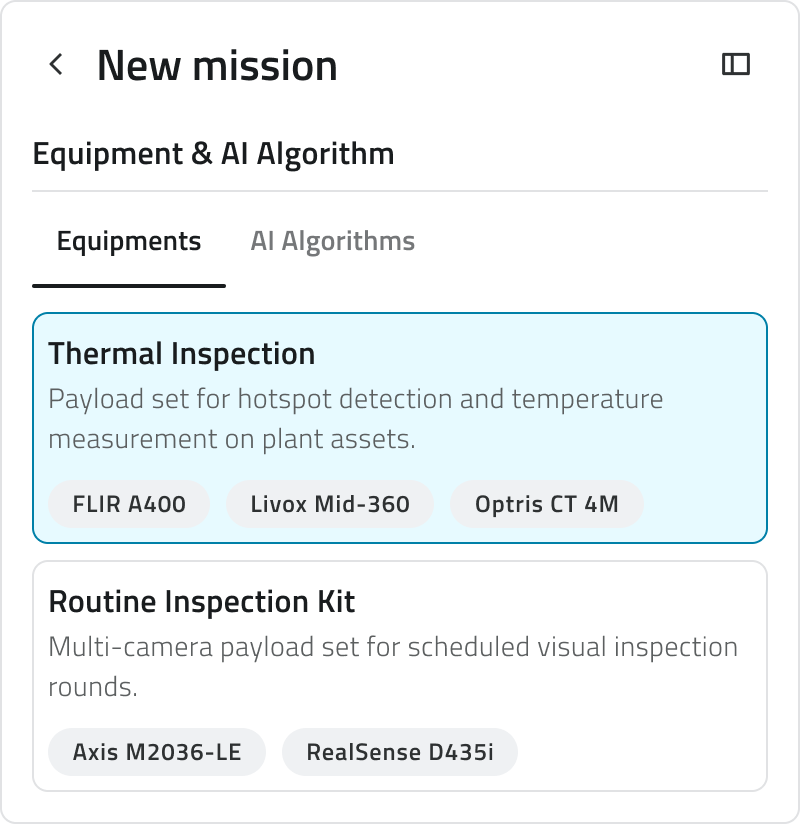
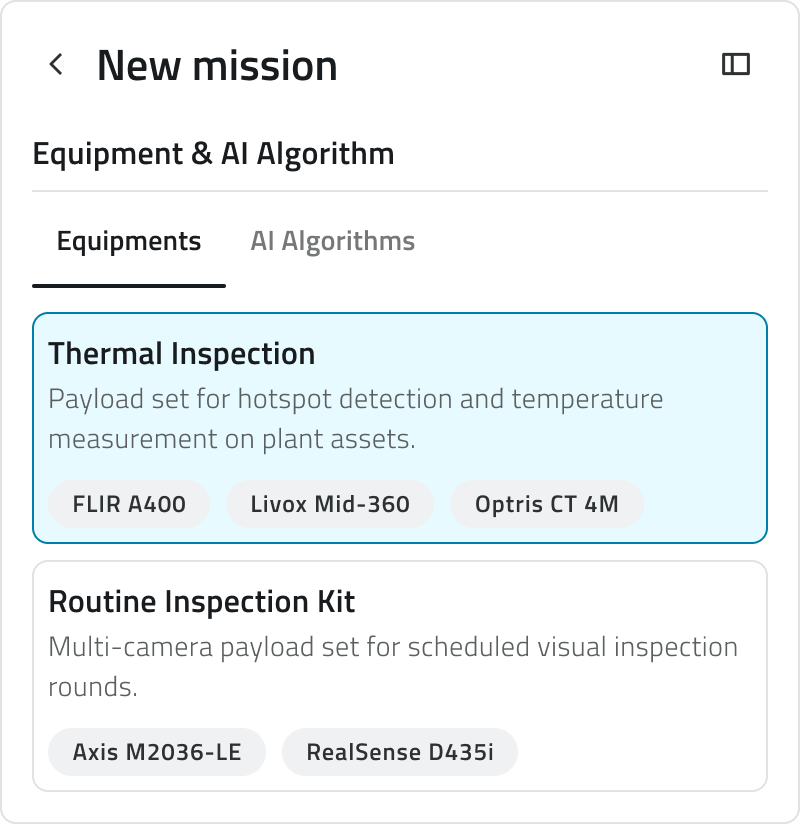
Select the **Equipment** the unit will carry. Each card shows the name, the description and the add-on models it contains.
Only the Equipment compatible with the unit chosen at step 1 is listed. Equipment is defined in advance from the **Global Lists**: here you pick one, you do not assemble it.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/3Qhimage-2.png)
#### AI Algorithms
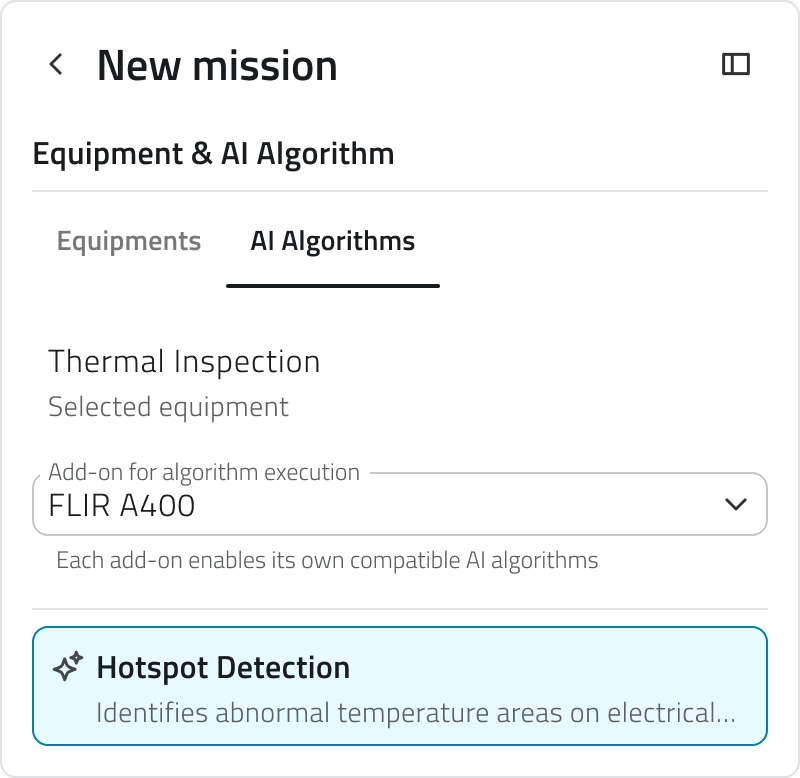
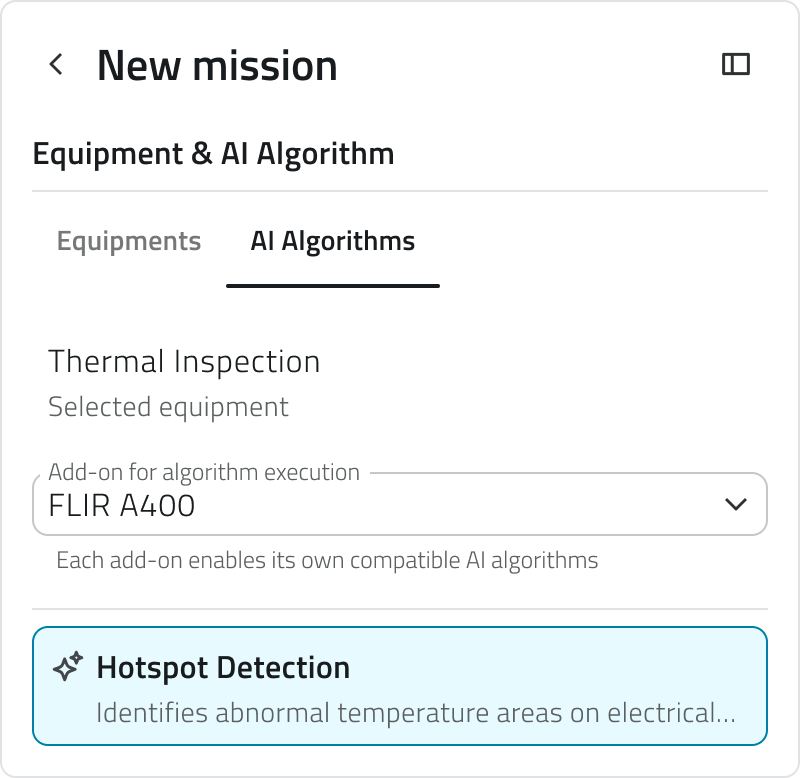
Assign an algorithm that will run on one of the add-ons. Select an **Equipment** first, then choose the add-on that will carry out the algorithm and the algorithm itself: each add-on works with its own compatible algorithms.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/1G5image-3.png)
#### Continuous Actions
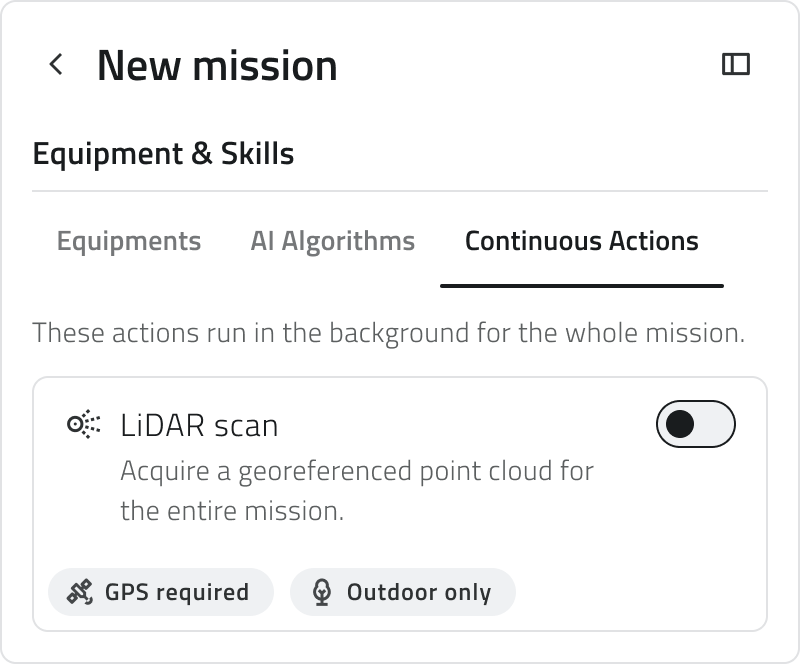
Continuous actions run in the background for the whole mission, from the moment it starts. Turn on the ones you need with their switch.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-09/continuous-actions.png)
A continuous action can be turned on when the mission satisfies the conditions on its card. For example, **LiDAR scan** needs an **Equipment** that includes GPS and an outdoor mission.
---
### Step 3: Mission Name & Typology
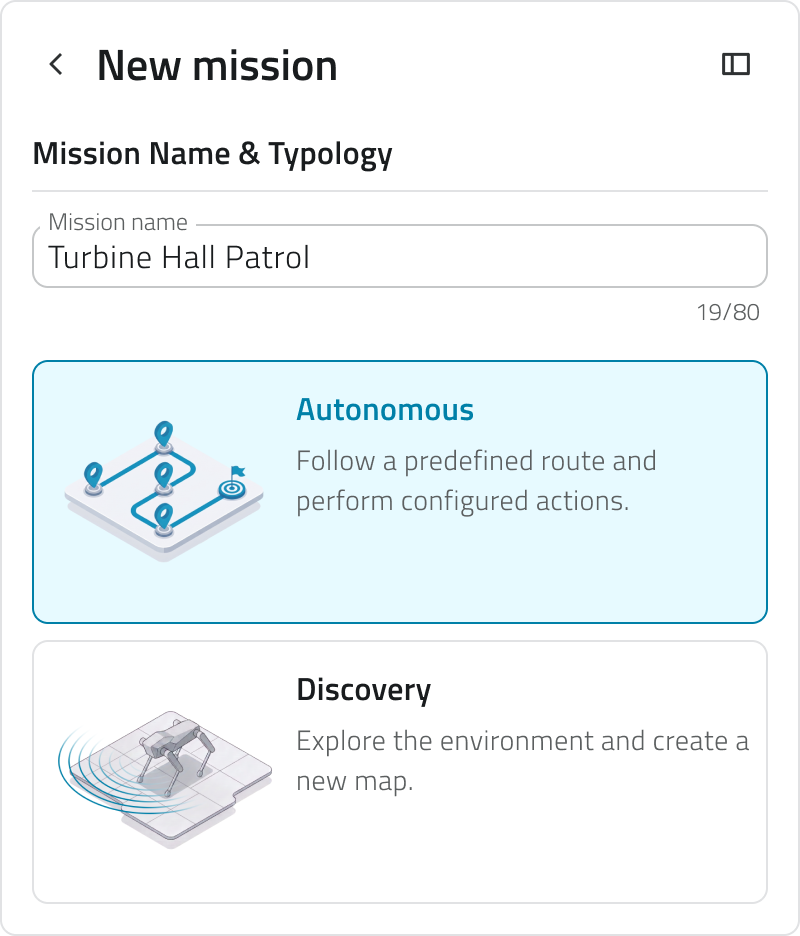
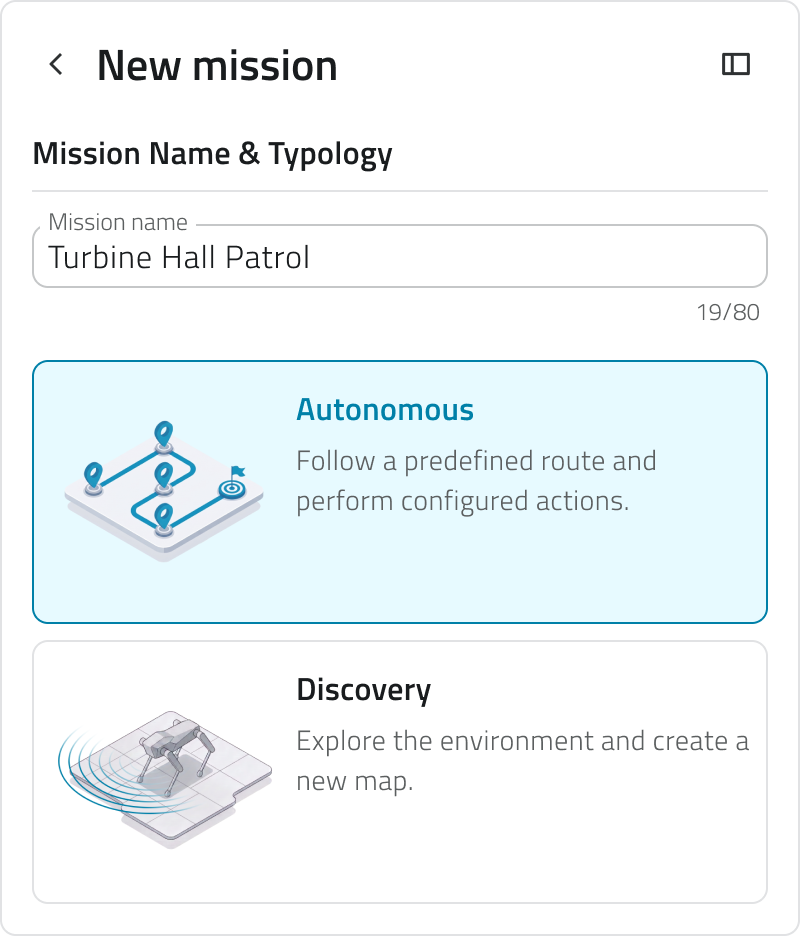
Give the mission a name, up to 80 characters, then choose the typology:
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/TdEimage-5.png)
| **Typology** | **What the mission does** |
| **Autonomous** | The unit follows a route you define and performs the actions you configure on each waypoint. |
| **Discovery** | The robot dog explores the environment and builds a new map of it. |
Selecting **Discovery** removes the **Mission Environment** step: the map is produced by the mission itself, so there is nothing to choose. The configuration continues on **Launch Mode**.
Discovery missions don't support AI algorithms: **any algorithm you had already selected is cleared**.
A mission with a drone is always **Autonomous**, so you find the typology already chosen for you.
---
### Step 4: Mission Environment
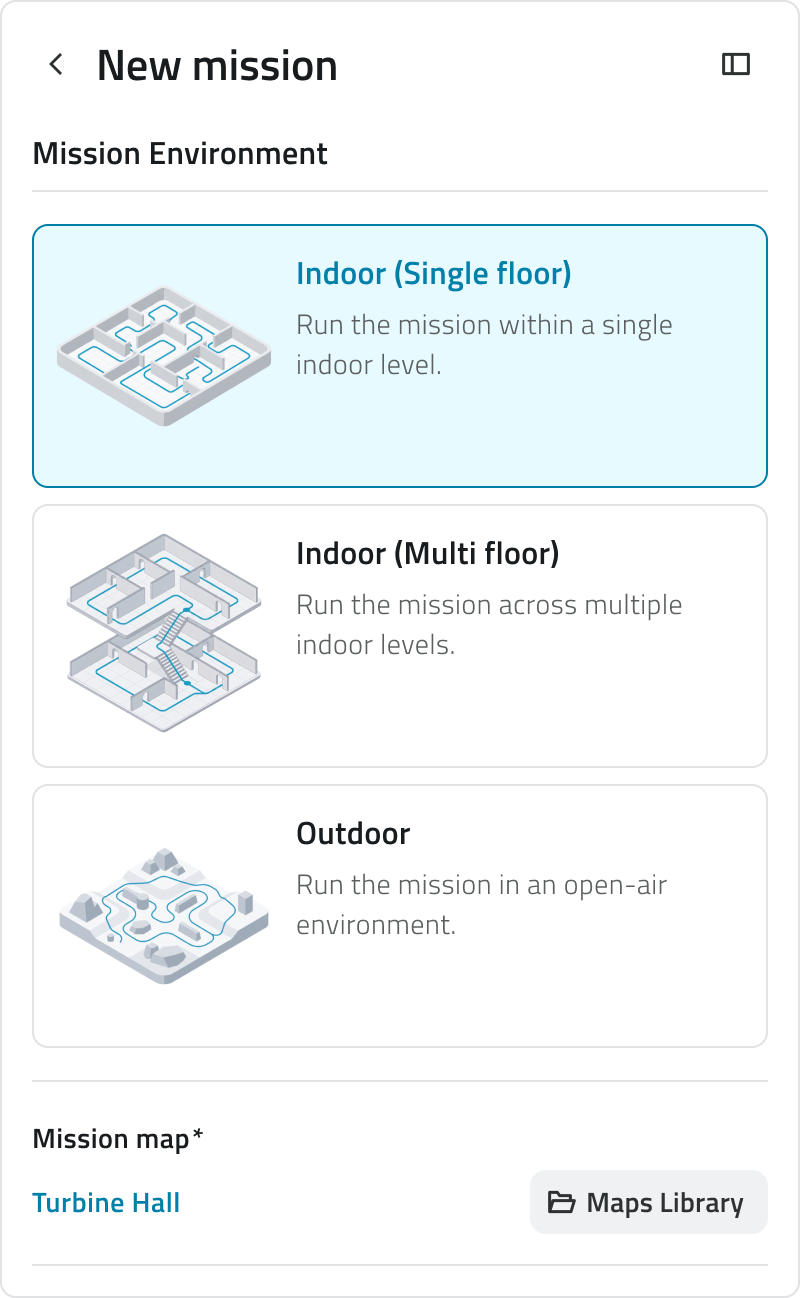
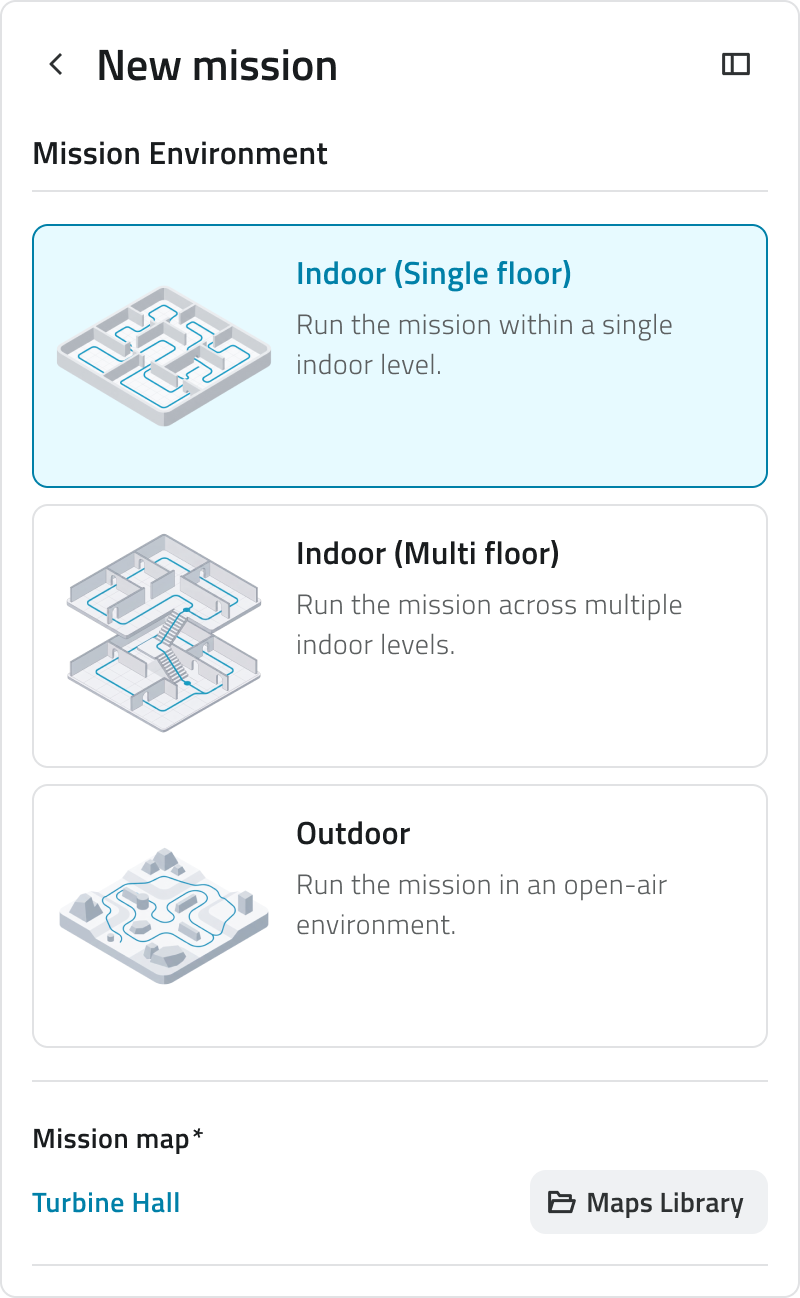
Choose where the mission runs, then which map it runs on.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/Fxaimage-6.png)
| **Environment** | **Where the mission runs** |
| **Indoor (Single floor)** | Within a single indoor level. |
| **Indoor (Multi floor)** | Across several indoor levels. |
| **Outdoor** | In an open-air environment. |
Once the environment is chosen, select the map under **Mission map**: open **Maps Library**, pick a map from the list and confirm with **Apply**. The list shows only the maps that suit the environment you selected, and the preview shows the map with its type and the date of its last change. You need to select a map before you can move on to the next step.
An environment you cannot select means the project has no map of that type. Associate a suitable map with the project, then start the configuration again.
#### Drone: Outdoor and flight parameters
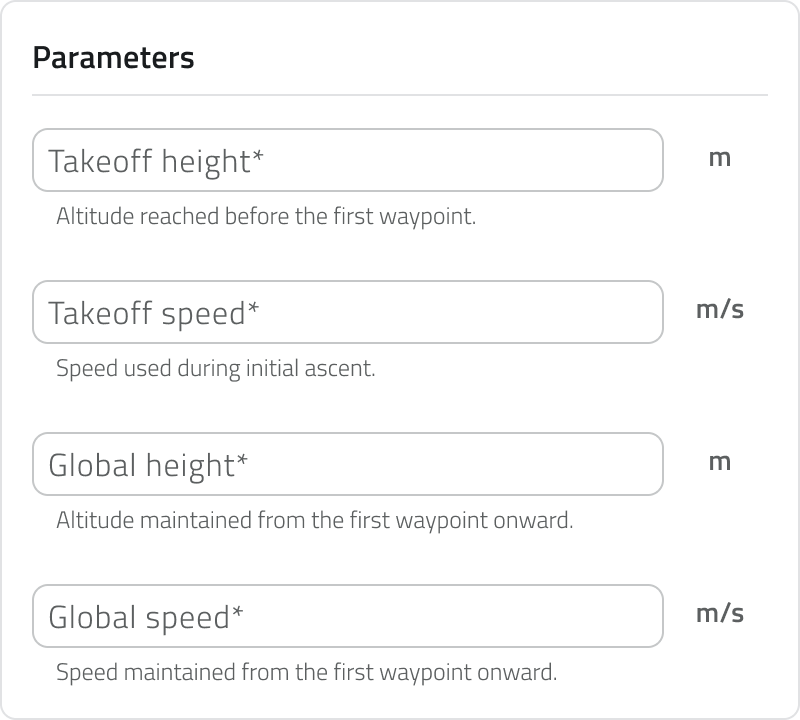
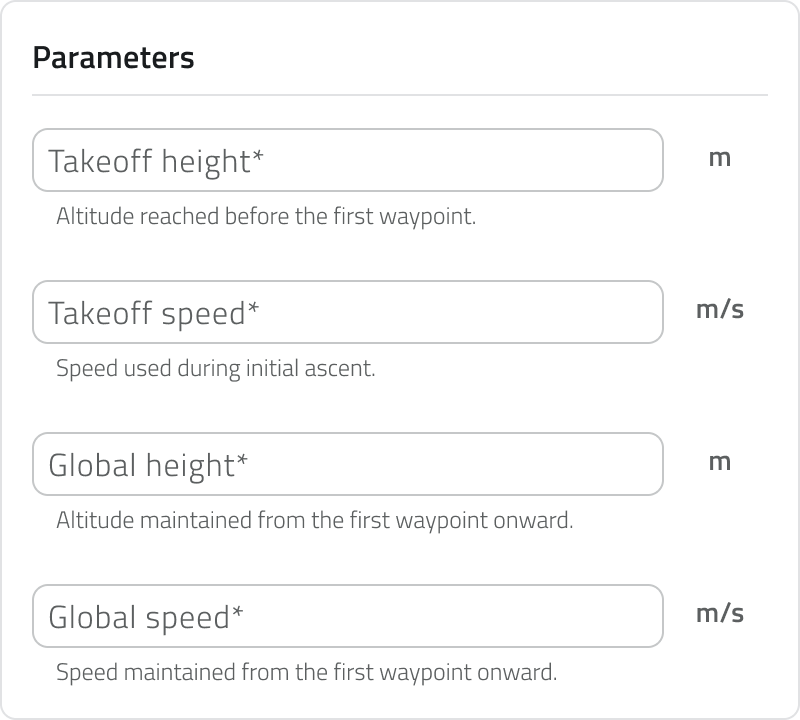
A mission with a drone always runs **Outdoor**, on a geographic map. This step asks instead for the flight parameters:
| **Parameter** | **What it sets** |
| **Takeoff height** | The altitude reached before the first waypoint. |
| **Takeoff speed** | The speed used during the initial ascent. |
| **Global height** | The altitude maintained from the first waypoint onward. |
| **Global speed** | The speed maintained from the first waypoint onward. |
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/ODximage-7.png)
---
### Step 5: Launch Mode
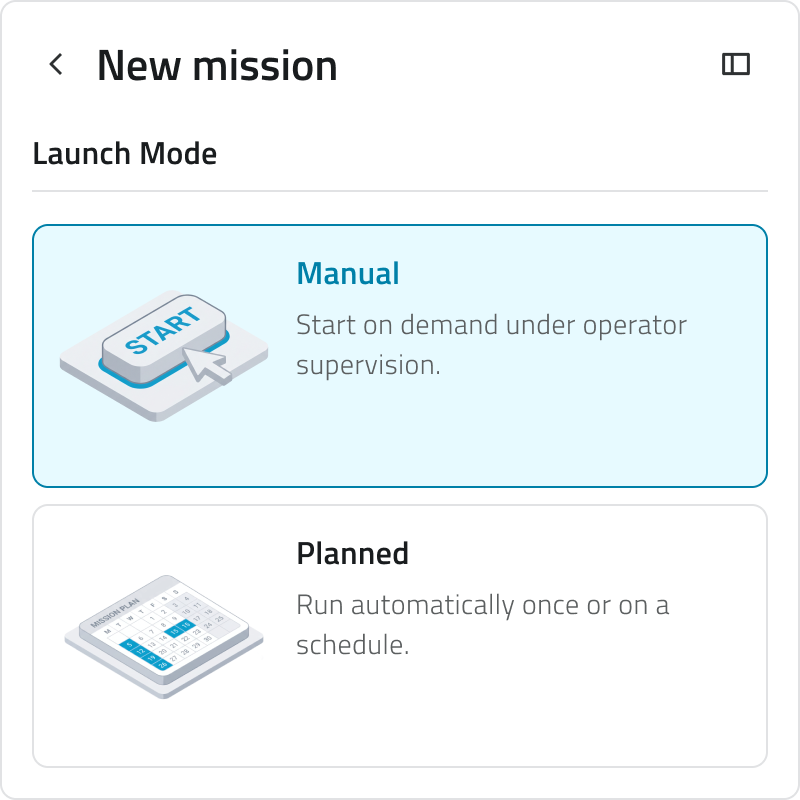
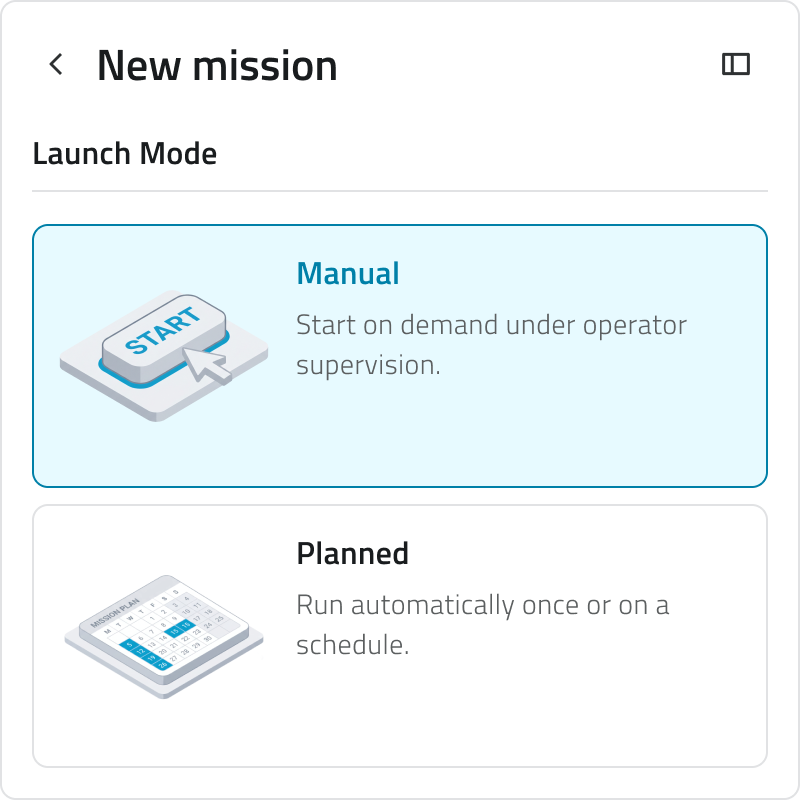
Decide when the mission starts:
| **Launch Mode** | **When the mission starts** |
| **Manual** | On demand, under the supervision of an operator. |
| **Planned** | Automatically, at the date and time you set. It can be a one-time event or a recurring one: daily or only on the days of the week you choose. |
Selecting **Planned** opens the scheduling options, where you can set the start date and time. From here you can also enable recurrence, choosing between a daily rhythm and custom days of the week. In all cases, the **Preview in calendar** button shows a preview of the slots on the calendar.
A mission with a drone always starts in **Manual** mode, so you find it already chosen for you.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/image-8.png)
---
### What happens when you select Proceed
**Proceed** closes the configuration. In sequence, the mission is created as a **Draft**, the platform connects to the **Mission Unit**, and the planning screen opens.
For a robot dog the **Home Position** is marked automatically, at the point where the unit is. For a drone you draw it on the map from the planning screen.
If the **Mission Unit** cannot be reached, nothing of your work is lost: the mission is created as a **Draft** and you can retry with **Retry Mission Unit Connection**. The **Home Position** and the **Pre Check** stay out of reach until the connection succeeds, because both depend on what the unit reports.
---
### Leaving the configuration
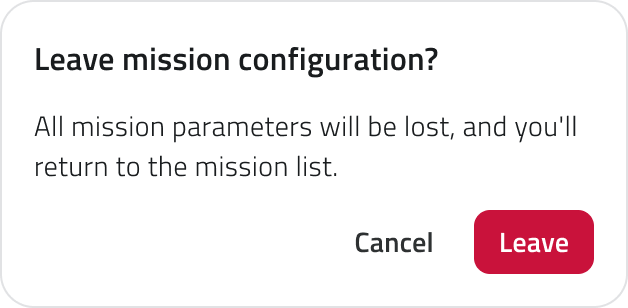
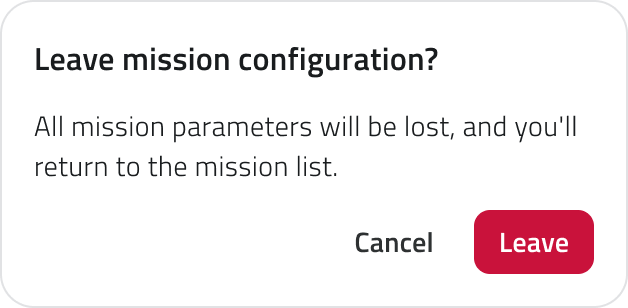
Leaving the configuration before **Proceed** asks for a confirmation: **Leave mission configuration?** Choose **Cancel** to stay, or **Leave** to return to the mission list.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/image-9.png)
Leaving discards all the mission parameters: nothing is kept, because the mission has not been created yet.
---
### Links
- *[Draw the mission on the map](https://wiki.eaglearca.com/books/mission-planner-sBN/page/draw-the-mission-on-the-map "Draw the mission on the map")*: where you land after **Proceed**.
- *[Schedule a mission](https://wiki.eaglearca.com/books/mission-planner-sBN/page/schedule-a-mission "Schedule a mission")*: the options behind **Planned**.
- *[Edit a mission's configuration](https://wiki.eaglearca.com/books/mission-planner-sBN/page/edit-a-missions-configuration "Edit a mission's configuration")*: change these choices later.
---
[  English ](https://wiki.eaglearca.com/link/173#bkmrk-english-italiano) [  Italiano ](https://wiki.eaglearca.com/link/173#bkmrk-english-italiano-1)
## Creare una Missione
---
La configurazione di una missione si svolge in **cinque step**: scegli l'unità da impiegare, la sua strumentazione, il tipo di missione, l'ambiente in cui si svolge e il momento in cui parte. Al termine la missione viene creata come **Bozza** e si apre la schermata di pianificazione, dove disegni il percorso sulla mappa.
Si parte dalla sezione **Missioni**, in **Live & Planned**, con il pulsante **Nuova missione**.
Per creare una missione servono almeno una **Mission Unit** e un **Equipment** già censiti.
---
### Quale percorso stai seguendo
La configurazione si adatta alle tue scelte. Queste sono le combinazioni principali, che cambiano il numero di step e gli elementi da definire.
| **Percorso** | **Step** | **Mappa** | **Home Position** | **In mappa** |
| Robot dog, **Autonoma** | 5 | Scelta dalla **Libreria mappe** | Marcata in automatico | **Waypoints**, **Geofencing**, **Zone di pericolo** |
| Robot dog, **Esplorativa** | **4** | Costruita dal robot dog durante la missione | Marcata in automatico | Niente da collocare |
| **Drone** | 5 | Geografica, fissa | Disegnata in mappa | **Waypoints** |
Per muoverti tra gli step usa **Avanti** e **Indietro**. I numeri in basso indicano a che punto sei e quanti step restano.
---
### Step 1: Mission Unit da schierare
Scegli l'unità che eseguirà la missione: due sezioni separano i tipi, **Robot Dog** e **Droni & Hangar**.
Ogni robot dog mostra il nome e il suo modello.
Una missione con robot dog usa **una sola unità**.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/zrCimage-1.png)
Una missione con drone usa **due unità**: un drone e un hangar, entrambi obbligatori, uno per tipo. Selezionali per proseguire; finché non lo fai, un messaggio te lo ricorda.
---
### Step 2: Equipment & AI Algorithm
Qui decidi come equipaggiare l'unità e cosa sarà in grado di fare durante la missione, attraverso tre sezioni: **Equipment**, **Algoritmi AI** e **Azioni continuative**.
#### Equipment
Seleziona l'**Equipment** con cui l'unità eseguirà la missione. Ogni card riporta nome, descrizione e i modelli di Add-on che contiene.
L'elenco mostra solo gli Equipment compatibili con l'unità scelta allo step 1. Gli Equipment vengono definiti in precedenza dalle **Liste Globali**: qui si sceglie tra quelli esistenti.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/V2Vimage-2.png)
#### Algoritmi AI
Assegna un algoritmo a uno degli add-on. Scegli prima un **Equipment**, poi l'add-on che eseguirà l'algoritmo e infine l'algoritmo stesso: ogni add-on funziona con i propri algoritmi compatibili.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/YYLimage-3.png)
#### Azioni continuative
Le azioni continuative restano attive dall'avvio e per tutta la durata della missione. Attiva quelle che ti servono con l'interruttore sulla card.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-09/continuous-actions.png)
Puoi attivare un'azione continuativa solo se la missione soddisfa le condizioni riportate sulla sua card. **LiDAR scan**, per esempio, richiede un **Equipment** con GPS e una missione all'aperto.
---
### Step 3: Nome Missione & Tipologia
Dai un nome alla missione, fino a 80 caratteri, poi scegli la tipologia:
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/dvdimage-5.png)
| **Tipologia** | **Cosa fa la missione** |
| **Autonoma** | L'unità segue un percorso che definisci tu ed esegue le azioni configurate su ciascun waypoint. |
| **Esplorativa** | Il robot dog esplora l'ambiente e ne costruisce una nuova mappa. |
Scegliendo **Esplorativa**, lo step **Ambiente della missione** non compare: la mappa viene prodotta dalla missione stessa, quindi non c'è nulla da scegliere. La configurazione prosegue con **Modalità di avvio**.
Le missioni esplorative non supportano gli algoritmi AI: **quelli già selezionati vengono rimossi**.
Una missione con drone è sempre **Autonoma**, quindi trovi la tipologia già scelta per te.
---
### Step 4: Ambiente della missione
Scegli dove si svolge la missione, poi su quale mappa.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/JbMimage-6.png)
| **Ambiente** | **Dove si svolge la missione** |
| **Interno (piano unico)** | Su un solo livello al chiuso. |
| **Interno (multipiano)** | Su più livelli al chiuso. |
| **All'aperto** | In un ambiente all'aperto. |
Per la mappa apri **Libreria mappe**, seleziona una voce dall'elenco e conferma con **Applica**. L'elenco mostra solo le mappe adatte all'ambiente scelto, mentre l'anteprima ne riporta il tipo e la data dell'ultima modifica. Per passare allo step successivo devi aver scelto una mappa.
Se non riesci a selezionare un ambiente, significa che il progetto non ha mappe di quel tipo. Associa al progetto una mappa adatta, poi riavvia la configurazione.
#### Drone: All'aperto e parametri di volo
Una missione con drone si svolge sempre **All'aperto**, su mappa geografica: in questo step imposti quindi i parametri di volo.
| **Parametro** | **Cosa imposta** |
| **Altezza di decollo** | La quota raggiunta prima del primo waypoint. |
| **Velocità di decollo** | La velocità usata durante la salita iniziale. |
| **Altezza globale** | La quota mantenuta dal primo waypoint in poi. |
| **Velocità globale** | La velocità mantenuta dal primo waypoint in poi. |
**[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/xajimage-7.png)**
---
### Step 5: Modalità di avvio
Decidi quando parte la missione:
| **Modalità di avvio** | **Quando parte la missione** |
| **Manuale** | Su richiesta, sotto la supervisione di un operatore. |
| **Pianificata** | In automatico, alla data e all'ora che imposti. Può essere singola oppure in serie: giornaliera o solo nei giorni della settimana che scegli. |
Scegliendo **Pianificata** si aprono le opzioni di pianificazione, dove imposti data e ora dell'avvio. Da qui puoi anche attivare la ripetizione, scegliendo tra cadenza giornaliera e giorni della settimana personalizzati. In tutti i casi, il pulsante **Anteprima nel calendario** mostra l'anteprima degli slot sul calendario.
Una missione con drone parte sempre in modalità **Manuale**, quindi la trovi già scelta per te.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/fbuimage-8.png)
---
### Cosa succede quando selezioni Procedi
**Procedi** chiude la configurazione. Nell'ordine: la missione viene creata come **Bozza**, la piattaforma si collega alla **Mission Unit** e si apre la schermata di pianificazione.
Per il robot dog la **Home Position** viene marcata in automatico, nel punto in cui si trova l'unità. Per il drone la disegni in mappa dalla schermata di pianificazione.
Se la **Mission Unit** non è raggiungibile il lavoro non va perso: la missione viene creata come **Bozza** e puoi ritentare con **Riprova la connessione alla Mission Unit**. **Home Position** e **Pre Check** restano fuori portata finché il collegamento non riesce, perché dipendono dai dati dell'unità.
---
### Uscire dalla configurazione
Se esci dalla configurazione prima di **Procedi** ti viene chiesta una conferma: **Esci dalla configurazione della missione?** Scegli **Annulla** per restare, oppure **Esci** per tornare all'elenco delle missioni.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/0IJimage-9.png)
Uscendo perdi tutti i parametri impostati, perché la missione non è ancora stata creata.
---
### Collegamenti
- *[Disegnare la missione in mappa](https://wiki.eaglearca.com/books/mission-planner-sBN/page/draw-the-mission-on-the-map "Draw the mission on the map")*: dove arrivi dopo il **Procedi**.
- *[Pianificare una missione](https://wiki.eaglearca.com/books/mission-planner-sBN/page/schedule-a-mission "Schedule a mission")*: le opzioni dietro **Pianificata**.
- *[Modificare la configurazione di una missione](https://wiki.eaglearca.com/books/mission-planner-sBN/page/edit-a-missions-configuration "Edit a mission's configuration")*: cambiare queste scelte in un secondo momento.
---
***Last update:** 14 September 2026*
# Draw the mission on the map
On the planning screen you place the mission on the map: the Home Position the unit returns to, the Waypoints it travels through, the actions it performs along the way, and any areas that limit where it may go.
[  English ](https://wiki.eaglearca.com/link/174#bkmrk-english-italiano) [  Italiano ](https://wiki.eaglearca.com/link/174#bkmrk-english-italiano-1)
---
On the planning screen you place the mission on the map: the **Home Position** the unit returns to, the **Waypoints** it travels through, the actions it performs along the way, and any areas that limit where it may go.
You reach this screen in two ways: at the end of the configuration of a new mission, or by opening a **Draft** mission from the mission list.
The panel on the left holds four tabs (**Waypoints**, **Details**, **In view** and **Streaming**), and the map fills the rest of the screen. At the bottom, **Save as a Draft** keeps your work and **Pre Check** moves on to the checks before the start.
---
### The connection to the Mission Unit
When you open the mission, the platform automatically connects to the assigned Mission Unit: it's the unit that reports its own position, and without it you can't set the Home Position or run the Pre Check.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/U42image-1.png)
If the connection fails, check that the unit is switched on and in range, then select **Retry Mission Unit connection**.
---
### The Home Position
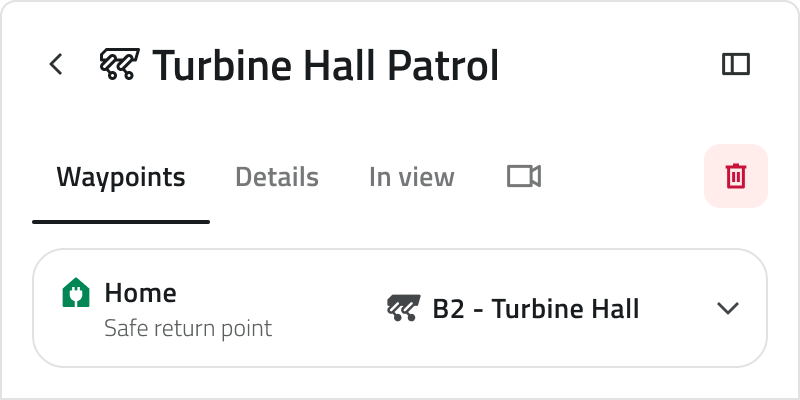
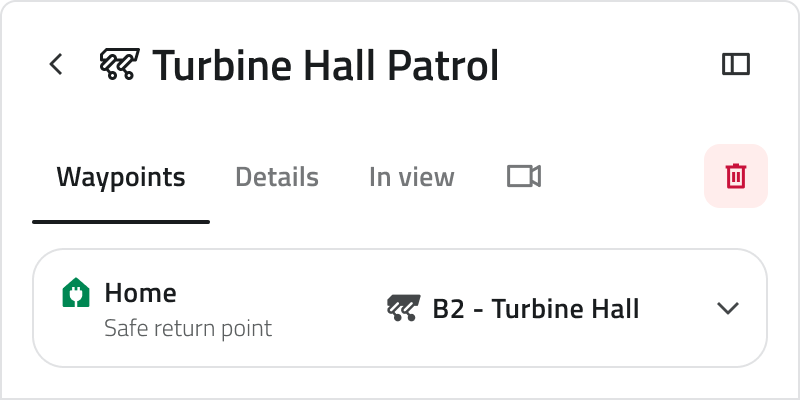
The **Home Position** is the point the unit starts from and returns to at the end of the mission. It appears at the top of the **Waypoints** tab, together with the unit assigned to the mission.
#### Robot Dog
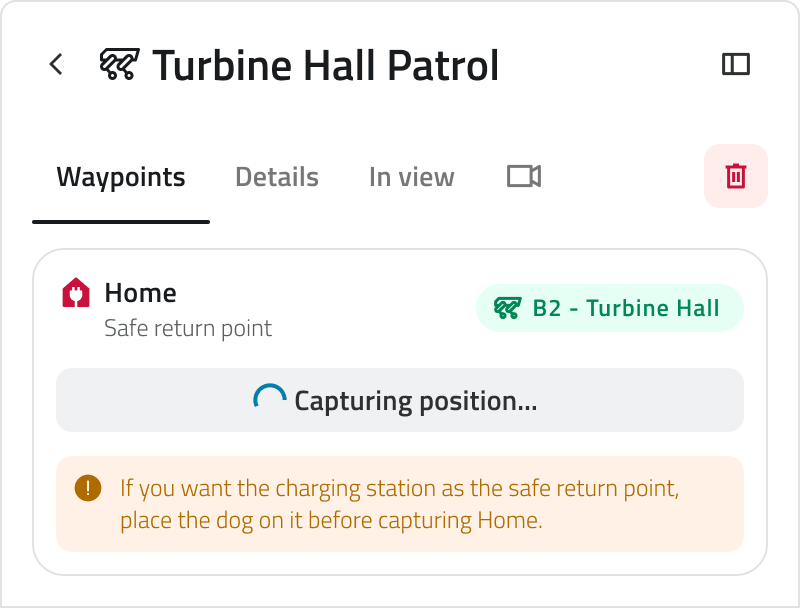
For a **robot dog**, the Home Position is set automatically at the point where the unit stands, with no need to place it manually. Once acquired, it can be removed or updated to the current position of the unit by selecting **Recapture Home Position**.
For the **robot dog**, once the Mission Unit is connected, click **Capture Home Position**: the platform records the point where the unit currently stands. If you want the robot dog to return to the charging station at the end of the mission, place it on the station before capturing the position.
Starting from the charging station is **strongly recommended for Discovery missions**.
Once captured, you can update the Home Position using **Recapture Home Position**.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/8Dximage-2.png)
#### Drone
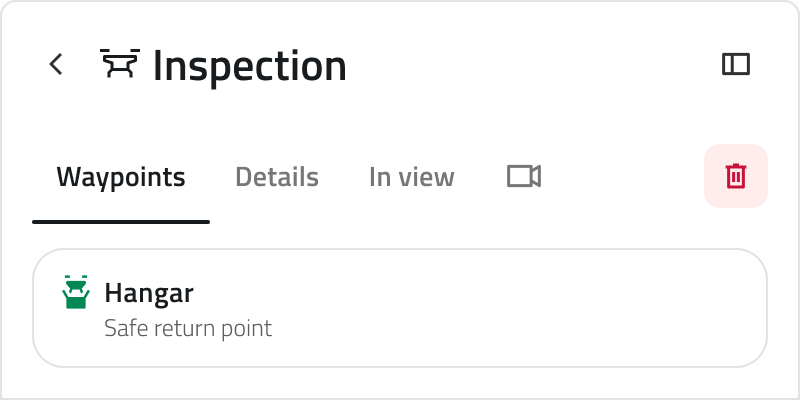
For a **drone**, the point of return is the **Hangar**: select that object class and place it on the map, in the same way a waypoint is added.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/nYhimage-3.png)
---
### Waypoints
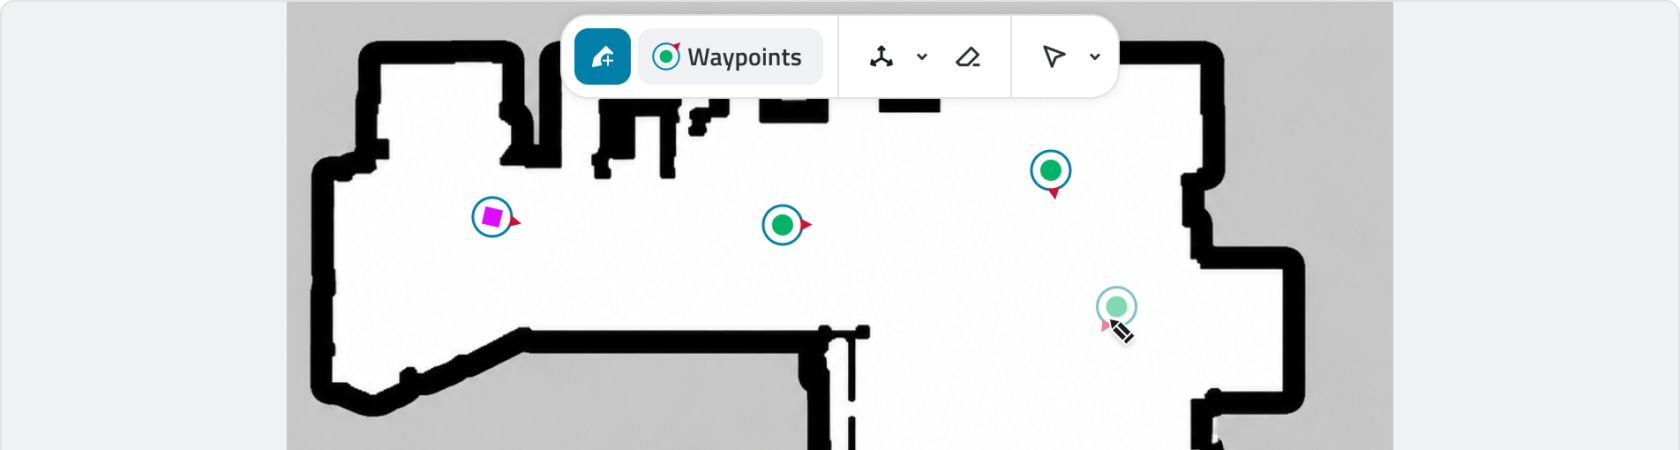
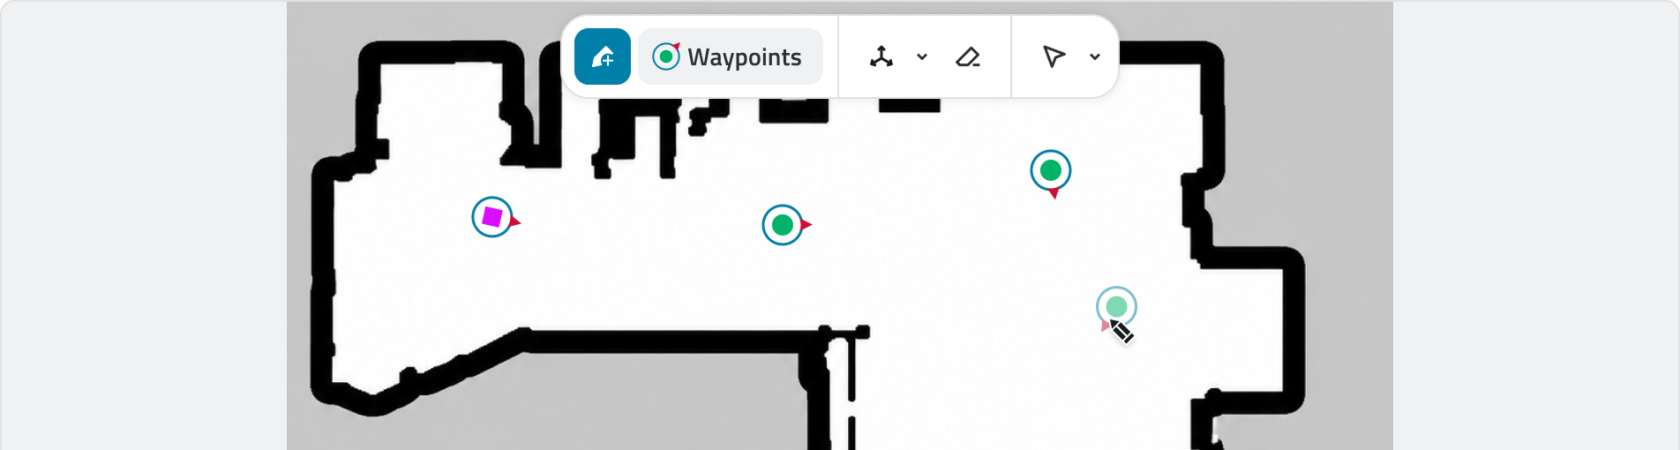
Waypoints are the points the unit travels through, in the order you place them. Draw the first one on the map and the route starts to take shape: each waypoint is numbered and appears both on the map and in the list on the left.
Each waypoint carries an orientation, which is the direction the unit faces when it arrives there.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/tMEimage-4.png)
#### Actions on a waypoint
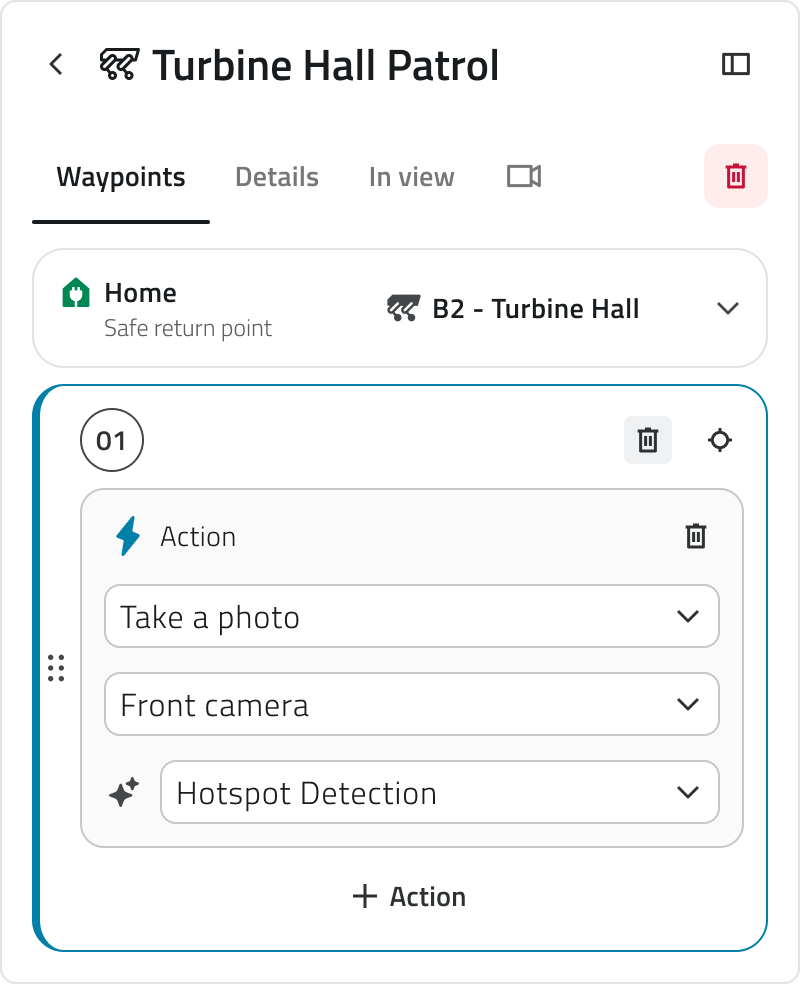
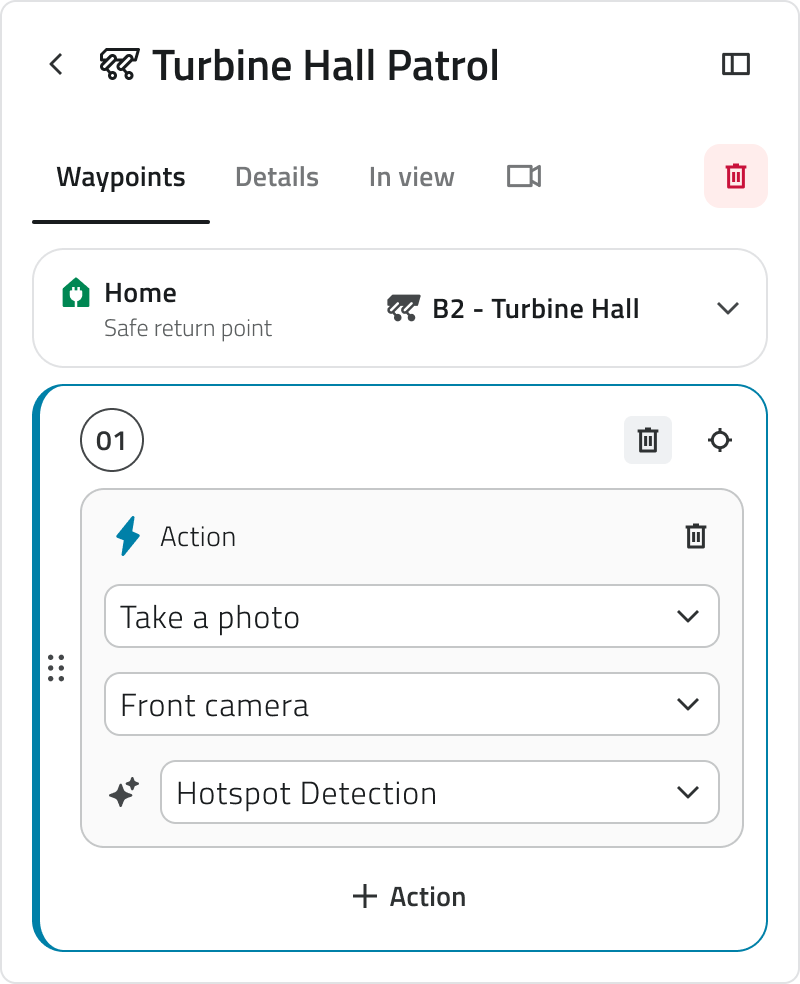
A waypoint can carry one or more actions, performed when the unit reaches it. Open the waypoint and add an action, then choose what it does, which add-on performs it and, where it applies, the algorithm that runs on it.
In the list, each waypoint shows how many actions it carries, so you can read the whole route at a glance.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/IK8image-5.png)
---
### Danger Zones and Geofencing
Besides the route, you can draw two kinds of area on the map to better define the mission:
| **Area** | **What it does** |
| **Danger Zones** | Marks an area the unit must keep out of. |
| **Geofencing** | Bounds the area the mission may take place in. |
Both are drawn as polygons and appear among the elements in the **In View** tab, where you can show or hide them as you work.
---
### Looking up an element on the map
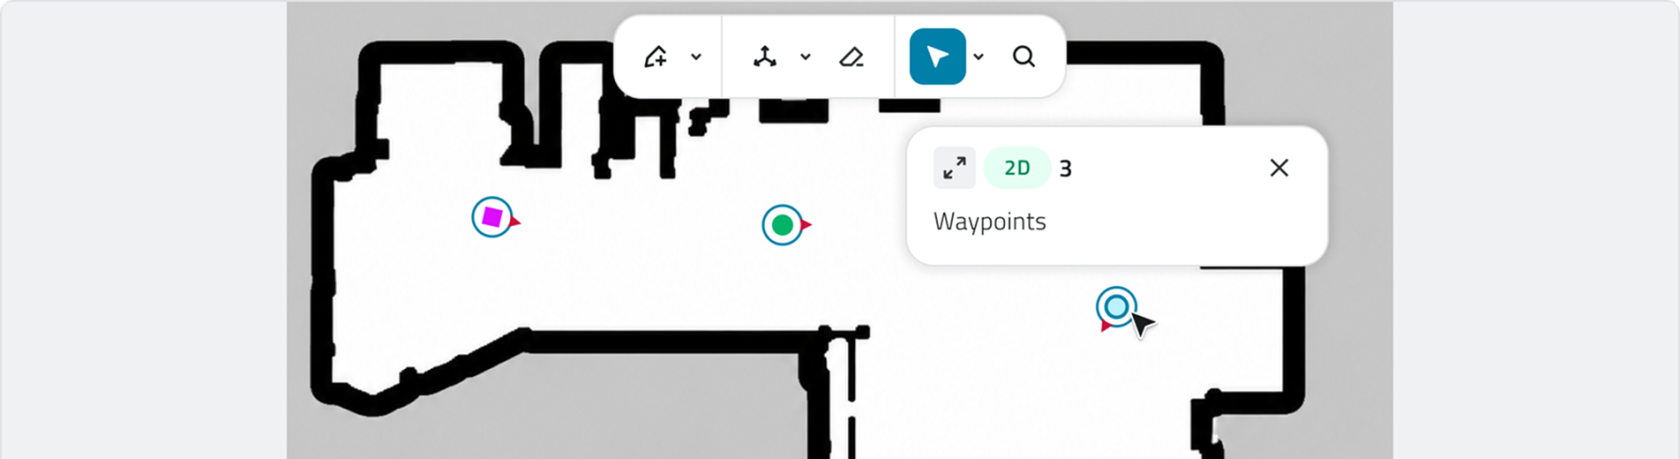
Selecting an element on the map opens a card with its essentials. Expanding the card shows its full attributes: for a waypoint, its identifier, the date of its last change, its orientation and the mission it belongs to.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/dtDimage-6.png)
---
### In view: what you see on the map
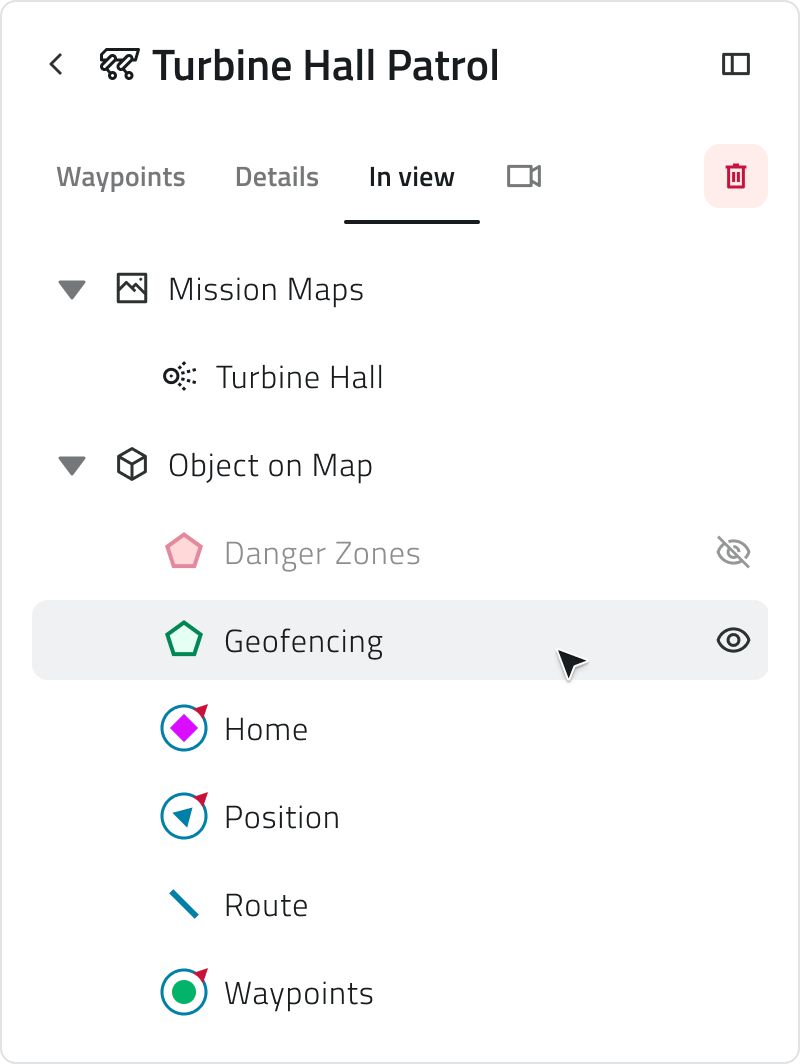
The **In view** tab governs what the map shows while you work. It holds two groups:
| **Group** | **What it contains** |
| **Mission Maps** | The map the mission runs on. In a multi-floor mission it lists the floors and the stairs between them. |
| **Object on Map** | The elements of the mission: **Danger Zones**, **Geofencing**, **Home**, **Position**, **Route** and **Waypoints**. |
Show or hide any entry with the eye next to it, and collapse a group with the arrow next to its name when you need more room for the rest.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/D2pimage-7.png)
In a mission with a drone the elements are the **Hangar** and the **Drone Waypoints**.
Expanding the map entry reveals **Map Opacity**: lower it to see what lies beneath the mission map, raise it to bring the map back to the front.
---
### Details of the mission
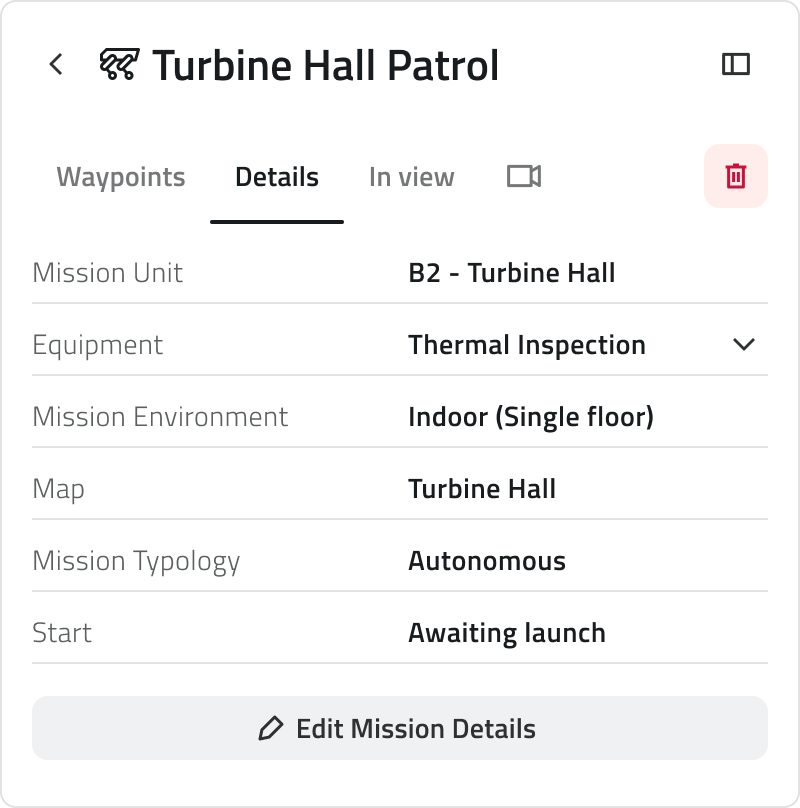
The **Details** tab collects all the mission information: the **Mission Unit**, the **Equipment** with the add-ons it includes and the algorithm assigned to each one, the **Mission Environment**, the **map**, the **mission typology** and the **start date**.
From this tab, the **Edit Mission Details** button takes you back to the configuration to change any of these choices.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/BpCimage-8.png)
---
### Saving and deleting
**Save as a Draft** keeps the mission with everything you have placed so far, and you find it again under **Draft** in the mission list. You can save whenever there is something new to keep.
Deleting the mission removes it from the project together with the route, the areas and the actions defined on it. A confirmation is asked before it happens.
Deletion is permanent and cannot be undone.
---
### Discovery missions
In a **Discovery** mission the robot dog explores the environment and builds the map on its own, so there's no route to draw.
Waypoints, geofences and danger zones can't be drawn in this type of mission.
---
### Links
- *[Run the pre-check and start a mission](https://wiki.eaglearca.com/books/mission-planner-sBN/page/run-the-pre-check-and-start-a-mission "Run the pre-check and start a mission")*: the checks before the start.
- *[Create a mission](https://wiki.eaglearca.com/books/mission-planner-sBN/page/create-a-mission "Create a mission")*: the configuration that comes before this screen.
- *[Find and manage your missions](https://wiki.eaglearca.com/books/mission-planner-sBN/page/find-and-manage-your-missions "Find and manage your missions")*: where drafts and planned missions live.
---
[  English ](https://wiki.eaglearca.com/link/174#bkmrk-english-italiano) [  Italiano ](https://wiki.eaglearca.com/link/174#bkmrk-english-italiano-1)
## Disegnare la missione sulla mappa
---
Nella schermata di pianificazione disegni la missione sulla mappa: la **Home Position** a cui l'unità rientra, i **Waypoints** che attraversa, le azioni che esegue lungo il percorso ed eventuali aree che ne limitano il movimento.
A questa schermata si arriva in due modi: al termine della configurazione di una nuova missione, oppure aprendo una missione **Bozza** dall'elenco delle missioni.
Il pannello a sinistra contiene quattro sezioni (**Waypoints**, **Dettagli**, **In vista** e **Streaming**), e la mappa occupa il resto della schermata. In basso, **Salva come bozza** conserva il lavoro e **Pre Check** porta ai controlli che precedono l'avvio.
---
### Il collegamento alla Mission Unit
All'apertura della missione la piattaforma si collega automaticamente alla **Mission Unit** assegnata: è l'unità a comunicare la propria posizione, e senza collegamento non puoi impostare la Home Position né eseguire il Pre Check.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/U42image-1.png)
Se il collegamento non riesce, verifica che l'unità sia accesa e a portata, poi seleziona **Riprova la connessione alla Mission Unit**.
---
### La Home Position
La **Home Position** è il punto da cui l'unità parte e a cui rientra a fine missione. Compare in cima alla sezione **Waypoints**, insieme all'unità assegnata alla missione.
#### Robot Dog
Per il **robot dog**, una volta collegata la Mission Unit, clicca **Cattura la Home Position**: la piattaforma registra il punto in cui l'unità si trova in quel momento. Se vuoi che il robot dog rientri alla stazione di ricarica a fine missione, posizionalo sulla stazione prima di catturare la posizione.
Per le **missioni esplorative** la partenza dalla stazione di ricarica è **fortemente consigliata**.
Una volta acquisita, puoi aggiornare la posizione della Home Position con con **Ricattura la Home Position**.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/8Dximage-2.png)
#### Drone
Per il **drone**, invece, il punto di rientro è l'**Hangar**: seleziona quella classe di oggetto e posizionala sulla mappa, con la stessa modalità utilizzata per aggiungere un waypoint.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/nYhimage-3.png)
---
### Waypoints
I waypoint sono i punti che l'unità attraversa, nell'ordine in cui li disegni. Il percorso prende forma dal primo waypoint che disegni sulla mappa: ciascuno viene numerato e compare sia sulla mappa sia nell'elenco a sinistra.
Ogni waypoint ha un orientamento, cioè la direzione verso cui l'unità è rivolta quando lo raggiunge.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/image.png)
#### Azioni su un waypoint
A un waypoint puoi assegnare una o più azioni, che l'unità esegue quando lo raggiunge. Apri il waypoint, aggiungi un'azione e indica in cosa consiste, quale add-on la esegue e, se serve, con quale algoritmo.
Nell'elenco ogni waypoint riporta il numero di azioni che contiene, così vedi subito com'è composto il percorso.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/IK8image-5.png)
---
### Danger Zones e Geofencing
Oltre al percorso, in mappa puoi disegnare due tipi di area che definiscono meglio la missione:
| **Area** | **Cosa fa** |
| **Zone di pericolo** | Segnala un'area in cui l'unità non deve entrare. |
| **Geofencing** | Delimita l'area entro cui la missione può svolgersi. |
Entrambe si disegnano come poligoni e compaiono tra gli elementi della sezione **In vista**, dove puoi mostrarle o nasconderle mentre lavori.
---
### Consultare un elemento in mappa
Selezionando un elemento sulla mappa si apre una card con le informazioni essenziali. Espandendola vedi tutti gli attributi: per un waypoint l'identificativo, la data dell'ultima modifica, l'orientamento e la missione a cui appartiene.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/dtDimage-6.png)
---
### In vista: cosa si vede in mappa
Dalla sezione **In vista** decidi cosa mostrare sulla mappa mentre lavori. Contiene due gruppi:
| **Gruppo** | **Cosa contiene** |
| **Mappe della missione** | La mappa su cui si svolge la missione. In una missione multipiano elenca i piani e le scale che li collegano. |
| **Oggetti sulla mappa** | Gli elementi della missione: **Zone di pericolo**, **Geofencing**, **Home**, **Posizione**, **Percorso** e **Waypoints**. |
L'occhio accanto a una voce la mostra o la nasconde, mentre la freccia accanto al nome di un gruppo lo comprime quando ti serve più spazio.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/D2pimage-7.png)
In una missione con drone gli elementi sono l'**Hangar** e i **Waypoints del drone**.
Espandendo la voce della mappa compare **Opacità della mappa**: abbassala per vedere cosa c'è sotto la mappa della missione, alzala per riportarla in primo piano.
---
### I dettagli della missione
La scheda **Dettagli** raccoglie tutte le informazioni della missione: la **Mission Unit**, **l'Equipment** con gli add-on che contiene e l'algoritmo assegnato a ciascuno, l'**Ambiente di missione**, la **mappa**, la **tipologia** e la **data di avvio**.
Da questa sezione, il pulsante **Modifica i dettagli della missione** riporta alla configurazione, dove puoi modificare ognuna di queste scelte.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/BpCimage-8.png)
---
### Salvare ed eliminare
**Salva come bozza** conserva la missione con tutto ciò che hai disegnato fino a quel momento, e la ritrovi sotto **Bozza** nell'elenco delle missioni. Puoi salvare ogni volta che c'è qualcosa di nuovo.
Eliminando la missione, dal progetto vengono rimossi anche il percorso, le aree e le azioni che hai definito. L'operazione richiede una conferma.
L'eliminazione è permanente e non può essere annullata.
---
### Missioni Esplorative
In una missione **Esplorativa** è il robot dog a esplorare l'ambiente e a costruirne la mappa, quindi non c'è un percorso da disegnare.
In questo tipo di missione non è possibile disegnare waypoint, geofence o danger zone.
---
### Collegamenti
- *[Eseguire il pre-check e avviare una missione](https://wiki.eaglearca.com/books/mission-planner-sBN/page/run-the-pre-check-and-start-a-mission "Run the pre-check and start a mission")*: i controlli che precedono l'avvio.
- *[Creare una missione](https://wiki.eaglearca.com/books/mission-planner-sBN/page/create-a-mission "Create a mission")*: la configurazione che precede questa schermata.
- *[Trovare e gestire le missioni](https://wiki.eaglearca.com/books/mission-planner-sBN/page/find-and-manage-your-missions "Find and manage your missions")*: dove trovi le bozze e le missioni pianificate.
---
***Last update:** 31 July 2026*
# Run the pre-check and start a mission
The Pre-check is the final step before a mission starts. It verifies that everything required for the mission is in place, tells you what needs to be fixed if something is missing, and allows you to start the mission or confirm its schedule.
[  English ](https://wiki.eaglearca.com/link/175#bkmrk-english-italiano) [  Italiano ](https://wiki.eaglearca.com/link/175#bkmrk-english-italiano-1)
---
The **Pre-check** is the final step before a mission starts. It verifies that everything required for the mission is in place, tells you what needs to be fixed if something is missing, and allows you to start the mission or confirm its schedule.
Open it by clicking **Pre Check**, at the bottom of the mission editor.
The pre-check runs with the **Mission Unit** connected, because part of what it verifies is reported by the unit itself.
---
### How to read the outcome
The outcome is divided into sections, each with the result of its own checks. Each section shows its outcome at a glance and opens to show the detail. Open the ones that need attention to read what is wrong and what to do about it.
| **Outcome** | **What it means** |
| **Passed** | The section has nothing to report. |
| **Warning** | The mission can run, but not as you planned it. A warning on **Waypoints**, for example, means some of them cannot be reached and will be skipped. Accept the warnings to go ahead, or go back and fix them. |
| **Error** | The mission cannot run as it is. Go back and resolve what the section reports. |
[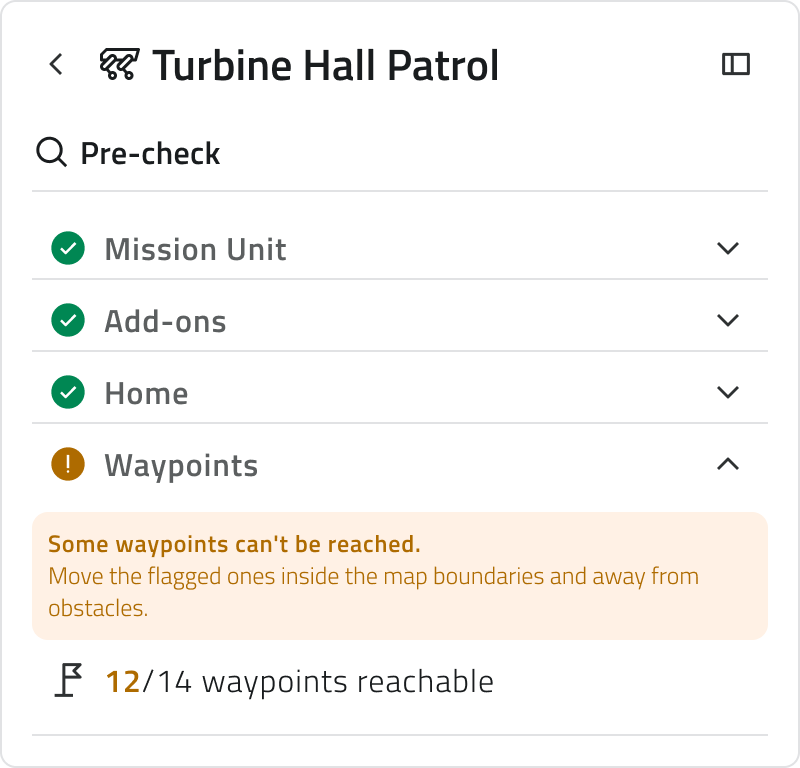](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/rfNimage-1.png)
### What the pre-check verifies
Which sections appear, and what you are shown before starting, depend on the Mission Unit assigned to the mission and on the type of mission. Go to the case that applies to you:
- [**Robot dog — Autonomous mission**](https://wiki.eaglearca.com/link/175#bkmrk-robot-dog-%E2%80%94-missione)
- [**Robot dog — Discovery mission**](https://wiki.eaglearca.com/link/175#bkmrk-robot-dog-%E2%80%94-missione-1)
- [**Drone**](https://wiki.eaglearca.com/link/175#bkmrk-drone)
---
#### Robot dog — Autonomous mission
Four sections are checked:
| **Sezione** | **Cosa verifica** |
| **Mission Unit** | That the unit assigned to the mission is connected and ready to carry it out. |
| **Add-ons** | That the add-ons the mission relies on are connected. The outcome tells you whether they all are, or only some. |
| **Home** | That the **Home Position** is set, so the unit knows where to return. |
| **Waypoints** | That the unit can reach the waypoints you placed. The outcome tells you how many are reachable out of the total. |
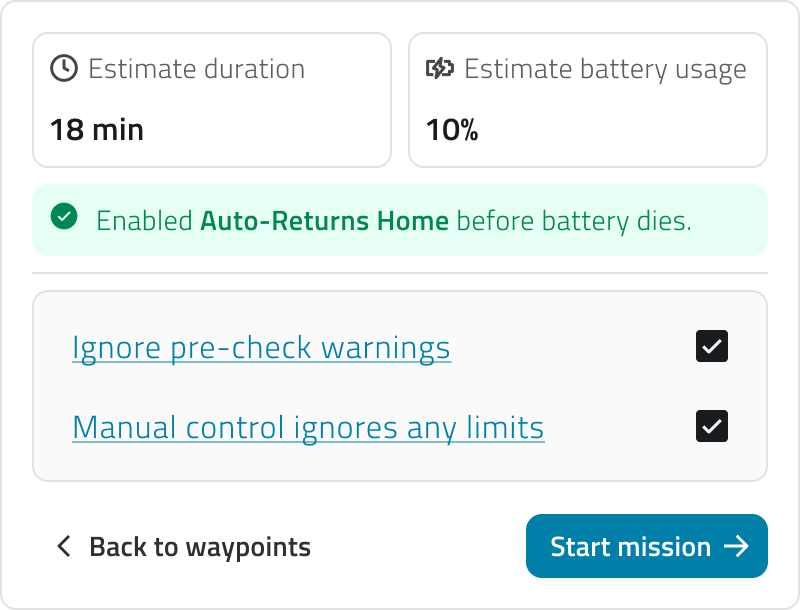
When the mission can go ahead, the pre-check also gives you an **Estimate duration** and an **Estimate battery usage** for the run you are about to start, so you can weigh them against the charge the unit has now.
It also confirms that **Auto-Returns Home** is enabled: the emergency safeguard that brings the unit back, on its own, if the charge is not enough to complete the mission.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/f08image-2.png)
---
#### Robot dog — Discovery mission
A Discovery mission has no route defined in advance, so only two sections are checked:
| **Sezione** | **Cosa verifica** |
| **Mission Unit** | That the unit assigned to the mission is connected and ready to carry it out. |
| **Add-ons** | That the add-ons the mission relies on are connected. The outcome tells you whether they all are, or only some. |
For a Discovery mission the pre-check shows no **duration** or **battery usage** estimate: without a defined route there is nothing to calculate them on. Check the charge of the unit before starting.
---
#### Drone
Three sections are checked:
| **Sezione** | **Cosa verifica** |
| **Mission Unit** | That the unit assigned to the mission is connected and ready to carry it out. |
| **Hangar** | That the position of the hangar has been captured and can be reached, so the drone has a point to return to. |
| **Waypoints** | That the unit can reach the waypoints you placed. The outcome tells you how many are reachable out of the total. |
For a mission with a drone the pre-check shows no **duration** or **battery usage** estimate.
---
### Start the mission
Depending on what the pre-check reports and on how the mission is set up, one or more **statements to acknowledge** appear above **Start mission**. The button remains disabled until you have read and checked each one.
What the last step does depends on the **Launch Mode** chosen during the configuration:
| **Modalità di avvio** | **Cosa succede** |
| **Manuale** | The mission starts straight away and you follow it on the live view. |
| **Pianificata** | The schedule is confirmed and the mission moves to **Planned**, ready to run at the date and time you set. |
To change something before starting, the **Back to waypoints** button returns to the mission editor with everything as you left it.
Leaving a mission set to **Planned** without confirming its schedule keeps it as a **Draft**: it will not run until you come back and confirm it.
---
### Links
- *[Robot Dog – Tracking a live mission](https://wiki.eaglearca.com/books/mission-planner-sBN/page/robot-dog-tracking-a-live-mission "Robot Dog – Tracking a live mission")*: what you see once the mission is running.
- *[Draw the mission on the map](https://wiki.eaglearca.com/books/mission-planner-sBN/page/draw-the-mission-on-the-map "Draw the mission on the map")*: where you go back to fix what the pre-check reports.
- *[Schedule a mission](https://wiki.eaglearca.com/books/mission-planner-sBN/page/schedule-a-mission "Schedule a mission")*: setting the date and time of a planned mission.
---
[  English ](https://wiki.eaglearca.com/link/175#bkmrk-english-italiano) [  Italiano ](https://wiki.eaglearca.com/link/175#bkmrk-english-italiano-1)
## Eseguire il pre-check e avviare una missione
---
Il **Pre-check** è l'ultimo passaggio prima che una missione parta. Verifica che sia presente tutto ciò che la missione richiede, indica cosa correggere se qualcosa manca, e consente di avviare la missione o di confermarne la pianificazione.
Si apre cliccando **Pre Check**, in fondo alla schermata di pianificazione.
Il pre-check richiede la **Mission Unit** collegata, perché parte dei controlli si basa sui dati che l'unità comunica.
---
### Come leggere l'esito
L'esito è diviso in sezioni, ciascuna con il risultato dei propri controlli. Ogni sezione mostra il proprio esito e può essere aperta per vederne il dettaglio. Apri quelle che richiedono attenzione per capire cosa non va e come intervenire.
| **Esito** | **Cosa significa** |
| **Superato** | La sezione non ha nulla da segnalare. |
| **Avviso** | La missione può partire, ma non come l'avevi pianificata. Un warning sui **Waypoints**, per esempio, indica che alcuni non sono raggiungibili e verranno saltati. Accetta i warning per procedere, oppure torna indietro e correggili. |
| **Errore** | La missione non può partire in queste condizioni: torna indietro e risolvi quanto segnalato dalla sezione. |
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/rfNimage-1.png)
### Cosa verifica il pre-check
Quali sezioni compaiono, e cosa ti viene mostrato prima dell'avvio, dipendono dalla Mission Unit assegnata alla missione e dal tipo di missione.
- [**Robot dog — Missione autonoma**](https://wiki.eaglearca.com/link/175#bkmrk-robot-dog-%E2%80%94-missione)
- [**Robot dog — Missione Discovery**](https://wiki.eaglearca.com/link/175#bkmrk-robot-dog-%E2%80%94-missione-1)
- [**Drone**](https://wiki.eaglearca.com/link/175#bkmrk-drone)
---
#### Robot dog — Missione autonoma
Vengono verificate quattro sezioni:
| **Sezione** | **Cosa verifica** |
| **Mission Unit** | Che l'unità assegnata alla missione sia collegata e pronta a eseguirla. |
| **Add-ons** | Che gli add-on necessari alla missione siano collegati. L'esito indica se lo sono tutti oppure solo alcuni. |
| **Home** | Che la **Home Position** sia impostata, così l'unità sa dove rientrare. |
| **Waypoints** | Che l'unità possa raggiungere i waypoint che hai disegnato. L'esito indica quanti sono raggiungibili sul totale. |
Quando è possibile procedere, il pre-check fornisce anche una **Durata stimata** e un **Consumo stimato della batteria** per la missione che si sta per avviare, così da poterle confrontare con il livello di carica attuale dell'unità.
Conferma inoltre che **Auto-Returns Home** è abilitato: la funzione di sicurezza di emergenza che riporta automaticamente l'unità al punto di partenza se la carica non è sufficiente per completare la missione.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/f08image-2.png)
---
#### Robot dog — Missione Discovery
Una missione Discovery non prevede un percorso definito in anticipo, quindi vengono verificate solo due sezioni:
| **Sezione** | **Cosa verifica** |
| **Mission Unit** | Che l'unità assegnata alla missione sia collegata e pronta a eseguirla. |
| **Add-ons** | Che gli add-on necessari alla missione siano collegati. L'esito indica se lo sono tutti oppure solo alcuni. |
Per una missione Discovery il pre-check non mostra la **stima di durata** né quella di **consumo della batteria**: senza un percorso definito non ci sono elementi su cui calcolarle.
---
#### Drone
Vengono verificate tre sezioni:
| **Sezione** | **Cosa verifica** |
| **Mission Unit** | Che l'unità assegnata alla missione sia collegata e pronta a eseguirla. |
| **Hangar** | Che la posizione dell'hangar sia stata acquisita e sia raggiungibile, così il drone ha un punto in cui rientrare. |
| **Waypoints** | Che l'unità sia in grado di raggiungere i waypoint che hai posizionato. Il risultato indica quanti di essi sono raggiungibili rispetto al totale. |
Per una missione con drone il pre-check non mostra la **stima di durata** né quella di **consumo della batteria**.
---
### Avviare la missione
In base all'esito del pre-check e alla configurazione della missione, sopra il pulsante **Avvia missione** vengono visualizzate uno o più **disclaimer da accettare**: il pulsante rimane disabilitato finché non sono stati letti e accettati tutti.
L'ultimo passaggio dipende dalla **Modalità di avvio** scelta durante la configurazione:
| **Modalità di avvio** | **Cosa succede** |
| **Manuale** | La missione parte subito e la segui dalla vista in diretta. |
| **Pianificata** | La pianificazione viene confermata e la missione passa tra le **Pianificate**, pronta a partire alla data e all'ora impostate. |
Se vuoi cambiare qualcosa prima di avviare, il pulsante **Torna ai waypoint** riporta alla schermata di pianificazione, dove ritrovi tutto come l'avevi lasciato.
Se esci da una missione impostata su **Pianificata** senza confermare la pianificazione, questa resta una **Bozza** e non verrà eseguita finché non la confermi.
---
### Collegamenti
- *[Robot Dog – Seguire una missione in diretta](https://wiki.eaglearca.com/books/mission-planner-sBN/page/robot-dog-tracking-a-live-mission "Robot Dog – Tracking a live mission")*: cosa vedi una volta che la missione è partita.
- *[Disegnare la missione in mappa](https://wiki.eaglearca.com/books/mission-planner-sBN/page/draw-the-mission-on-the-map "Draw the mission on the map")*: dove tornare per correggere quanto il pre-check segnala.
- *[Pianificare una missione](https://wiki.eaglearca.com/books/mission-planner-sBN/page/schedule-a-mission "Schedule a mission")*: impostare data e ora di una missione pianificata.
---
***Last update:** 31 July 2026*
# Schedule a mission
A mission set to run Planned starts on its own at the date and time set for it, without anyone launching it. The Scheduling options, which appear as soon as you select Planned in the Launch Mode step of the configuration, are where you decide when that happens, whether it happens more than once, and where you check that it does not overlap the missions already booked for the same Mission Unit.
[  English ](https://wiki.eaglearca.com/link/176#bkmrk-english-italiano) [  Italiano ](https://wiki.eaglearca.com/link/176#bkmrk-english-italiano-1)
---
A mission set to run **Planned** starts on its own at the date and time set for it, without anyone launching it. The **Scheduling** options, which appear as soon as you select **Planned** in the **Launch Mode** step of the configuration, are where you decide when that happens, whether it happens more than once, and where you check that it does not overlap the missions already booked for the same **Mission Unit**.
You reach them both while you configure a new mission and when you change one.
---
### When the mission starts
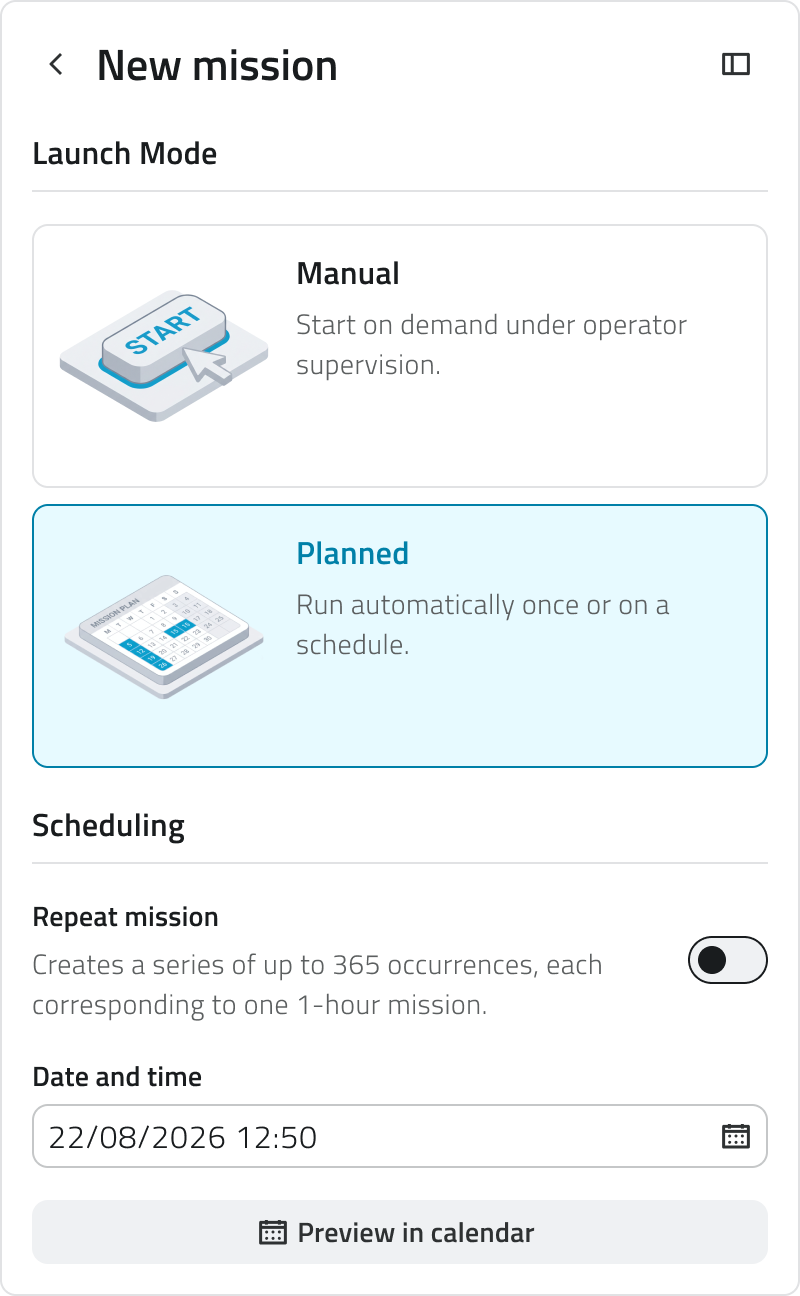
Fill in the **Date and time** field to set when the mission starts.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/RE6image-1.png)
Schedule the mission at least five minutes ahead: the platform needs that margin to prepare the run and reach the Mission Unit.
---
### Repeating the mission
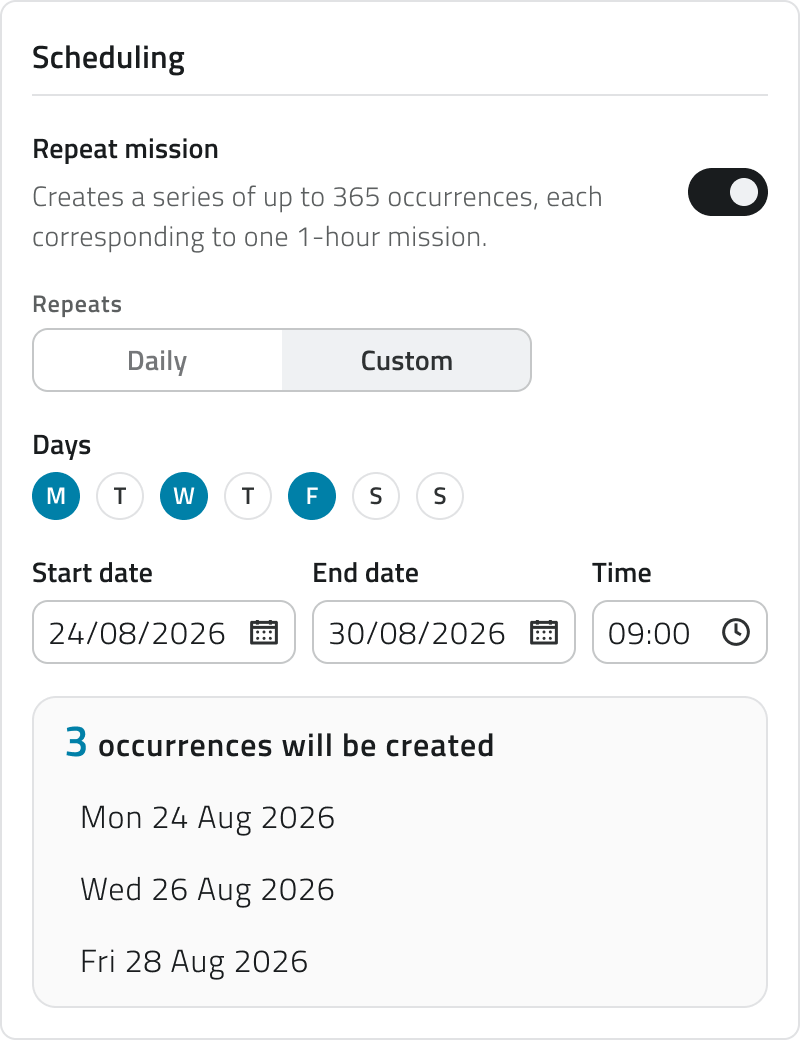
Turn on **Repeat mission** to run the same mission again over a period of time instead of once. What you build is a **series**, and every run inside it is an **occurrence**.
Choose the rhythm of the series:
| **Repeats** | **What you get** |
| **Daily** | One occurrence every day of the period. |
| **Custom** | One occurrence only on the days of the week you pick. |
Fill in **Start date** and **End date** to define the period the series covers, and **Time** to set when each occurrence starts.
As you change these choices, the platform tells you how many occurrences the series will create, so you know how many there will be before you confirm.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/bTfimage-2.png)
A series cannot stretch beyond a year: **Start date** and **End date** must fall within twelve months of each other. Plan a longer campaign as more than one series.
---
### Checking the plan before confirming
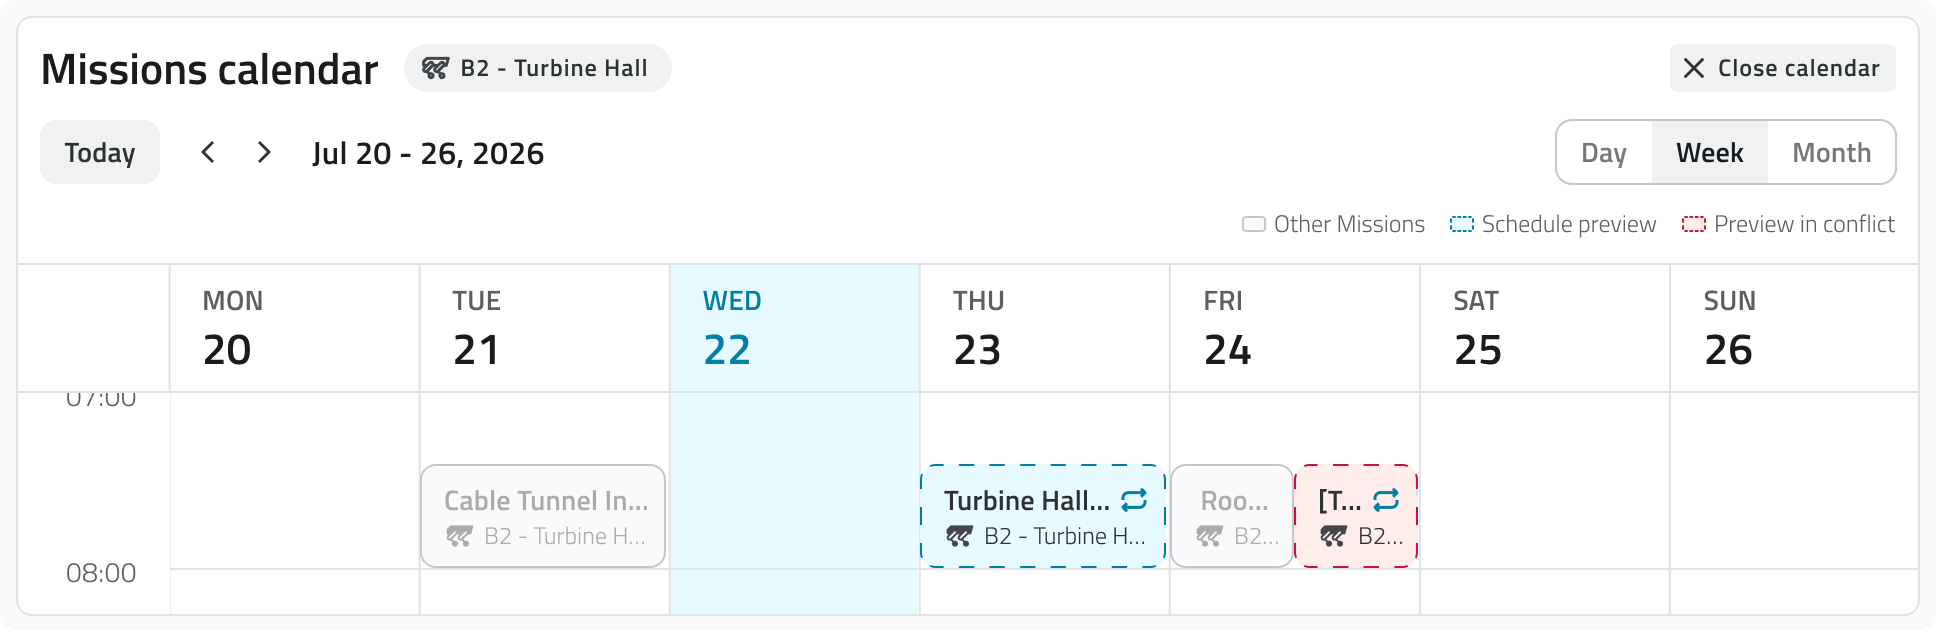
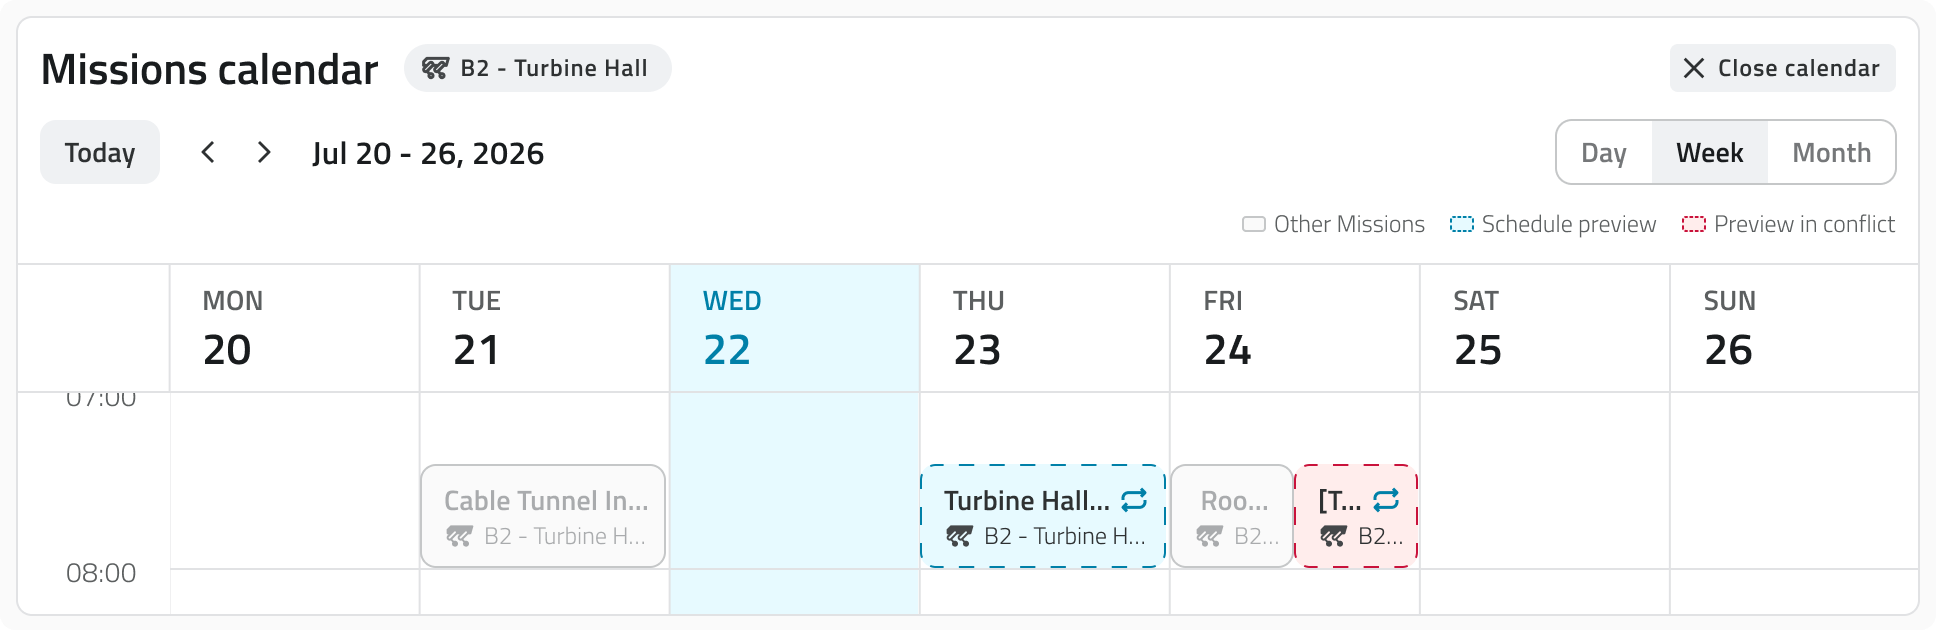
The **Preview in calendar** button opens the **Missions calendar** beside the scheduling options. It puts the mission you are planning next to what is already booked for the same **Mission Unit**, so you see the plan in context instead of as a list of dates. **Close calendar** closes it again.
The calendar tells three things apart: **Other Missions**, already booked; **Schedule preview**, the occurrences you are about to create; and **Preview in conflict**, the ones that clash with something already there. Switch between **Day**, **Week** and **Month** to see how the series falls over the period, and use **Today** to come back to the current date.
---
### When a mission clashes with another
A conflict means the same **Mission Unit** is already committed to another mission at that moment, and one unit can only carry out one mission at a time. The preview tells you how many occurrences are in conflict and on which dates.
You can confirm the schedule anyway: the mission is created with its conflicting occurrences flagged. A mission cannot be moved once it is scheduled, though, so clearing a conflict means deleting one of the two.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/BLqimage-3.png)
An occurrence left in conflict is not carried out. The mission stays in the calendar, marked as conflicting, until you delete one of the two missions.
---
### Confirming the schedule
The date you choose is not booked yet. The mission is saved as a **Draft** and takes its place in the calendar only when you confirm it in the **Pre Check**. An **Autonomous** mission has to be drawn on the map first, while a **Discovery** mission has no path to draw and goes straight to the Pre Check.
Once confirmed, the mission moves in among the **Planned** ones, where you find the date of its next run and how many runs it still has ahead.
---
### Following a series once it is planned
In the mission list, a recurring mission carries **Next** with the date and time of the occurrence that comes first, and a badge with how many occurrences it still holds.
[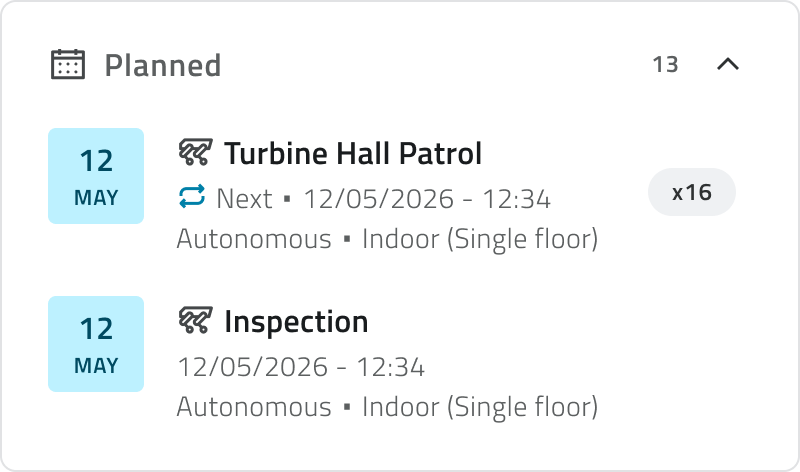](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/rL9image-4.png)
Click the mission and choose what to open: **View next occurrence** or **View entire series**.
The series shows the mission as it was planned, with a **Schedule** section that gathers the period the series covers, the time of each run and the days of the week it falls on, followed by the list of the occurrences still to come. That list gets shorter as the series is carried out.
In the **Details** tab, next to the button that deletes the mission, a second button opens the **Missions calendar** already filtered on the mission's **Mission Unit**, so you see the series alongside everything that unit is already booked for.
The occurrence, which you also reach by selecting one of the dates in that list, shows the same mission with the schedule reduced to the day and the time of that single run.
---
### Links
- *[Run the pre-check and start a mission](https://wiki.eaglearca.com/books/mission-planner-sBN/page/run-the-pre-check-and-start-a-mission "Run the pre-check and start a mission")*: where the schedule is confirmed.
- *[Missions calendar](https://wiki.eaglearca.com/books/mission-planner-sBN/page/missions-calendar "Missions calendar")*: seeing and managing what is planned, conflicts included.
---
[  English ](https://wiki.eaglearca.com/link/176#bkmrk-english-italiano) [  Italiano ](https://wiki.eaglearca.com/link/176#bkmrk-english-italiano-1)
## Pianificare una missione
---
Una missione impostata su **Pianificata** parte da sola alla data e all'ora prestabilite, senza che nessuno la avvii. Le opzioni di **Pianificazione** compaiono appena selezioni **Pianificata** nello step **Modalità di avvio** della configurazione: qui stabilisci quando la missione parte, se deve ripetersi e controlli che non si sovrapponga alle missioni già prenotate per la stessa **Mission Unit**.
Le trovi sia quando configuri una nuova missione, sia quando ne modifichi una.
---
### Quando parte la missione
Il campo **Data e ora** va compilato per stabilire quando partirà la missione.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/RE6image-1.png)
Pianifica la missione con almeno cinque minuti di anticipo: alla piattaforma serve quel margine per preparare l'esecuzione e raggiungere la Mission Unit.
---
### Ripetere la missione
Attiva **Ripeti missione** se la stessa missione deve ripetersi in un certo periodo invece di essere eseguita una volta sola. L'insieme delle ripetizioni è una **serie**, e ogni esecuzione al suo interno è un'**occorrenza**.
Scegli il ritmo della serie:
| **Ripetizione** | **Cosa ottieni** |
| **Giornaliera** | Un'occorrenza ogni giorno del periodo. |
| **Personalizzata** | Un'occorrenza solo nei giorni della settimana che scegli. |
**Data di inizio** e **Data di fine** vanno compilate per definire il periodo coperto dalla serie, **Ora** per stabilire l'orario di avvio di ogni occorrenza.
A ogni modifica, la piattaforma aggiorna il numero di occorrenze che verranno create dalla serie: sai quante saranno prima di confermare.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/bTfimage-2.png)
Una serie non può estendersi oltre un anno: **Data di inizio** e **Data di fine** devono restare entro dodici mesi l'una dall'altra. Per un periodo più lungo, crea più serie.
---
### Verificare il piano prima di confermare
Il pulsante **Anteprima nel calendario** apre il **Calendario delle missioni** accanto alle opzioni di pianificazione. La missione che stai pianificando compare insieme a quelle già prenotate per la stessa **Mission Unit**, così la vedi nel suo contesto e non come un semplice elenco di date. Per richiuderlo, usa **Chiudi calendario**.
Il calendario distingue tre cose: le missioni già prenotate (**Altre missioni**), le occorrenze che stai per creare (**Anteprima della pianificazione**) e quelle che si sovrappongono a una missione esistente (**Anteprima in conflitto**). Con **Giorno**, **Settimana** e **Mese** cambi vista per capire come cade la serie nel periodo, mentre **Oggi** riporta alla data corrente.
---
### Quando una missione si sovrappone a un'altra
Si crea un conflitto quando la **Mission Unit** è già impegnata in un'altra missione allo stesso orario, perché un'unità può eseguire una sola missione per volta. L'anteprima ti dice quante occorrenze sono in conflitto e in quali date.
Puoi confermare la pianificazione anche così: la missione viene creata con le occorrenze in conflitto evidenziate. Una volta pianificate, però, le missioni non si possono spostare: per risolvere un conflitto devi eliminare una delle due.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/BLqimage-3.png)
Un'occorrenza lasciata in conflitto non viene eseguita. La missione resta nel calendario, segnalata come in conflitto, finché non elimini una delle due missioni.
---
### Confermare la pianificazione
Scegliere la data non basta a prenotarla: la missione viene salvata come **Bozza** e prende posto nel calendario solo quando la confermi nel **Pre Check**. In una missione **Autonoma** devi prima disegnarla sulla mappa, mentre in una **Esplorativa** non c'è un percorso da disegnare e si passa direttamente al Pre Check.
Da quel momento la missione compare tra le **Pianificate**, con la data della prossima esecuzione e il numero di esecuzioni ancora da svolgere.
---
### Seguire una serie dopo la pianificazione
Nell'elenco delle missioni, una missione ricorrente mostra la voce **Prossima**, con la data e l'ora dell'occorrenza più imminente, e un badge che indica quante occorrenze restano.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/rL9image-4.png)
La serie mostra la missione come l'hai pianificata: sotto **Pianificazione** trovi il periodo coperto, l'orario di ogni esecuzione e i giorni della settimana in cui è prevista, seguiti dall'elenco delle occorrenze ancora da svolgere, che si accorcia man mano che la serie procede.
Nella scheda **Dettagli**, accanto al button che elimina la missione, un secondo button apre il **Calendario delle missioni** già filtrato sulla **Mission Unit** della missione, così vedi la serie insieme a tutto ciò per cui quell'unità è già impegnata.
Selezionando una data dell'elenco apri la singola occorrenza: è la stessa missione, ma con la pianificazione limitata al giorno e all'ora di quell'esecuzione.
---
### Collegamenti
- *[Eseguire il pre-check e avviare una missione](https://wiki.eaglearca.com/books/mission-planner-sBN/page/run-the-pre-check-and-start-a-mission "Run the pre-check and start a mission")*: dove la pianificazione viene confermata.
- *[Calendario delle missioni](https://wiki.eaglearca.com/books/mission-planner-sBN/page/missions-calendar "Missions calendar")*: vedere e gestire ciò che è pianificato, conflitti compresi.
---
***Last update:** 14 September 2026*
# Edit a mission's configuration
Everything you decided while configuring a mission can be decided again: the Mission Unit that carries it out, the Equipment it uses, the name and the typology, the environment with its map, and the way the mission starts.
[  English ](https://wiki.eaglearca.com/link/177#bkmrk-english-italiano) [  Italiano ](https://wiki.eaglearca.com/link/177#bkmrk-english-italiano-1)
---
Everything you decided while configuring a mission can be decided again: the **Mission Unit** that carries it out, the **Equipment** it uses, the name and the typology, the environment with its map, and the way the mission starts.
The steps depend on one another, so a change can take away a choice you had already made in another step. The table further down says what each one affects.
---
### Reopening the configuration
Open the **Details** tab of the planning screen and select **Edit Mission Details**. The configuration opens again at the first step.
Reach the step you want with **Next** and **Back**, or select its number in the row at the bottom of the panel.
[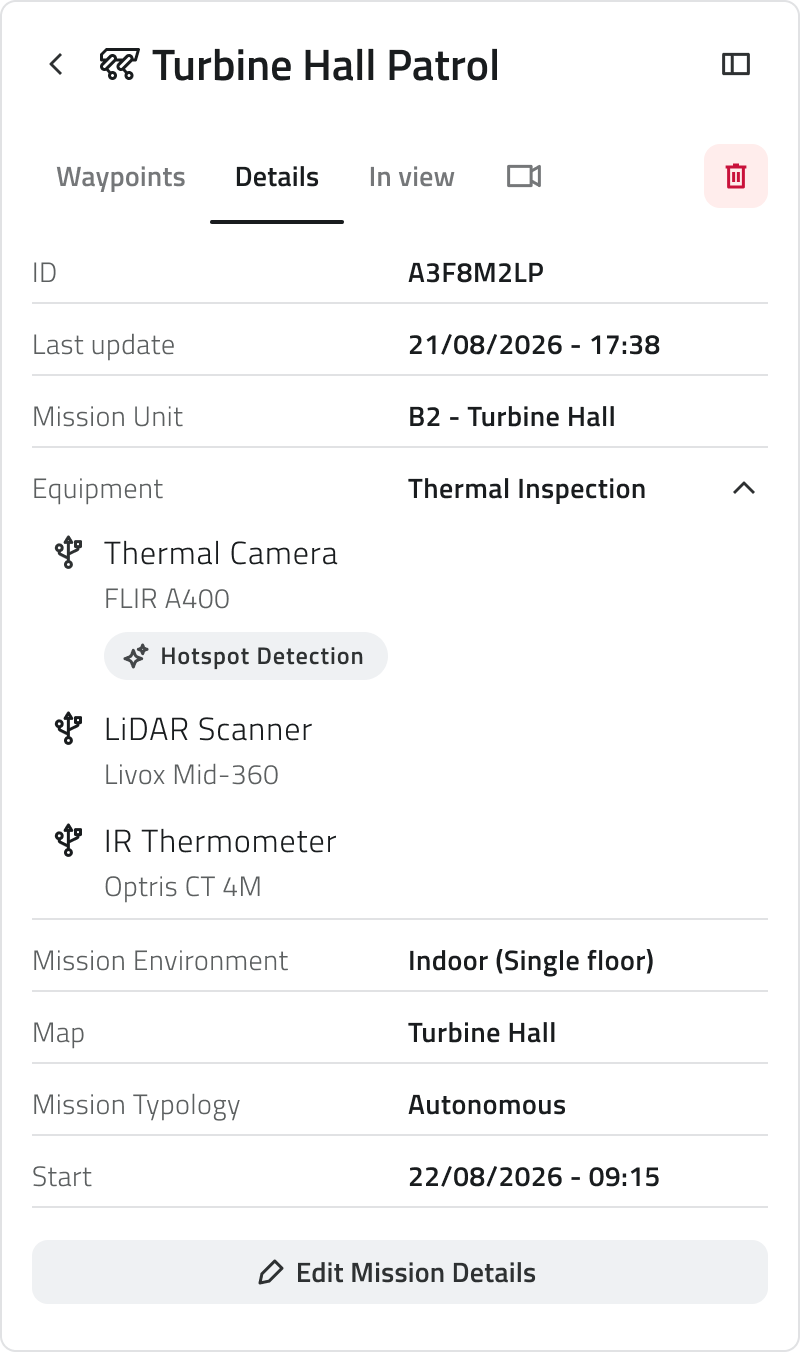](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/bmQimage-1.png)
After a change, the steps that come after it have to be confirmed one by one with **Next**, even when the change leaves them exactly as they were.
---
### What each change affects
| **What you change** | **What it affects** |
| The **Mission Unit** | If the new unit does not support the **Equipment** you had chosen, you will need to select another one among those it supports.
If you select a unit of a different type, the configuration adapts to what that type can do. |
| The **Equipment** | The waypoint actions performed by an add-on the new Equipment does not carry. |
| The typology | Switching to **Discovery** keeps the map and the elements you drew, but they aren't executed: you can delete them. Any AI algorithms you selected are removed, since Discovery missions don't support them.
Switching to **Autonomous** means choosing a map and drawing the mission. |
| The **Mission Environment** | Home Position, waypoints, Danger Zones and Geofencing stay at the coordinates they had, and need checking on the new map. |
| The map | Nothing is removed, but the positions of what you drew need checking on the new map. |
---
### Waypoint actions to fill in again
Every action assigned to a waypoint is performed by one of the add-ons of the Equipment. **If you changed the Equipment** and the new one doesn't carry the add-on an action needs, **that action is cleared**: the waypoint stays in the list, either partly filled in or with no action at all. Open it and assign an action the new Equipment can perform, or delete the empty one. The other waypoints keep the actions they had.
---
### Links
- *[Draw the mission on the map](https://wiki.eaglearca.com/books/mission-planner-sBN/page/draw-the-mission-on-the-map "Draw the mission on the map")*: where you reopen the configuration from, and where you come back to.
- *[Create a mission](https://wiki.eaglearca.com/books/mission-planner-sBN/page/create-a-mission "Create a mission")*: each step and each choice described in full.
- *[Run the pre-check and start a mission](https://wiki.eaglearca.com/books/mission-planner-sBN/page/run-the-pre-check-and-start-a-mission "Run the pre-check and start a mission")*: the checks that follow what you have changed.
---
[  English ](https://wiki.eaglearca.com/link/177#bkmrk-english-italiano) [  Italiano ](https://wiki.eaglearca.com/link/177#bkmrk-english-italiano-1)
## Modifica la configurazione di una missione
---
Ogni scelta fatta in fase di configurazione può essere rivista: la **Mission Unit** che esegue la missione, l'**Equipment** che utilizza, il nome e la tipologia, l'ambiente con la sua mappa e il modo in cui la missione parte.
Gli step sono legati tra loro: una modifica può far decadere una scelta già fatta in un altro step. Nella tabella più sotto trovi su cosa incide ciascuna.
---
### Riaprire la configurazione
Apri la sezione **Dettagli** della schermata di pianificazione e seleziona **Modifica i dettagli della missione**: la configurazione si riapre dal primo step.
Per spostarti tra gli step usa **Avanti** e **Indietro**, oppure vai diretto a quello che ti serve selezionandone il numero nella riga in basso nel pannello.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/bmQimage-1.png)
Dopo una modifica, gli step successivi vanno riconfermati uno per uno con **Avanti**, anche quando restano esattamente come erano.
---
### Su cosa incide ogni modifica
| **Cosa modifichi** | **Su cosa incide** |
| La **Mission Unit** | Se la nuova unità non supporta l'**Equipment** scelto in precedenza, dovrai selezionarne un altro tra quelli supportati.
Se scegli un'unità di tipo diverso, la configurazione si adatta alle possibilità di quel tipo. |
| L'**Equipment** | Le azioni dei waypoint che richiedono un add-on non presente nel nuovo Equipment. |
| La tipologia | Passando a **Esplorativa** la mappa e gli elementi disegnati restano, ma non vengono eseguiti: puoi eliminarli. Gli algoritmi AI selezionati vengono rimossi, perché le missioni esplorative non li supportano.
Passando ad **Autonoma** dovrai scegliere una mappa e disegnare la missione. |
| L'**Ambiente della missione** | Home Position, waypoint, Zone di pericolo e Geofencing restano alle coordinate che avevano, e vanno verificati sulla nuova mappa. |
| La mappa | Nulla viene rimosso, ma le posizioni degli elementi vanno verificate sulla nuova mappa. |
---
### Azioni dei waypoint da ricompilare
Ogni azione assegnata a un waypoint viene eseguita da uno degli add-on dell'Equipment. **Se hai modificato l'Equipment** e quello nuovo non dispone dell'add-on richiesto da un'azione, **l'azione si svuota**: il waypoint resta in elenco, parzialmente compilato oppure senza azione. Aprilo e assegna un'azione che il nuovo Equipment è in grado di eseguire, oppure elimina quella rimasta vuota. Gli altri waypoint mantengono le azioni che avevano.
---
### Collegamenti
- *[Disegnare la missione in mappa](https://wiki.eaglearca.com/books/mission-planner-sBN/page/draw-the-mission-on-the-map "Draw the mission on the map")*: da dove riapri la configurazione, e dove torni.
- *[Creare una missione](https://wiki.eaglearca.com/books/mission-planner-sBN/page/create-a-mission "Create a mission")*: ogni step e ogni scelta descritti per esteso.
- *[Eseguire il pre-check e avviare una missione](https://wiki.eaglearca.com/books/mission-planner-sBN/page/run-the-pre-check-and-start-a-mission "Run the pre-check and start a mission")*: i controlli che seguono ciò che hai modificato.
---
***Last update:** 6 August 2026*
# Missions calendar
Missions calendar puts what is planned on a timeline, so you can see when a Mission Unit is busy, which missions are about to run and which ones are waiting for a conflict to be resolved.
[  English ](https://wiki.eaglearca.com/link/178#bkmrk-english-italiano) [  Italiano ](https://wiki.eaglearca.com/link/178#bkmrk-english-italiano-1)
---
**Missions calendar** puts what is planned on a timeline, so you can see when a **Mission Unit** is busy, which missions are about to run and which ones are waiting for a conflict to be resolved.
The same calendar appears in two places, and what changes is how much of the organisation it covers:
| **Where you open it** | **What it covers** |
| Inside a project, from the calendar icon in the side bar | The missions of that project. This is where you delete a mission or one of its occurrences. |
| From the app's home screen, using the calendar icon in the sidebar | The missions of the organisation and of the selected group, across all of its projects. |
---
### The five views
Each view answers a different question, and they all show the same missions:
| **View** | **What it shows** |
| **Series** | The recurring missions listed one by one, instead of a grid of days. |
| **Day** | One day on an hourly grid, with each mission at its own time and a line marking the current moment. |
| **Week** | Seven days side by side, to see how a week is loaded. |
| **Month** | The whole month, with the missions of each day. When a day is too full to show them all, **+N missions** tells you how many others there are. |
| **Agenda** | The next 14 days as a list grouped by day, without empty days. |
The arrows move to the period before or after the one you are looking at, and **Today** brings you back to the current one.
[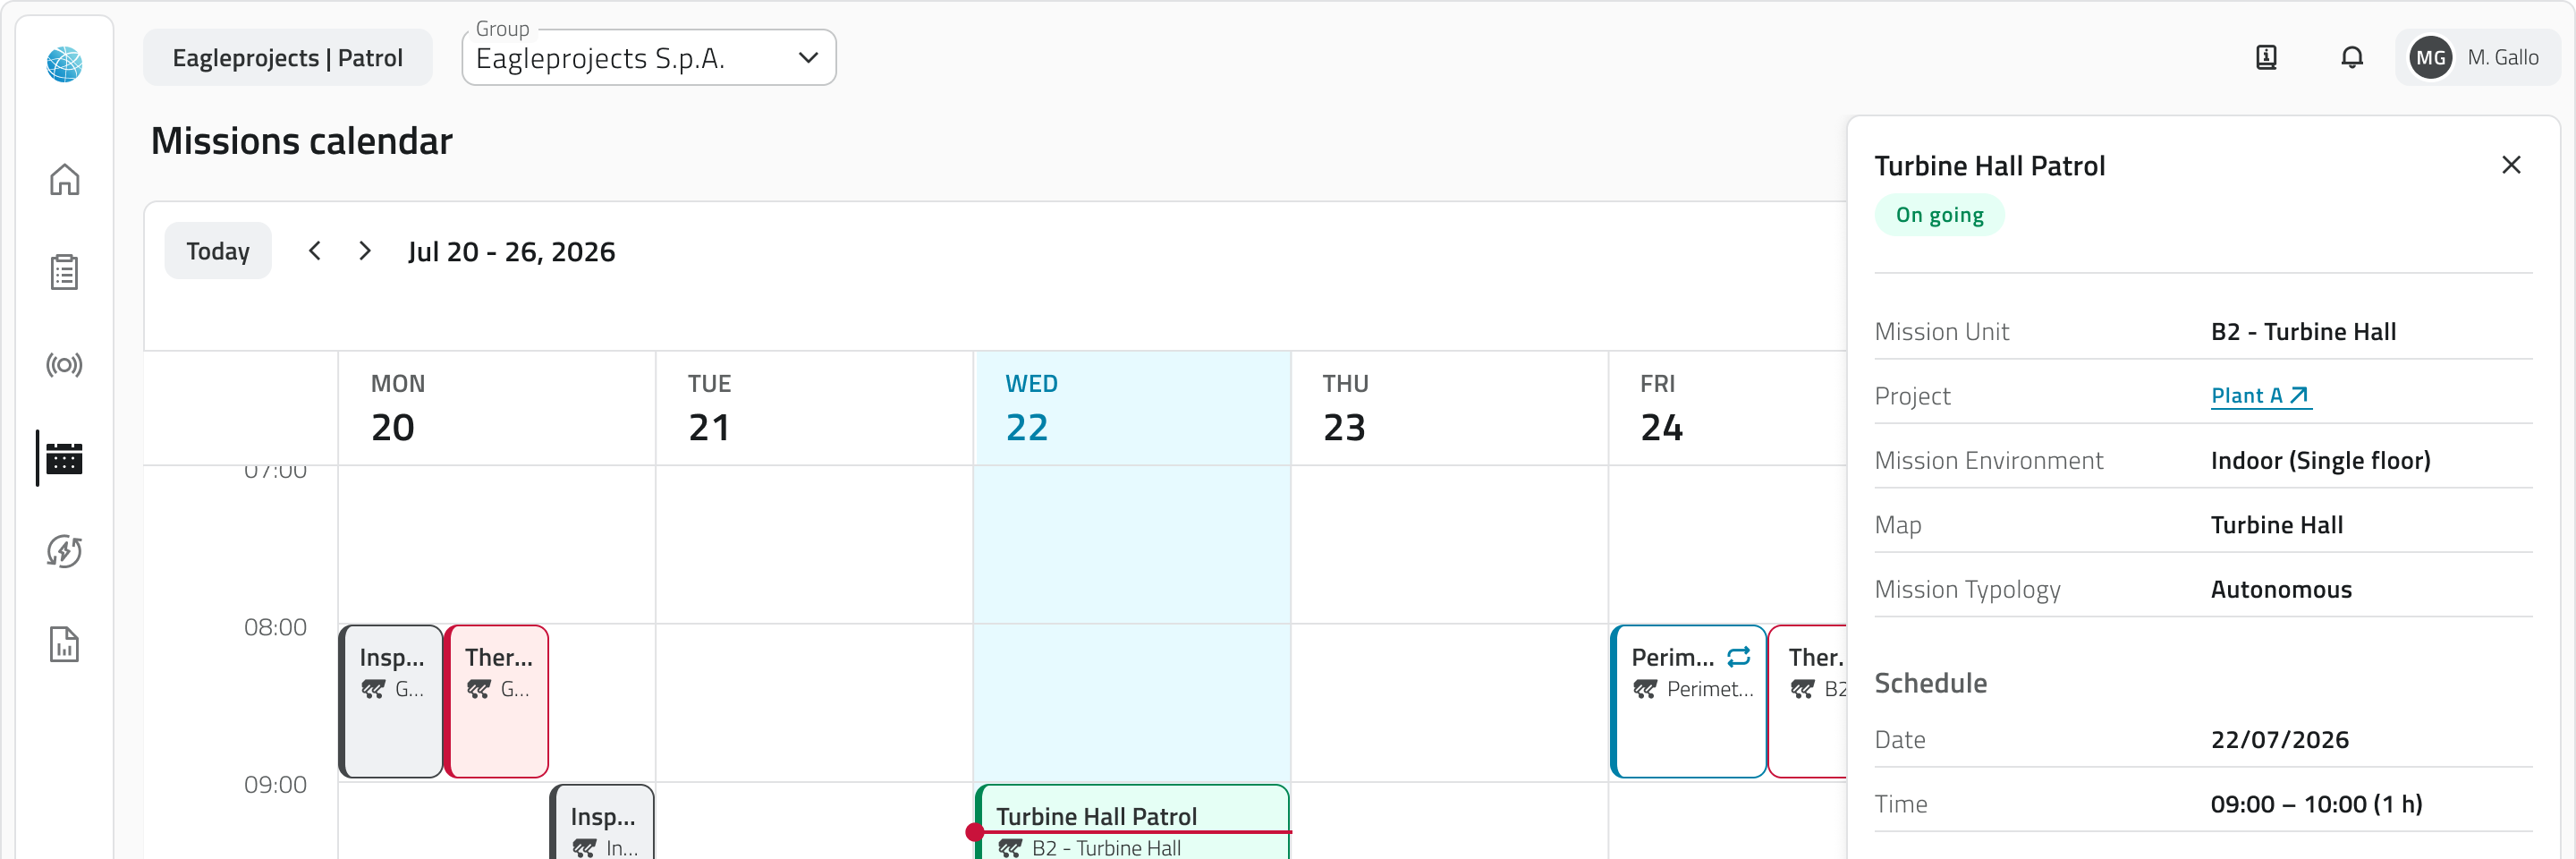](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/organization-calendar-week-view-on-going-mission-details.png)
---
### Reading a mission at a glance
Every mission on the calendar carries its start time, its name and the **Mission Unit** that runs it. A mission that belongs to a series also carries the recurrence icon, so you can tell it apart from a mission planned once.
The colour of each mission represents its state, and the legend above the calendar shows what each colour means:
| **State** | **What it means** |
| **Planned** | The mission will start at the date and time set for it. |
| **On going** | The mission is running now. |
| **Executed** | The mission has run and is over. |
| **In conflict** | The **Mission Unit** has been selected for two missions in the same time slot, so this mission risks not starting. |
---
### Opening a mission from the calendar
Select a mission and a panel opens on the right, showing its state and its configuration: the **Mission Unit**, the **Mission Environment**, the map and the typology, followed by a **Schedule** section with the date, the time and how long the run lasts.
When the mission is in conflict, the panel says so: the **Mission Unit** is committed to another mission in the same time slot, and this one risks not starting.
[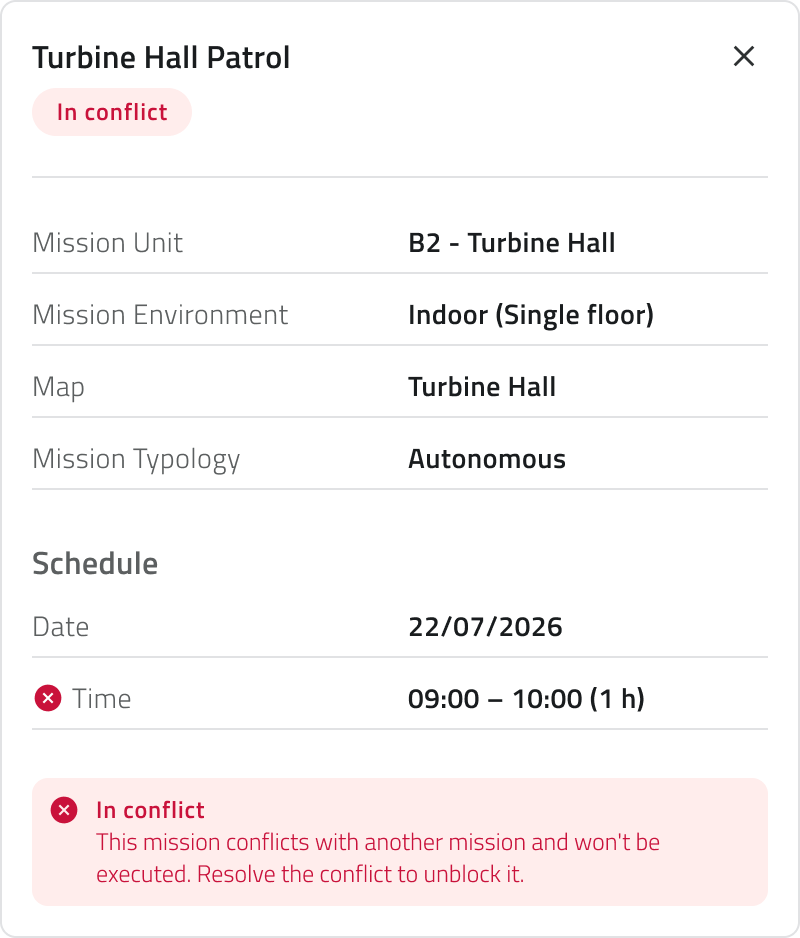](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/Q3oimage-2.png)
---
### Following the recurring missions
The **Series** view lists the recurring missions one by one. Each of them shows the rhythm and the time it runs at, the first and the last date of the series, how many occurrences are still to come and how many of them are in conflict, and the date of the next one. **View** opens the series on the calendar.
[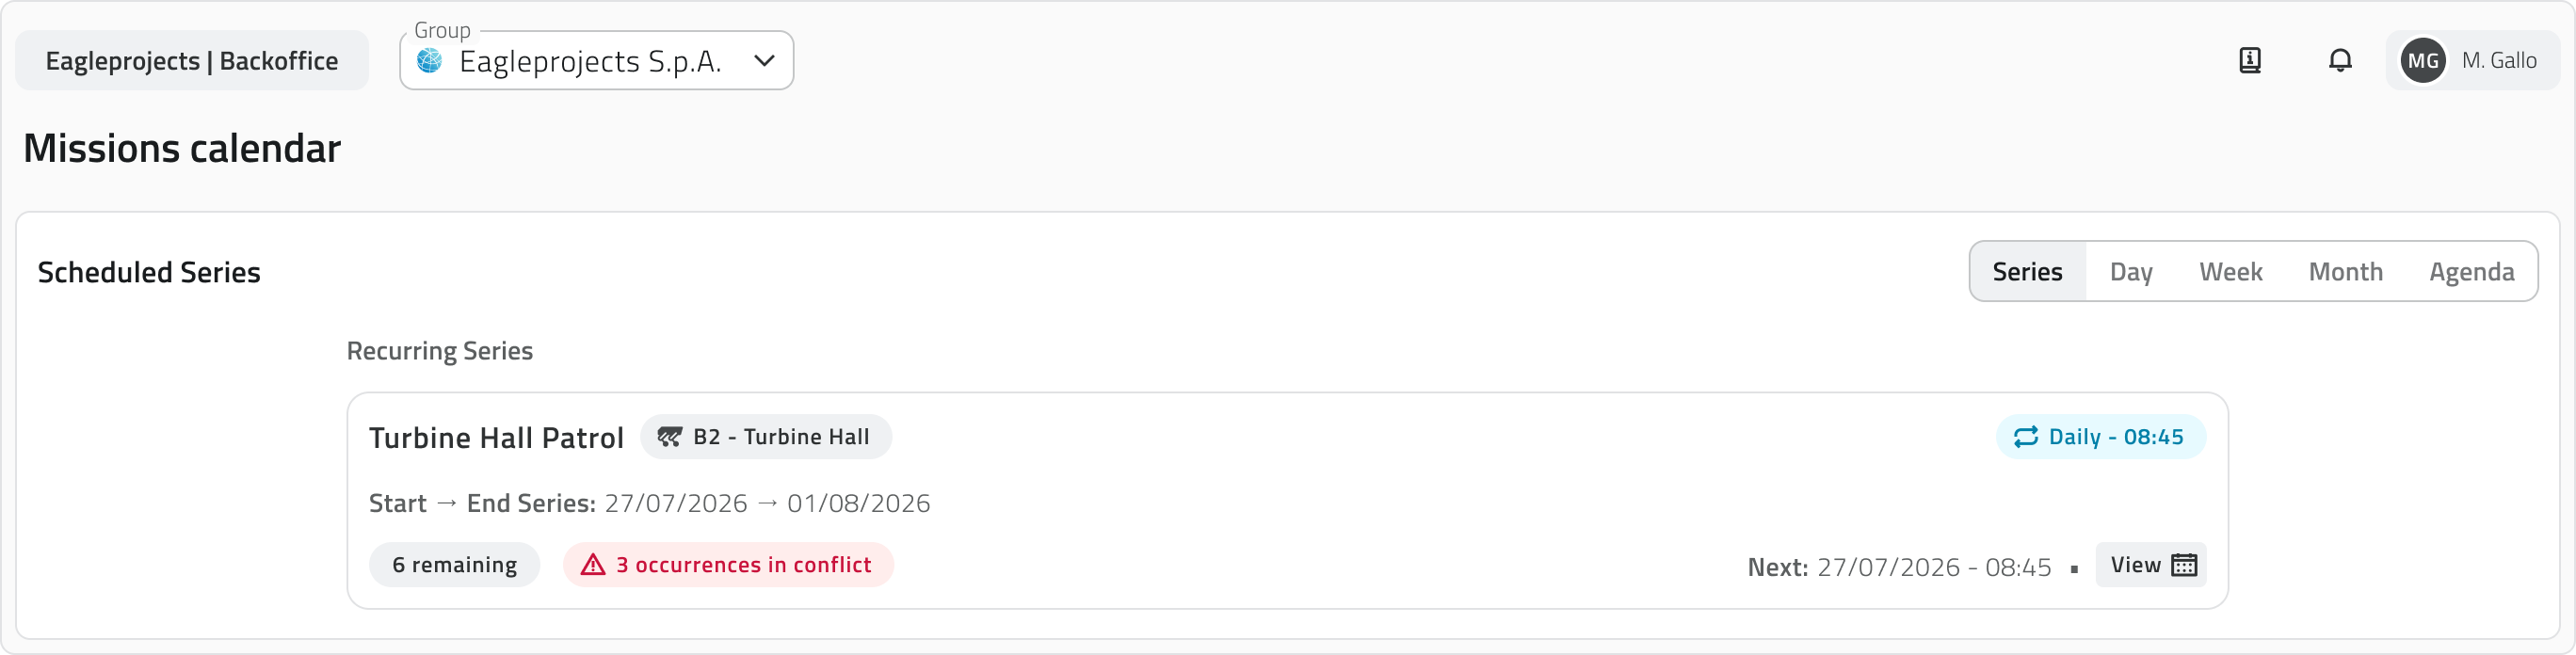](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/jghimage-3.png)
---
### Deleting a planned mission
The **Delete** button, at the bottom of the panel, removes the mission from the project. For a mission planned once, a confirmation is all it takes.
For a mission that belongs to a series, you first choose what to delete: only that occurrence, that one and all the following ones, or the entire series. Next to each choice you see how many occurrences it involves and the date it reaches.
[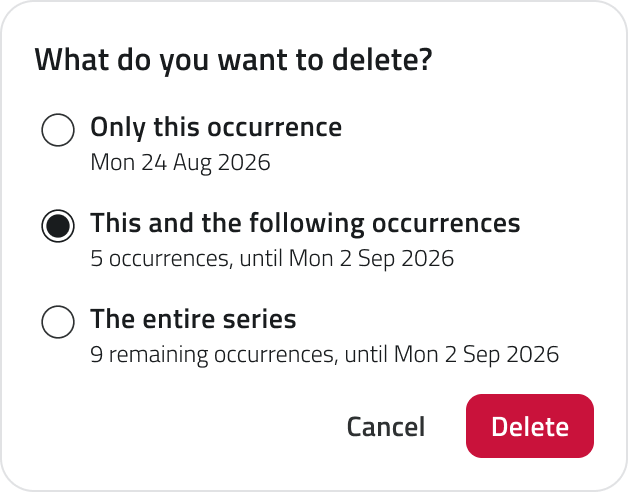](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/UeEimage-4.png)
---
### The Organization Calendar
In the main app, the calendar displays the missions for all projects in the selected group.
Since the missions here come from different projects, each one always indicates which project it belongs to: the panel adds a **Project** row, and in the **Series** view the project appears next to each recurring mission. In both cases, it's a link that opens the project.
---
### Links
- *[Schedule a mission](https://wiki.eaglearca.com/books/mission-planner-sBN/page/schedule-a-mission "Schedule a mission")*: how a mission ends up on the calendar.
- *[Edit a mission's configuration](https://wiki.eaglearca.com/books/mission-planner-sBN/page/edit-a-missions-configuration "Edit a mission's configuration")*: changing a mission instead of deleting it.
---
[  English ](https://wiki.eaglearca.com/link/178#bkmrk-english-italiano) [  Italiano ](https://wiki.eaglearca.com/link/178#bkmrk-english-italiano-1)
## Calendario delle missioni
---
**Calendario delle missioni** distribuisce su un calendario tutto ciò che è pianificato, così vedi quando una **Mission Unit** è impegnata, quali missioni stanno per partire e quali restano in attesa che un conflitto venga risolto.
Lo stesso calendario compare in due punti, e cambia solo l'ampiezza di ciò che raccoglie:
| **Dove lo apri** | **Cosa raccoglie** |
| Dentro un progetto, dall'icona del calendario nella barra laterale | Le missioni di quel progetto. È da qui che elimini una missione o una delle sue occorrenze. |
| Dalla pagina principale dell'app, tramite l'icona del calendario nella barra laterale | Le missioni dell'organizzazione e del gruppo selezionato, su tutti i suoi progetti. |
---
### Le cinque viste
Le viste mostrano le stesse missioni, ma ciascuna risponde a una domanda diversa:
| **Vista** | **Cosa mostra** |
| **Serie** | Le missioni ricorrenti elencate una per una, al posto della griglia dei giorni. |
| **Giorno** | Una giornata su griglia oraria, con ogni missione al proprio orario e una linea che segna il momento attuale. |
| **Settimana** | Sette giorni affiancati, per capire quanto è carica una settimana. |
| **Mese** | Il mese intero, con le missioni di ogni giorno. Quando un giorno è troppo pieno per mostrarle tutte, **+N missioni** indica quante altre ce ne sono. |
| **Agenda** | I prossimi 14 giorni in elenco, raggruppati per giorno e senza i giorni vuoti. |
Le frecce spostano al periodo precedente o successivo a quello che stai guardando, mentre **Oggi** riporta a quello corrente.
[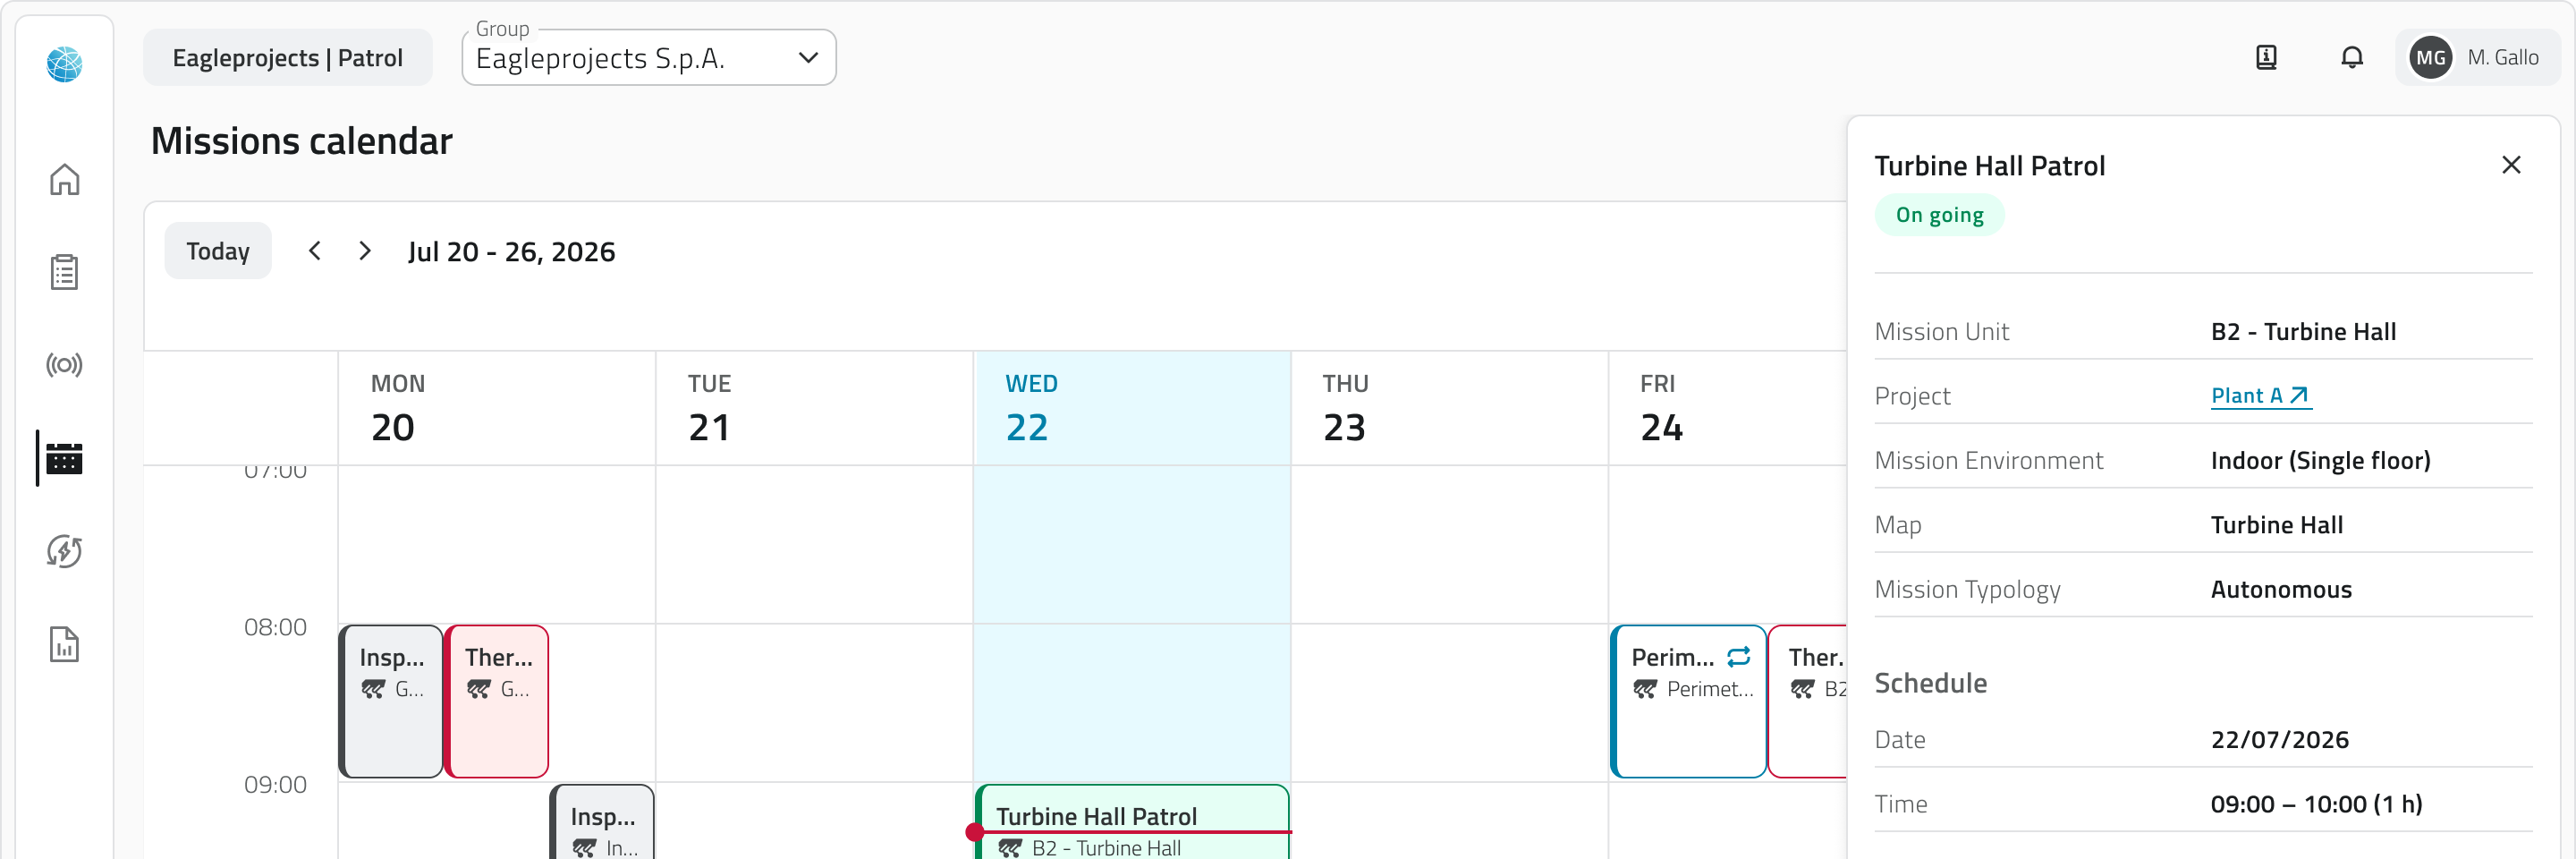](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/oxVimage-1.png)
---
### Leggere una missione a colpo d'occhio
Ogni missione sul calendario riporta l'orario di avvio, il nome e la **Mission Unit** che la esegue. Le missioni che fanno parte di una serie portano anche l'icona della ricorrenza, che le distingue da quelle pianificate una volta sola.
Il colore di ogni missione rappresenta il suo stato, e la legenda sopra il calendario ricorda a cosa corrisponde ciascun colore:
| **Stato** | **Cosa significa** |
| **Pianificata** | La missione partirà alla data e all'ora impostate. |
| **In corso** | La missione è in esecuzione adesso. |
| **Eseguita** | La missione è stata eseguita e si è conclusa. |
| **In conflitto** | La **Mission Unit** è stata selezionata per due missioni nello stesso slot orario, quindi la missione rischia di non partire. |
---
### Aprire una missione dal calendario
Selezionando una missione si apre un pannello a destra che riporta il suo stato e la sua configurazione: la **Mission Unit**, l'**Ambiente della missione**, la mappa e la tipologia, seguiti da una sezione **Pianificazione** con la data, l'ora e la durata dell'esecuzione.
Se la missione è in conflitto il pannello lo segnala: la **Mission Unit** è impegnata in un'altra missione nello stesso slot orario e questa rischia di non partire.
[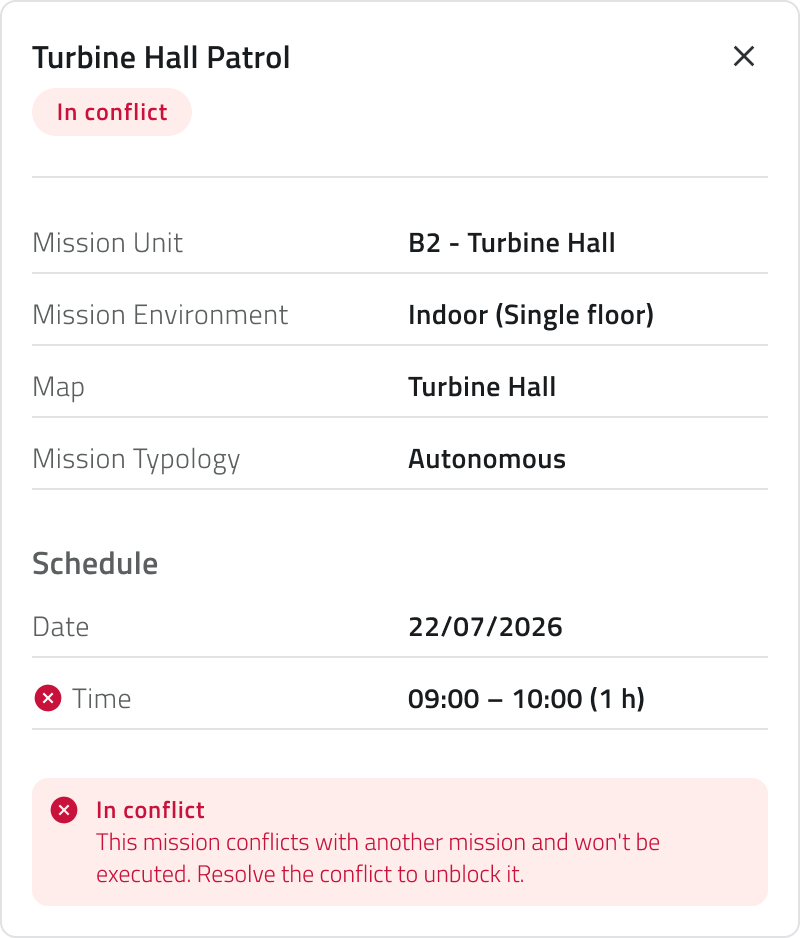](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/OAOimage-2.png)
---
### Seguire le missioni ricorrenti
La vista **Serie** raccoglie le missioni ricorrenti, una riga per ciascuna. Per ognuna vedi con quale ritmo e a che ora viene eseguita, il primo e l'ultimo giorno della serie, quante occorrenze restano da svolgere e quante di queste sono in conflitto, insieme alla data della prossima. Con il pulsante **Visualizza** apri la serie direttamente sul calendario.
[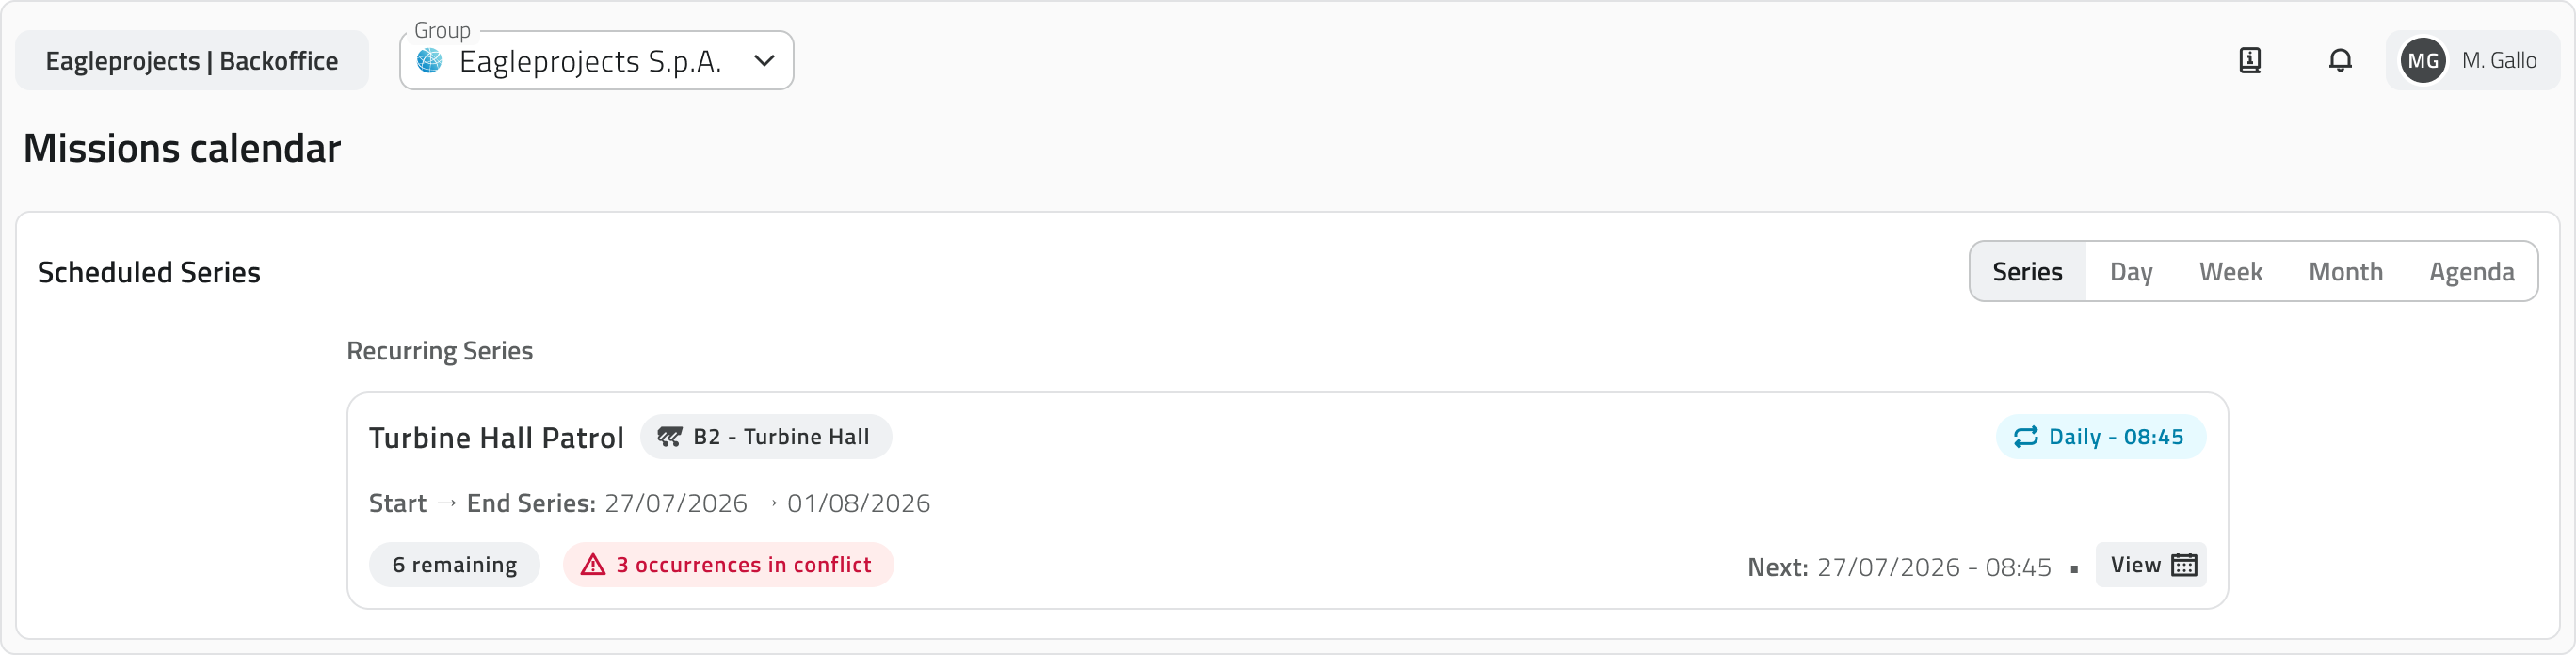](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/8cSimage-3.png)
---
### Eliminare una missione pianificata
In fondo al pannello della missione, il pulsante **Elimina** la rimuove dal progetto. Se la missione è pianificata una volta sola, basta confermare.
Se invece la missione fa parte di una serie, devi prima indicare cosa eliminare: solo quell'occorrenza, quella e tutte le successive, oppure l'intera serie. Accanto a ogni scelta trovi quante occorrenze comprende e fino a quale data arriva.
[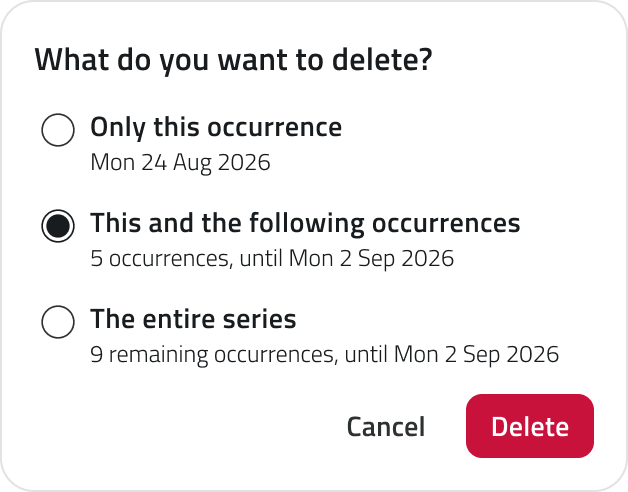](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/YF8image-4.png)
---
### Il calendario dell'organizzazione
Nell'app principale, il calendario mostra le missioni di tutti i progetti del gruppo selezionato.
Dato che qui le missioni arrivano da progetti diversi, ognuna indica sempre da quale: il pannello aggiunge la riga **Progetto** e nella vista **Serie** il progetto compare accanto a ogni missione ricorrente. In entrambi i casi è un link che apre il progetto.
---
### Collegamenti
- *[Pianificare una missione](https://wiki.eaglearca.com/books/mission-planner-sBN/page/schedule-a-mission "Schedule a mission")*: come una missione finisce sul calendario.
- *[Modificare la configurazione di una missione](https://wiki.eaglearca.com/books/mission-planner-sBN/page/edit-a-missions-configuration "Edit a mission's configuration")*: modificare una missione invece di eliminarla.
---
***Last update:** 14 September 2026*
# Robot Dog – Tracking a live mission
During a live mission you follow the robot dog as it moves and you see what its add-ons see, and you can step in at any moment: take the controls yourself, stop the unit where it is, bring it home or end the mission.
[  English ](https://wiki.eaglearca.com/link/179#bkmrk-english-italiano) [  Italiano ](https://wiki.eaglearca.com/link/179#bkmrk-english-italiano-1)
---
During a live mission you follow the robot dog as it moves and you see what its add-ons see, and you can step in at any moment: take the controls yourself, stop the unit where it is, bring it home or end the mission.
You arrive here in two ways: by starting a mission from the **Pre Check**, or by opening a mission from **Live Missions** in the mission list.
---
### The live screen
The panel on the left holds the state of the mission and the commands to act on it, and it can be closed when you need more room. You follow the run on the map, always among the views, with the route and the unit moving along it, while the rest of the space is shared out by the streams you have turned on.
At the top of the panel, a chip reports the state of the mission. Below it the unit is named with its model and its battery level, and then come the controls that let you drive it.
Four tabs follow: **Equipment** lists the add-ons the unit carries, **Details** gathers the configuration the mission was created with, **In view** decides what the map shows, and **Streaming** is where you manage the streams, turning each add-on's transmission on or off.
[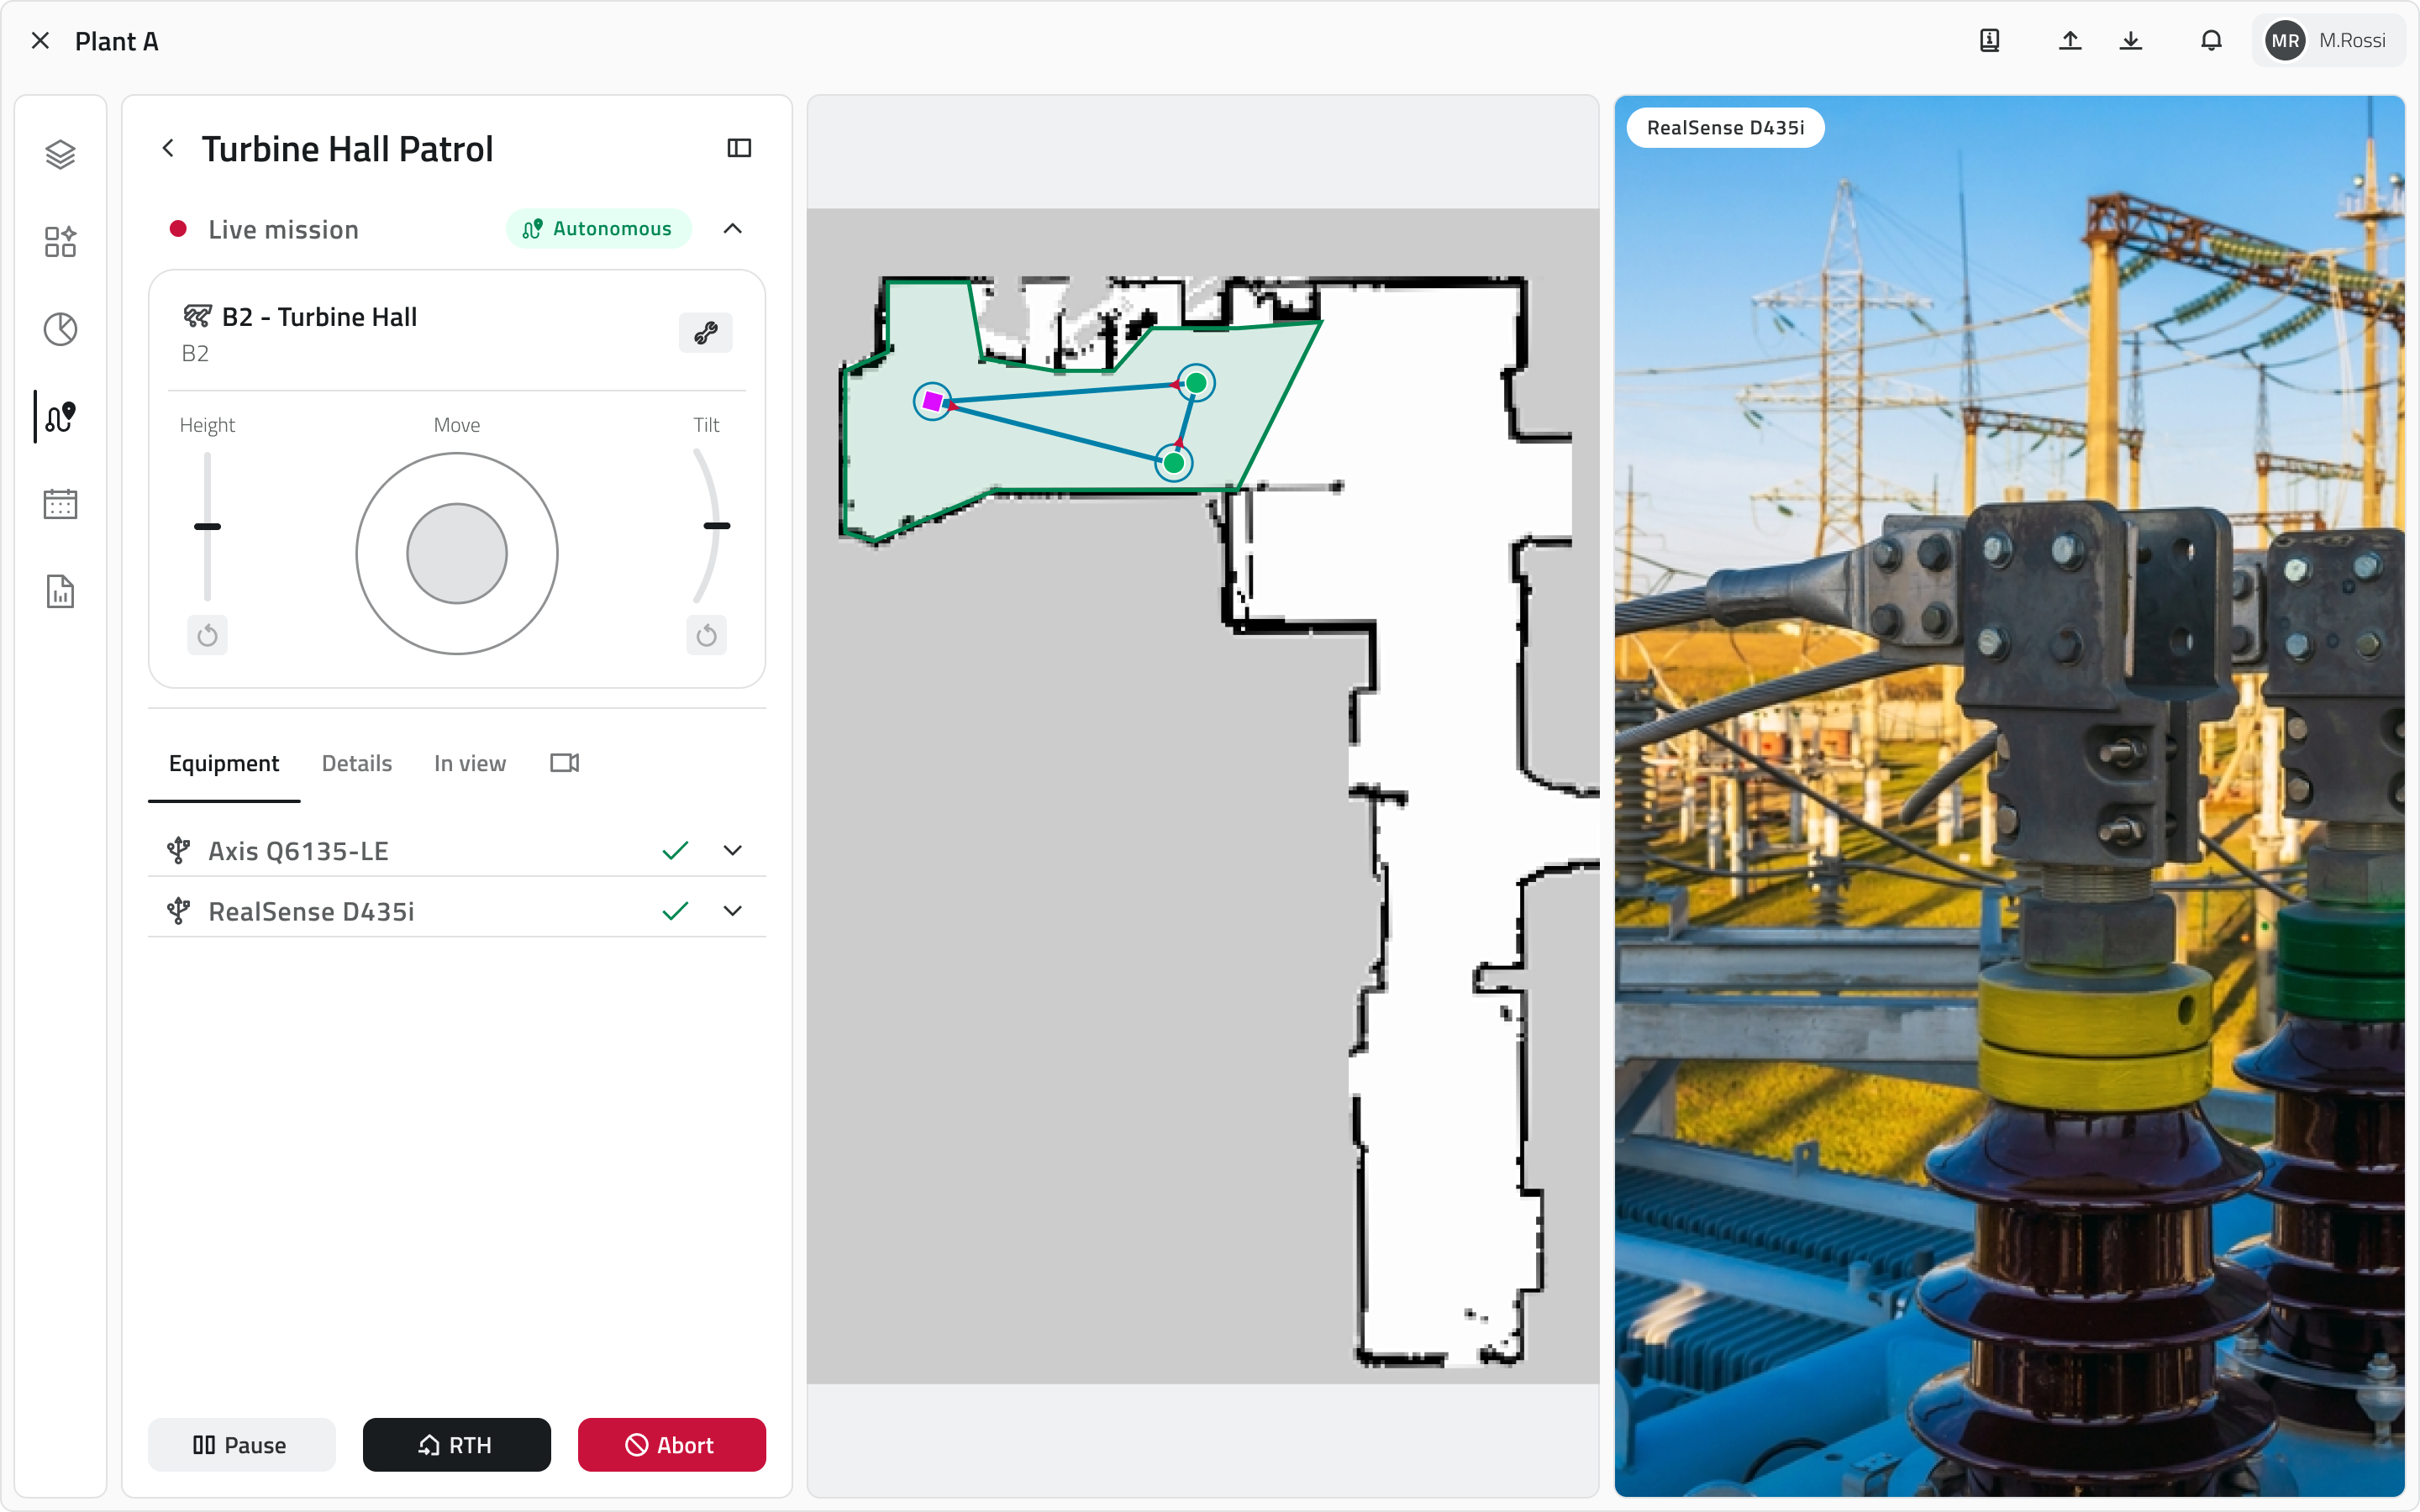](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/ViWimage-1.png)
---
### Mission control modes
The chip at the top of the panel names one of three states, and each one changes what the unit is doing and what you can do with it.
#### Autonomous mode
The robot dog travels the route on its own, waypoint after waypoint, and performs the actions configured on each one.
#### Manual control mode
Use the joypad and the mission passes into your hands: the autonomous run is suspended, the unit answers only to your commands and a message on the panel reminds you that you have the controls. There are three of them:
[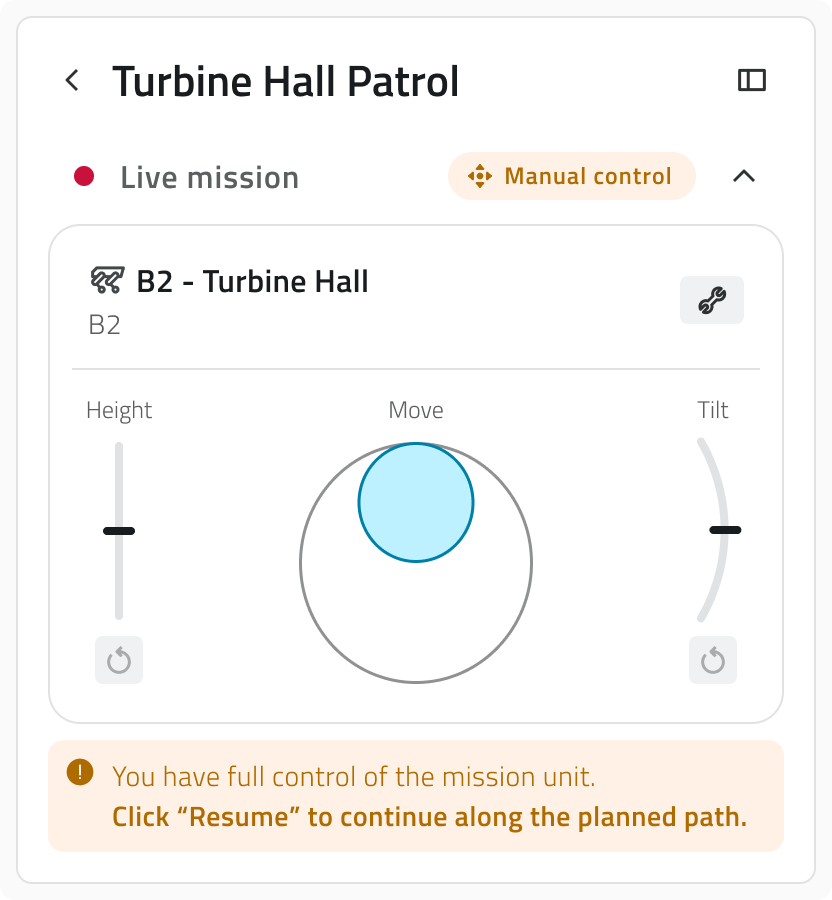](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/a8Nimage-2.png)
| **Control** | **What it does** |
| **Move** (joypad) | Controls the robot dog's movements in the direction applied on the joypad. |
| **Height** | Raises and lowers the body of the robot dog. Height does not stop it: the unit can walk however high or low the body is. |
| **Tilt** | Leans the body forward or backward, so as to point the add-ons downward or upward. Unlike height, tilt prevents movement: while the body is tilted, the unit does not respond to the joypad's movement commands. |
**Height** and **Tilt** each have a reset below them, which brings the value back to its default.
The **Resume** button puts the mission back in autonomous mode.
#### Pause
**Pause** stops the robot dog where it is. The unit waits there with no time limit, until you decide what to do next. **Resume** sends it back along the route.
---
### Ending the mission early
Two commands end a mission before its last waypoint, and they leave the unit in very different places. Both ask for a confirmation, and neither can be undone.
| **Command** | **Where the unit ends up** |
| **RTH** | The unit works out a way back and returns to its **Home Position**. |
| **Abort** | The unit leaves the route and stays where it is, idle, until you take manual control or start another mission. |
Both treat what has been recorded in the same way: everything already saved is kept, while anything still being recorded when you confirm is lost. Stop a recording before confirming if you want to keep it.
While the unit is returning home you can still stop it with the **Pause** button, and the **Resume** button puts it back on the way home.
---
### Using the add-ons during the mission
The **Equipment** section lists the controllable add-ons mounted on the unit and reports, for each one, whether it is responding. Opening one gives you its controls without interrupting the mission: the available actions depend on the add-on.
| **Control** | **What it does** |
| **Aiming** | The arrows point the add-on up, down, left and right, and the reset below them brings it back to the position it started from. |
| **Zoom** | Brings the image closer or takes it further away, with the current value between the two buttons. |
| **Photo** | Takes one image, there and then. |
| **Start REC** | Begins a recording, and stops it when you ask again. |
[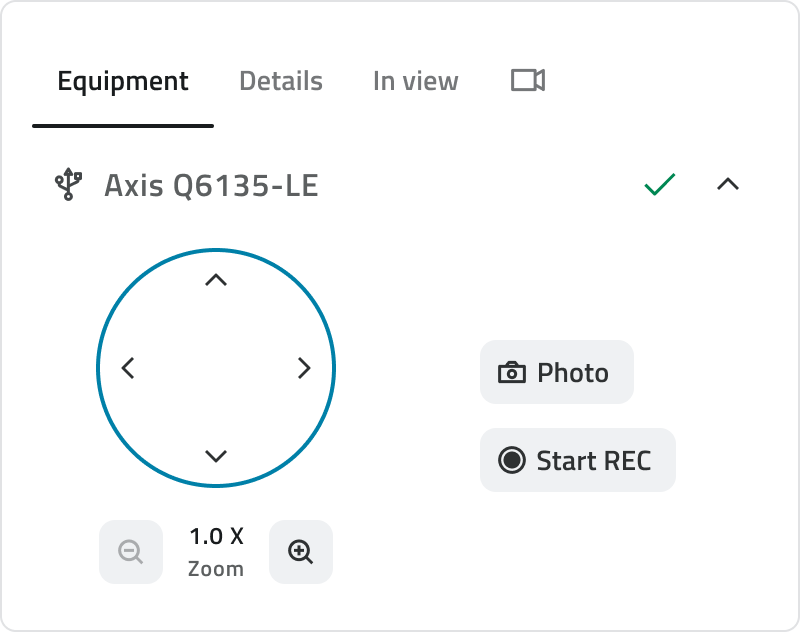](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/hv1image-3.png)
Not every add-on offers all of these: in each one you find only the controls it supports.
What you do here is yours alone: it neither changes the mission nor touches the actions configured on the waypoints, which the unit goes on performing. The controls work in autonomous mode as well as when you have taken over.
---
### Watching the streams
Every video source you turn on opens a view of its own, with the name of the add-on it comes from at the top. The views share the available space with the map, which stays visible throughout, so you can keep an eye on where the unit is and on what it is transmitting.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/T9Zimage-4.png)
---
### Leaving the mission without stopping it
Going back to the mission list leaves the mission running: the robot dog carries on, and the mission stays under **Live Missions**. Open it again from there and you are back where you were, with the map, the streams and the controls.
---
### Links
- *[Run the pre-check and start a mission](https://wiki.eaglearca.com/books/mission-planner-sBN/page/run-the-pre-check-and-start-a-mission "Run the pre-check and start a mission")*: the checks that come before the start.
- *[Review an executed mission](https://wiki.eaglearca.com/books/mission-planner-sBN/page/review-an-executed-mission "Review an executed mission")*: what you find once a mission is over.
- *[Control room](https://wiki.eaglearca.com/books/mission-planner-sBN/page/control-room "Control room")*: following every unit of the organisation at once.
---
[  English ](https://wiki.eaglearca.com/link/179#bkmrk-english-italiano) [  Italiano ](https://wiki.eaglearca.com/link/179#bkmrk-english-italiano-1)
## Robot dog – Monitoraggio di una missione in tempo reale
---
Durante una missione live segui il robot dog mentre avanza da un waypoint all'altro e vedi in diretta le immagini dei suoi add-on. Puoi intervenire in qualsiasi momento: prendere i comandi dell'unità, fermarla dov'è, farla rientrare alla **Home Position** oppure chiudere la missione prima della fine.
Ci si arriva in due modi: avviando una missione dal **Pre Check**, oppure aprendo una missione da **Live Missions** nell'elenco delle missioni.
---
### La schermata della missione in corso
A sinistra, il pannello raccoglie lo stato della missione e i comandi con cui intervenire; quando ti serve più spazio puoi chiuderlo. L'esecuzione può essere seguita sulla mappa, sempre presente, che mostra il percorso e l'unità mentre lo percorre. Lo spazio restante si divide tra gli streaming che hai attivato.
In cima al pannello, un chip riporta lo stato della missione. Sotto trovi l'unità con il modello e il livello di batteria, e poi i comandi con cui guidarla.
Seguono quattro sezioni: **Equipment** elenca gli add-on che l'unità porta con sé, **Dettagli** raccoglie la configurazione con cui la missione è stata creata, **In vista** decide cosa mostra la mappa e da **Streaming** gestisci le trasmissioni, accendendo o spegnendo quella di ciascun add-on.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/ViWimage-1.png)
---
### Modalità di controllo della missione
Il chip in cima al pannello indica in quale dei tre stati si trova la missione. Da questo dipendono sia il comportamento dell'unità sia i comandi che hai a disposizione.
#### Modalità autonoma
Il robot dog percorre da sé il tracciato, un waypoint dopo l'altro, eseguendo su ciascuno le azioni che sono state configurate.
#### Modalità controllo manuale
Basta usare il joypad perché la missione passi sotto il tuo controllo: l'esecuzione autonoma si sospende, l'unità risponde soltanto ai tuoi comandi e un messaggio nel pannello lo segnala. Hai a disposizione tre comandi:
[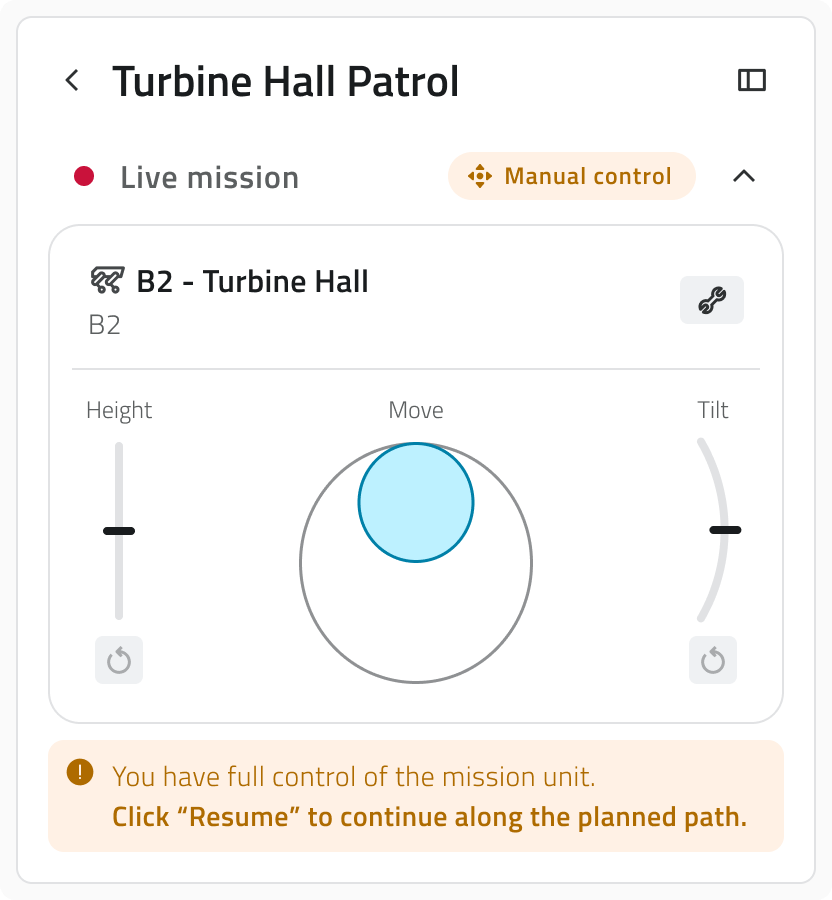](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/IPjimage-2.png)
| **Comando** | **Cosa fa** |
| **Movimento** (joypad) | Comanda gli spostamenti del robot dog nella direzione impressa sul joypad. |
| **Altezza** | Alza e abbassa il corpo del robot dog. L'altezza non gli impedisce di muoversi: l'unità può camminare sia alzata sia abbassata. |
| **Inclinazione** | Inclina il corpo in avanti o all'indietro, così da puntare gli add-on verso il basso o verso l'alto. A differenza dell'altezza, l'inclinazione preclude gli spostamenti: finché il corpo è inclinato l'unità non risponde ai comandi di movimento del joypad. |
Sia **Altezza** sia **Inclinazione** hanno un reset che riporta il valore a quello predefinito.
Con il pulsante **Riprendi** la missione torna in modalità autonoma.
#### Pausa
**Pausa** arresta il robot dog dov'è: l'unità resta in attesa a tempo indeterminato, finché non decidi come proseguire. Con **Riprendi** torna a percorrere il tracciato.
---
### Chiudere la missione prima della fine
Due comandi chiudono la missione prima dell'ultimo waypoint, con esiti molto diversi per l'unità. Entrambi chiedono una conferma e nessuno dei due può essere annullato.
| **Comando** | **Dove finisce l'unità** |
| **RTH** | L'unità calcola il percorso di rientro e torna alla propria **Home Position**. |
| **Abort** | L'unità abbandona il percorso e resta ferma dov'è, in attesa che tu prenda il controllo manuale o avvii un'altra missione. |
In entrambi i casi i media già salvati vengono conservati, mentre una registrazione ancora in corso al momento della conferma va perduta. Se vuoi conservarla, fermala prima di confermare.
Durante il rientro puoi comunque fermarla con il pulsante **Pausa**; con il pulsante **Riprendi** torna a dirigersi verso casa.
---
### Usare gli add-on durante la missione
La sezione **Equipment** elenca gli add-on comandabili montati sull'unità e segnala, per ciascuno, se sta rispondendo. Aprendone uno ne prendi i comandi senza interrompere la missione: le azioni disponibili dipendono dall'add-on.
| **Comando** | **Cosa fa** |
| **Orientamento** | Le frecce orientano l'add-on verso l'alto, il basso, destra e sinistra; il reset sottostante lo riporta nella posizione iniziale. |
| **Zoom** | Avvicina o allontana l'immagine. Il valore corrente è indicato tra i due pulsanti. |
| **Foto** | Scatta subito un'immagine. |
| **Avvia REC** | Avvia la registrazione e, premuto di nuovo, la interrompe. |
[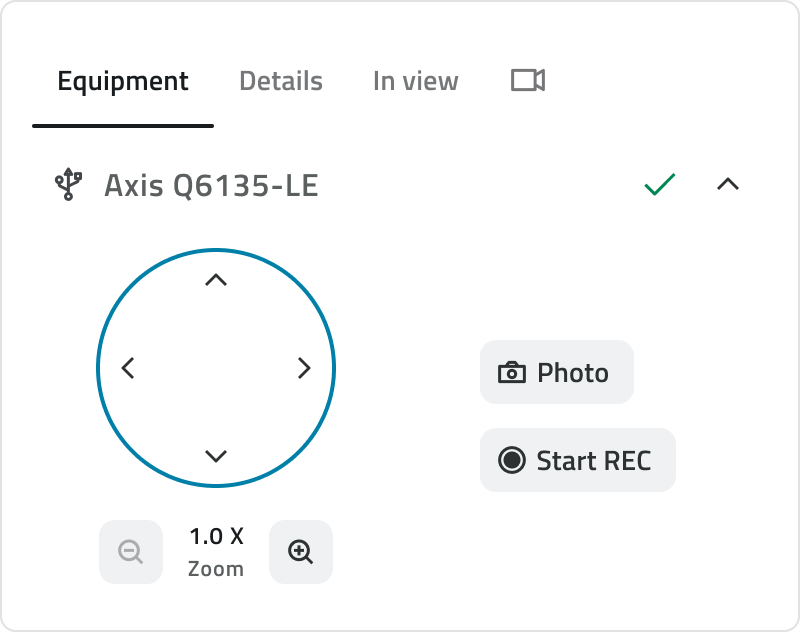](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/4Okimage-3.png)
Non tutti gli add-on offrono tutti questi comandi: per ciascuno trovi soltanto quelli che supporta.
Quello che fai da qui non modifica la missione e lascia intatte le azioni configurate sui waypoint, che l'unità continua a eseguire. I comandi restano utilizzabili sia in modalità autonoma sia dopo che hai preso il controllo.
---
### Guardare gli streaming
Ogni sorgente video che attivi apre una vista dedicata, con in alto il nome dell'add-on a cui fa riferimento. Le viste si distribuiscono automaticamente nello spazio disponibile insieme alla mappa, che resta sempre visibile: puoi così tenere d'occhio la posizione dell'unità e le immagini che trasmette.
[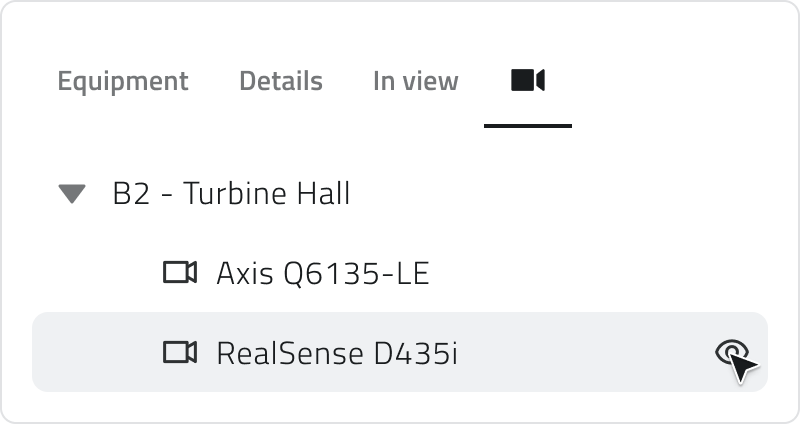](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/T9Zimage-4.png)
---
### Uscire dalla missione senza fermarla
Se torni all'elenco delle missioni la missione non si ferma: il robot dog continua il percorso stabilito e la trovi ancora sotto **Live Missions**. Basta riaprirla per ritrovare tutto come l'avevi lasciato, dalla mappa agli streaming ai comandi.
---
### Collegamenti
- *[Eseguire il pre-check e avviare una missione](https://wiki.eaglearca.com/books/mission-planner-sBN/page/run-the-pre-check-and-start-a-mission "Run the pre-check and start a mission")*: i controlli che precedono l'avvio.
- *[Consultare una missione eseguita](https://wiki.eaglearca.com/books/mission-planner-sBN/page/review-an-executed-mission "Review an executed mission")*: cosa trovi a missione conclusa.
- *[Control room](https://wiki.eaglearca.com/books/mission-planner-sBN/page/control-room "Control room")*: seguire insieme tutte le unità dell'organizzazione.
---
***Last update:** 6 August 2026*
# Drone – Tracking a live mission
During a live mission with a drone you can follow the mission from the panel and watch the images the cameras send back, while the flight runs on its own.
[  English ](https://wiki.eaglearca.com/link/181#bkmrk-english-italiano) [  Italiano ](https://wiki.eaglearca.com/link/181#bkmrk-english-italiano-1)
---
During a live mission with a drone you can follow the mission from the panel and watch the images the cameras send back, while the flight runs on its own.
You arrive here in two ways: by starting a mission from the **Pre Check**, or by opening it from the **Live Missions** section.
---
### The live screen
The panel on the left holds the state of the mission and the configuration it was built with, and it can be closed when you need more room. The map is always there, with the waypoints and the hangar of the mission, and the space left over is shared out by the streams you have turned on.
At the top of the panel a chip reports the state of the mission, below it the unit with the model of the drone, and then the three panels: **Details**, **In view** and **Streaming**, marked with a camera.
[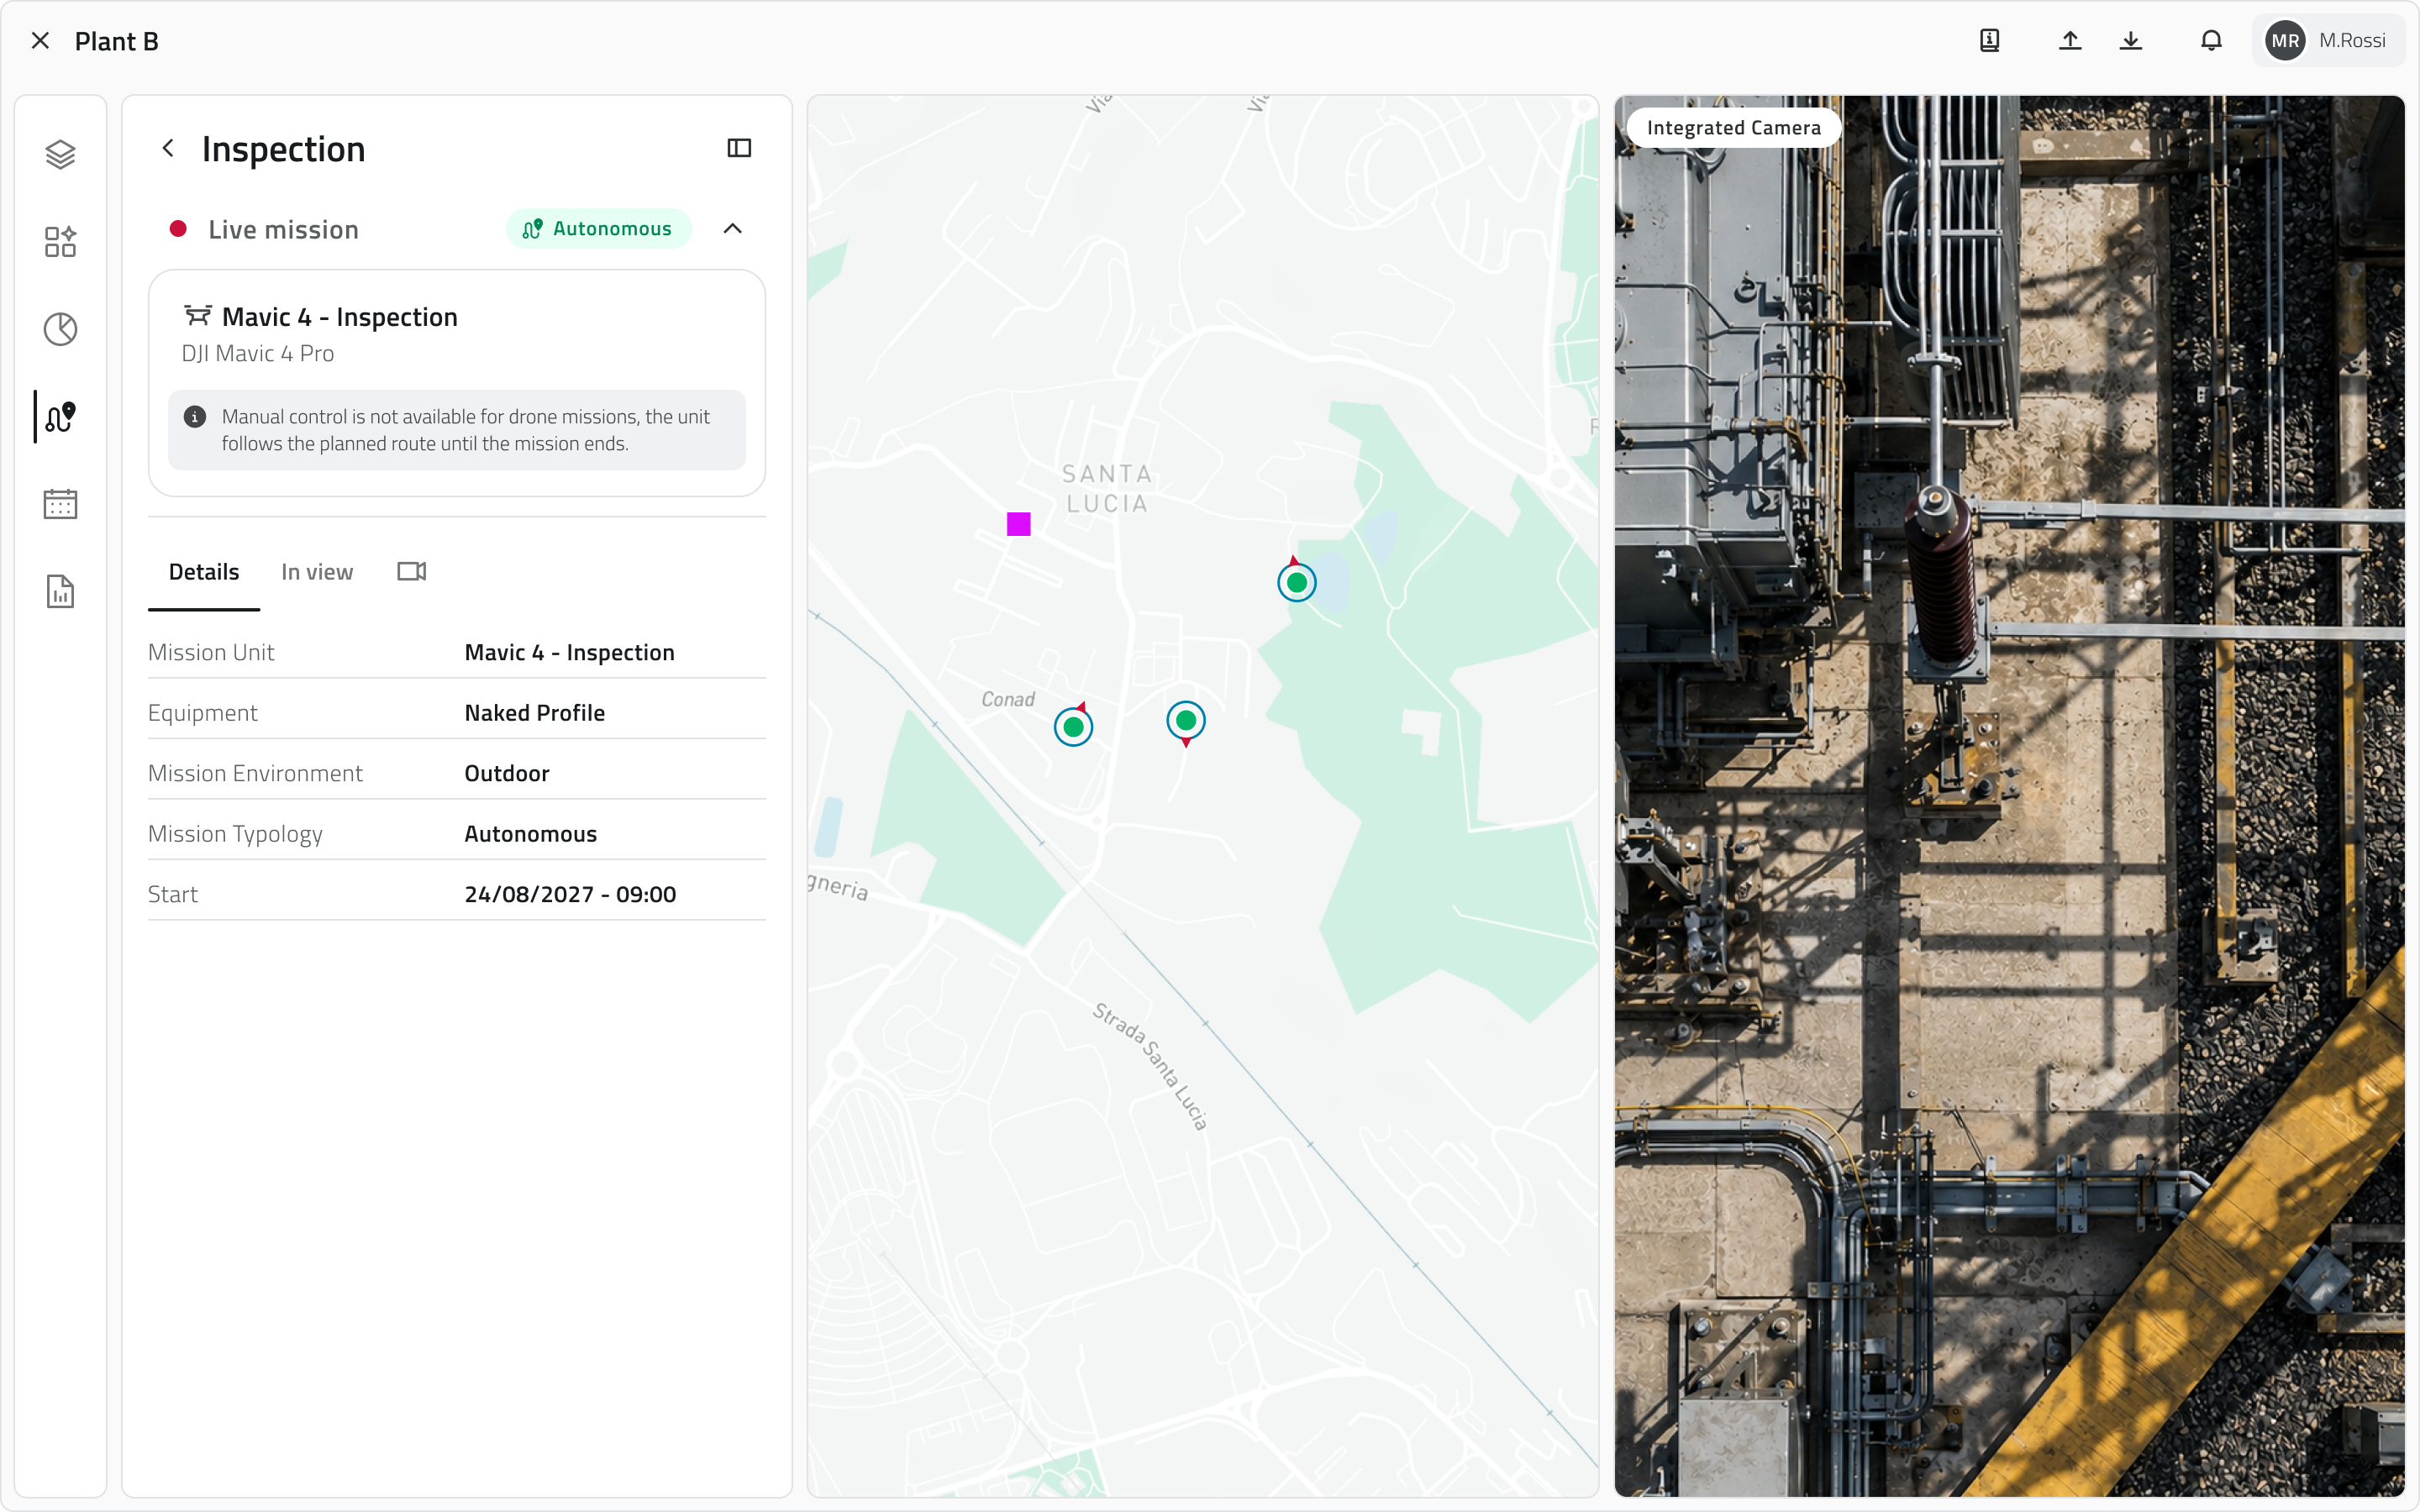](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/lnsimage-1.png)
---
### The details of the mission
The **Details** panel repeats the configuration the mission was created with: the **Mission Unit** that flies it, the **Equipment** it uses, the environment, the typology and the moment the mission started.
[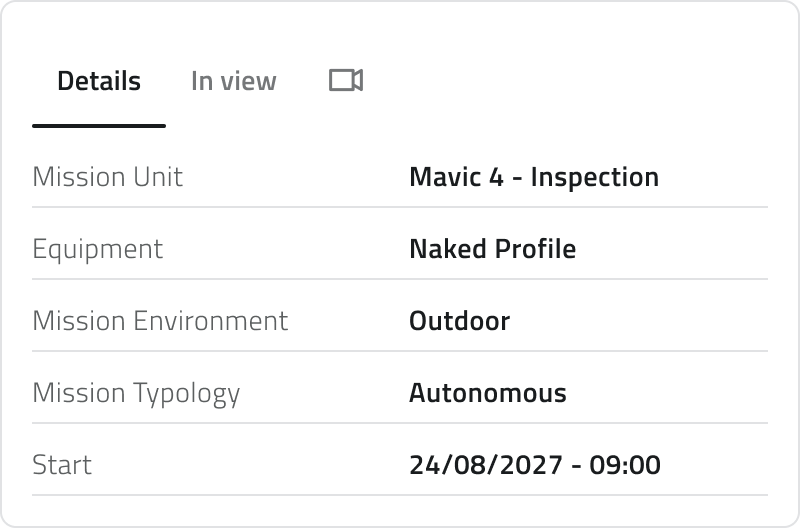](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/Zycimage-2.png)
---
### What the map shows
The **In view** panel lists the elements drawn on the map, the **Drone Waypoints** and the **Hangar**, and the eye beside each one shows or hides it while the mission goes on.
[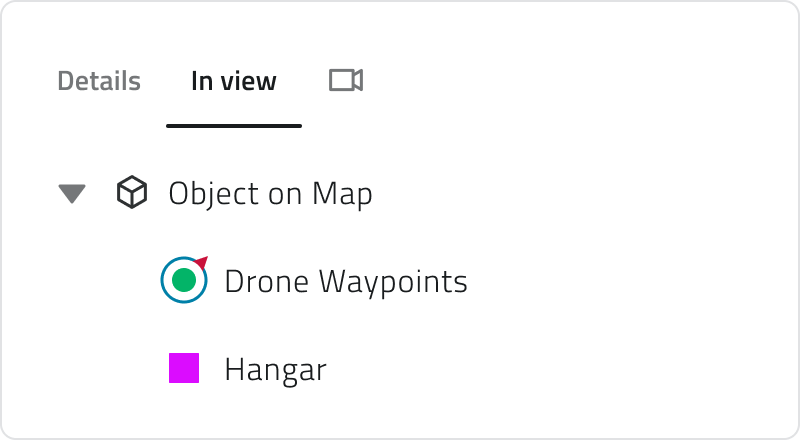](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/eM7image-3.png)
---
### Watching the streams
The **Streaming** panel lists the video sources grouped by unit, the drone with its own camera and the hangar with its own. Turning one on opens a view for it, with the name of the source at the top, and the eye beside a group hides the view again.
[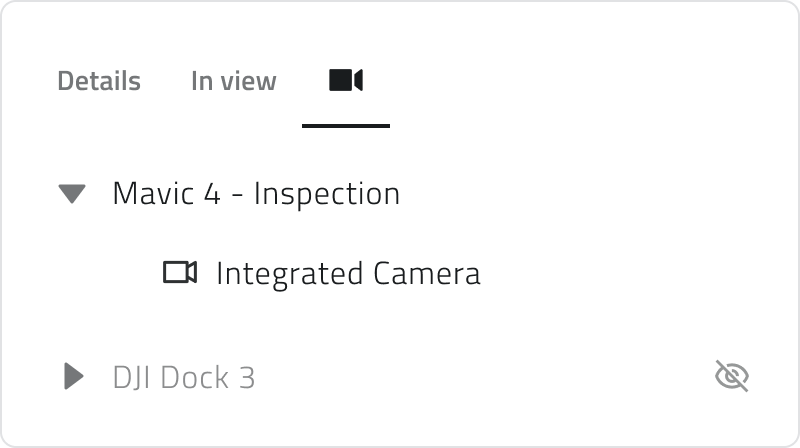](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/tMeimage-4.png)
The space adjusts itself as you show and hide the views: the map is always there, and what is left goes to the views you have open.
---
### Leaving the mission without stopping it
Going back to the mission list, or moving to another section of the platform, leaves the mission running: the drone carries on along its route and you can go back to it from the list, in the **Live Missions** section. Open it again and you find everything as you left it, the map and the streams included.
---
### Links
- *[Run the pre-check and start a mission](https://wiki.eaglearca.com/books/mission-planner-sBN/page/run-the-pre-check-and-start-a-mission "Run the pre-check and start a mission")*: the checks that come before the start.
- *[Find and manage your missions](https://wiki.eaglearca.com/books/mission-planner-sBN/page/find-and-manage-your-missions "Find and manage your missions")*: where you open a mission that is already running.
- *[Review an executed mission](https://wiki.eaglearca.com/books/mission-planner-sBN/page/review-an-executed-mission "Review an executed mission")*: what you find once a mission is over.
---
[  English ](https://wiki.eaglearca.com/link/181#bkmrk-english-italiano) [  Italiano ](https://wiki.eaglearca.com/link/181#bkmrk-english-italiano-1)
## Drone – Monitoraggio di una missione in tempo reale
Durante una missione live con drone puoi seguire la missione dal pannello e guardare le immagini che le telecamere trasmettono, mentre il volo procede da sé.
Ci si arriva in due modi: avviando una missione dal **Pre Check**, oppure aprendola dalla sezione **Live Missions**.
---
### La schermata della missione in corso
Il pannello a sinistra mostra lo stato della missione e la configurazione con cui è stata creata e può essere chiuso quando serve più spazio. La mappa rimane sempre visibile, con i waypoint e l’hangar della missione, mentre lo spazio restante viene suddiviso tra gli stream che sono stati attivati.
Nella parte superiore del pannello, un indicatore mostra lo stato della missione; sotto sono riportati l’unità e il modello del drone, seguiti dai tre pannelli: **Details**, **In view** e **Streaming**, quest’ultimo contrassegnato dall’icona di una fotocamera.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/lnsimage-1.png)
---
### I dettagli della missione
Il pannello **Details** riporta la configurazione con cui è stata creata la missione: la **Mission Unit** che la esegue, l’**Equipment** utilizzato, l’ambiente, la tipologia e l’ora di inizio della missione.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/Zycimage-2.png)
---
### Cosa si vede in mappa
Il pannello **In view** elenca gli elementi visualizzati sulla mappa, i **Drone Waypoints** e l’**Hangar**. L’icona a forma di occhio accanto a ciascun elemento consente di mostrarlo o nasconderlo durante la missione.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/eM7image-3.png)
---
### Guardare gli streaming
Il pannello **Streaming** elenca le sorgenti video raggruppate per unità: il drone con la propria telecamera e l’hangar con la propria. Attivando una sorgente, si apre la relativa vista, con il nome della sorgente nella parte superiore; l’icona a forma di occhio accanto a un gruppo consente di nascondere nuovamente la vista.
Lo spazio si adatta automaticamente man mano che le viste vengono mostrate o nascoste: la mappa rimane sempre visibile, mentre lo spazio restante viene distribuito tra le viste aperte.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/tMeimage-4.png)
---
### Uscire dalla missione senza fermarla
Tornare all’elenco delle missioni o spostarsi in un’altra sezione della piattaforma non interrompe la missione: il drone prosegue lungo il proprio percorso ed è possibile tornare alla missione dall’elenco, nella sezione **Live Missions**. Riaprendola, si ritrova tutto nello stato in cui era stato lasciato, inclusi la mappa e gli stream.
---
### Collegamenti
- *[Eseguire il pre-check e avviare una missione](https://wiki.eaglearca.com/books/mission-planner-sBN/page/run-the-pre-check-and-start-a-mission "Run the pre-check and start a mission")*: i controlli che precedono l'avvio.
- *[Trovare e gestire le missioni](https://wiki.eaglearca.com/books/mission-planner-sBN/page/find-and-manage-your-missions "Find and manage your missions")*: da dove apri una missione già in corso.
- *[Rivedere una missione eseguita](https://wiki.eaglearca.com/books/mission-planner-sBN/page/review-an-executed-mission "Review an executed mission")*: cosa trovi quando la missione è conclusa.
---
***Last update:** 21 August 2026*
# Review an executed mission
A mission that has come to an end stays available under Executed, in the Missions panel. Open it and you find how the run went, the media it collected, and the possibility to restore the mission without configuring it from scratch.
[  English ](https://wiki.eaglearca.com/link/182#bkmrk-english-italiano) [  Italiano ](https://wiki.eaglearca.com/link/182#bkmrk-english-italiano-1)
---
A mission that has come to an end stays available under **Executed**, in the **Missions** panel. Open it and you find how the run went, the media it collected, and the possibility to restore the mission without configuring it from scratch.
The panel on the left has three tabs, **Summary**, **Details** and **In view**, while beside it the map opens on which the mission ran, with the waypoints and the areas drawn when it was created.
---
### The report of the mission
At the top of the **Summary** tab is the list of **Manual Captures**: the photos and videos taken at your request while the mission was running, kept apart from those produced at the waypoints. They are split in two groups, photos and videos, each with its own count and with the name and the time of every file.
The waypoints follow, in the order they were reached, each with the number of actions carried out and media collected. Open one and you find the individual actions, with the add-on that performed them, and the files that go with them.
Waypoints the **Mission Unit** did not reach are marked in red, both in the list and on the map, so you can see at a glance which part of the route was left uncovered.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/9oIimage-1.png)
---
### The map of a mission that is over
The map of a mission that is over is read only: it shows the mission as it ran and can no longer be changed. You can still select the elements and use the measuring tools, to take distances and areas over the route that was covered.
---
### Opening a photo or a video
Select a file to open it full screen. Below it you find where it comes from, a waypoint or a manual capture, and when it was taken; the arrows on either side move to the other files of the same group. From here you can enlarge the image and download the file.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/YDZimage-2.png)
---
### How it was configured
The **Details** tab reports the configuration the mission ran with: the **Mission Unit**, the **Equipment** with its add-ons, the **Mission Environment**, the map, the typology and the moment it started.
The **In view** tab works as it does while planning: it lists the map and the elements drawn on it, hides and shows them, adjusts the opacity of the map and, in a multi floor mission, lists the floors.
---
### Running the same mission again
When a mission has to be repeated there is no need to configure it again: **Restore Mission**, in the menu at the top right of the panel, makes a copy of it as a **Draft**, with waypoints, actions, **Danger Zones** and **Geofencing** already in place. The copy can still be changed before it starts.
From the copy you take the usual path of a Draft: the platform connects to the **Mission Unit**, you capture the **Home Position** again and you move on to the **Pre Check**. The Home is taken again because it concerns where the unit is now, not where it was then.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/ykWimage-3.png)
---
### Discovery missions
A **Discovery** mission doesn't follow a route: it explores the environment and **produces a map**. The generated map is always uploaded to the system, while the mission itself is saved as completed only if **manual acquisitions** were made during execution. In that case the report contains no waypoints or actions, but a message confirming that the mission has ended, the acquisitions collected and, next to it, the map that was produced.
Missions of this kind cannot be restored: to explore again, configure a new **Discovery** mission.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/2vqimage-4.png)
---
### Links
- *[Find and manage your missions](https://wiki.eaglearca.com/books/mission-planner-sBN/page/find-and-manage-your-missions "Find and manage your missions")*: where you open an executed mission.
- *[Missions calendar](https://wiki.eaglearca.com/books/mission-planner-sBN/page/missions-calendar "missions-calendar")*: where an executed mission also appears.
---
[  English ](https://wiki.eaglearca.com/link/182#bkmrk-english-italiano) [  Italiano ](https://wiki.eaglearca.com/link/182#bkmrk-english-italiano-1)
## Esaminare una missione completata
---
Una missione che si è conclusa resta a disposizione nella sezione **Eseguite** del pannello **Missioni**. Aprendola ritrovi come si è svolta, i media che ha raccolto e la possibilità di ripristinare la missione senza configurarla da capo.
Il pannello a sinistra è diviso in tre sezioni, **Riepilogo**, **Dettagli** e **In vista**. Accanto si apre la mappa su cui la missione si è svolta, con i waypoint e le aree definiti in fase di creazione.
---
### Il resoconto della missione
In cima alla sezione **Riepilogo** è riportato l'elenco delle **Acquisizioni manuali**: le foto e i video acquisiti su tua richiesta durante lo svolgimento della missione, tenuti distinti da quelli prodotti sui waypoint. Sono divisi in due gruppi, foto e video, ognuno con il proprio conteggio e con il nome e l'ora di acquisizione di ciascun file.
Seguono i waypoint, nell'ordine in cui sono stati raggiunti, ciascuno con il numero di azioni svolte e di media raccolti. Aprendone uno trovi le singole azioni, con l'add-on che le ha eseguite, e i file corrispondenti.
I waypoint che la **Mission Unit** non ha raggiunto sono evidenziati in rosso, nell'elenco e sulla mappa: individui così a colpo d'occhio quale parte del percorso è rimasta scoperta.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/6znimage-1.png)
---
### La mappa di una missione conclusa
La mappa di una missione conclusa è in sola lettura: mostra la missione com'è stata eseguita e non può più essere modificata. Puoi comunque selezionare gli elementi e usare gli strumenti di misura, per rilevare distanze e aree sul percorso svolto.
---
### Aprire una foto o un video
Selezionando un file lo apri a schermo intero. Sotto compaiono la sua origine, il waypoint oppure un'acquisizione manuale, e la data in cui è stato acquisito; le frecce ai lati portano agli altri file dello stesso gruppo. Da qui puoi ingrandire l'immagine e scaricare il file.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/gizimage-2.png)
---
### Com'è stata configurata
La sezione **Dettagli** riporta la configurazione con cui la missione è stata eseguita: la **Mission Unit**, l'**Equipment** con i suoi add-on, l'**Ambiente della missione**, la mappa, la tipologia e il momento di avvio.
La sezione **In vista** si comporta come in fase di pianificazione: elenca la mappa e gli elementi disegnati, permette di nasconderli e di mostrarli, regola l'opacità della mappa e, in una missione multipiano, riporta i singoli piani.
---
### Eseguire di nuovo la stessa missione
Per ripetere una missione non serve riconfigurarla: **Ripristina missione**, nel menu in alto a destra del pannello, ne crea una copia come **Bozza**, con waypoint, azioni, **Zone di pericolo** e **Geofencing** già al loro posto. La copia resta modificabile prima dell'avvio.
Da lì la copia segue il percorso di una qualsiasi Bozza: la piattaforma si collega alla **Mission Unit**, tu riacquisisci la **Home Position** e passi al **Pre Check**. La Home Position va riacquisita perché dipende da dove si trova l'unità ora, non da dov'era allora.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/IX2image-3.png)
---
### Missioni Esplorative
Una missione **Esplorativa** non segue un percorso: esplora l'ambiente e ne **produce una mappa**. La mappa generata viene sempre caricata nel sistema, mentre la missione viene salvata come eseguita solo se durante l'esecuzione sono state effettuate **acquisizioni manuali**. In quel caso il resoconto non contiene waypoint né azioni, ma un messaggio che conferma la conclusione della missione, le acquisizioni raccolte e, accanto, la mappa prodotta.
Le missioni di questo tipo non possono essere ripristinate: per esplorare di nuovo occorre configurare una nuova missione **Esplorativa**.
[](https://wiki.eaglearca.com/uploads/images/gallery/2026-08/waeimage-4.png)
---
### Collegamenti
- *[Trovare e gestire le missioni](https://wiki.eaglearca.com/books/mission-planner-sBN/page/find-and-manage-your-missions "Find and manage your missions")*: da dove apri una missione eseguita.
- *[Calendario delle missioni](https://wiki.eaglearca.com/books/mission-planner-sBN/page/missions-calendar "missions-calendar")*: dove una missione eseguita compare anche.
---
***Last update:** 6 August 2026*